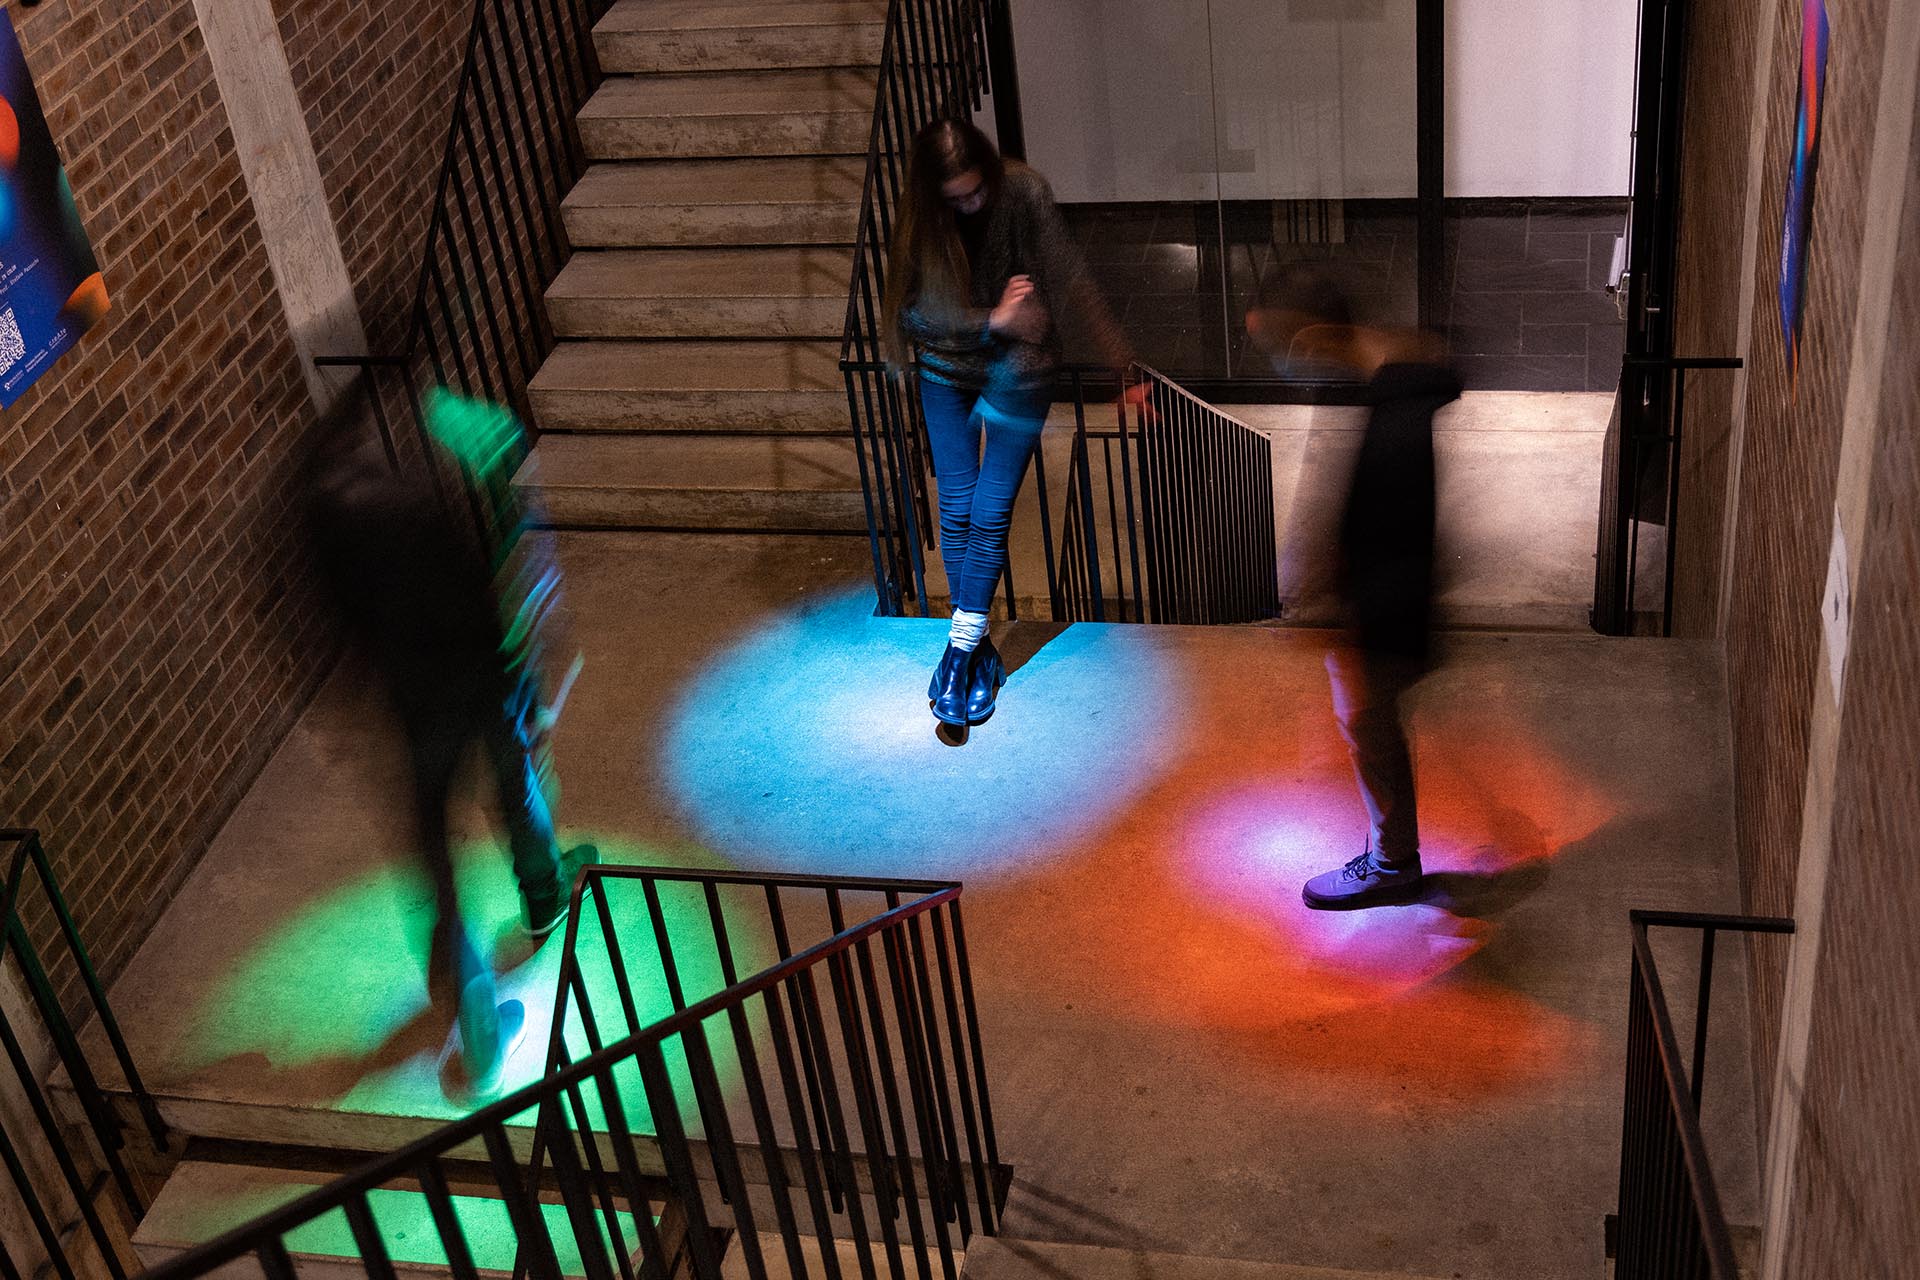
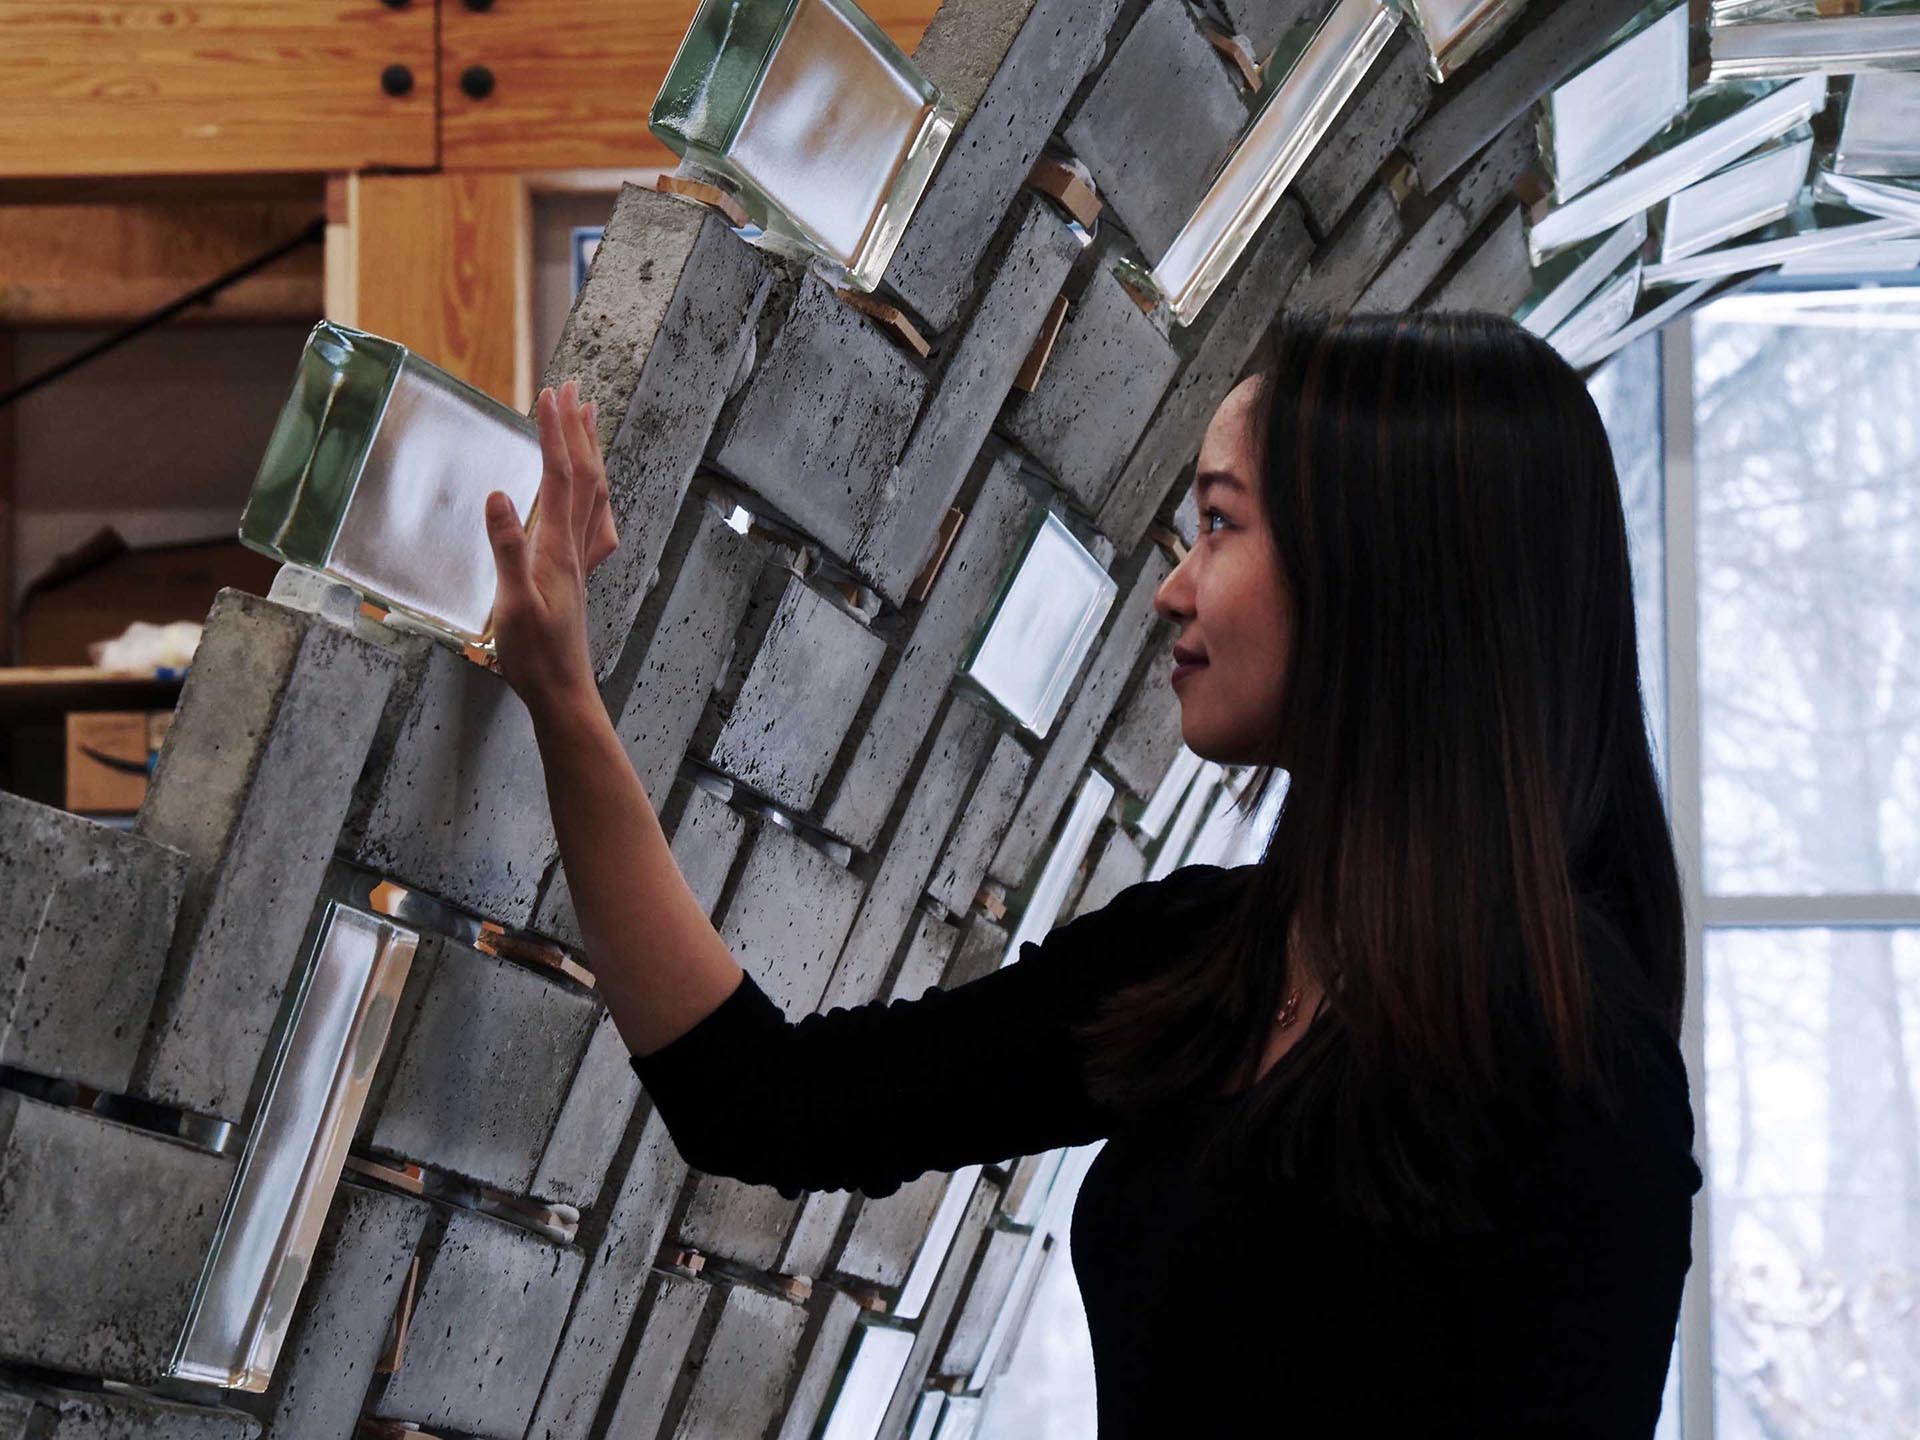
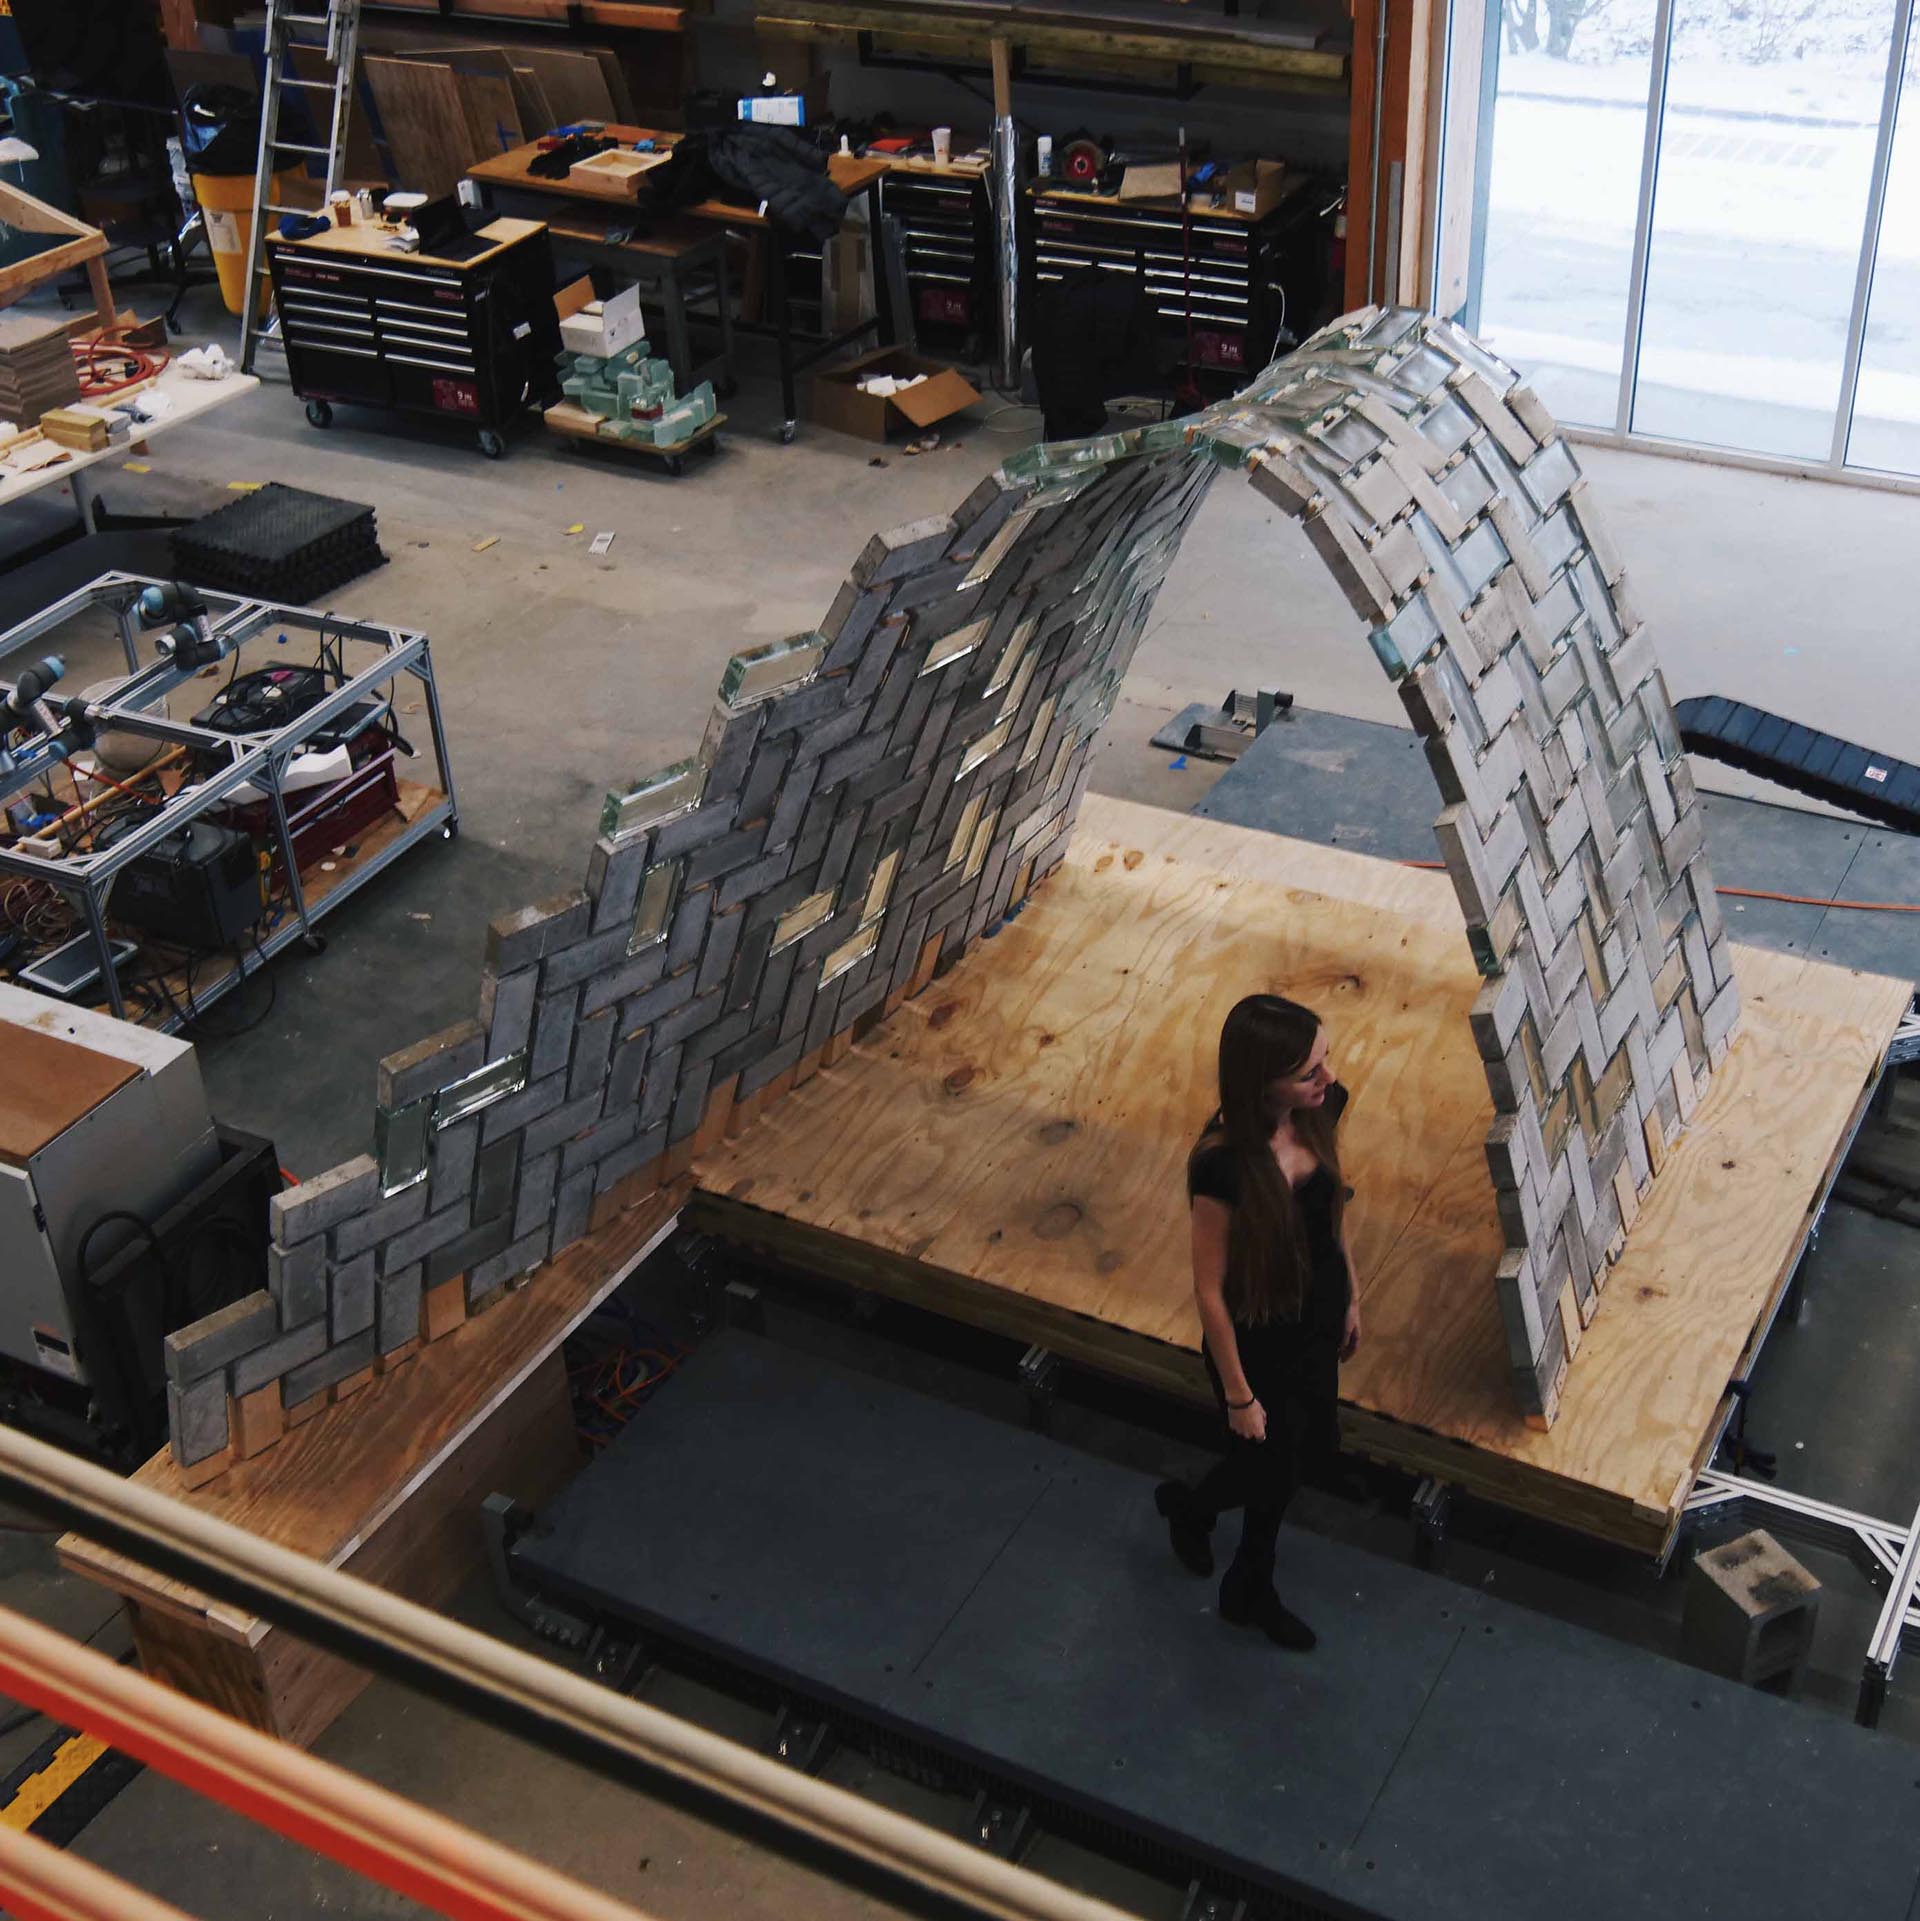
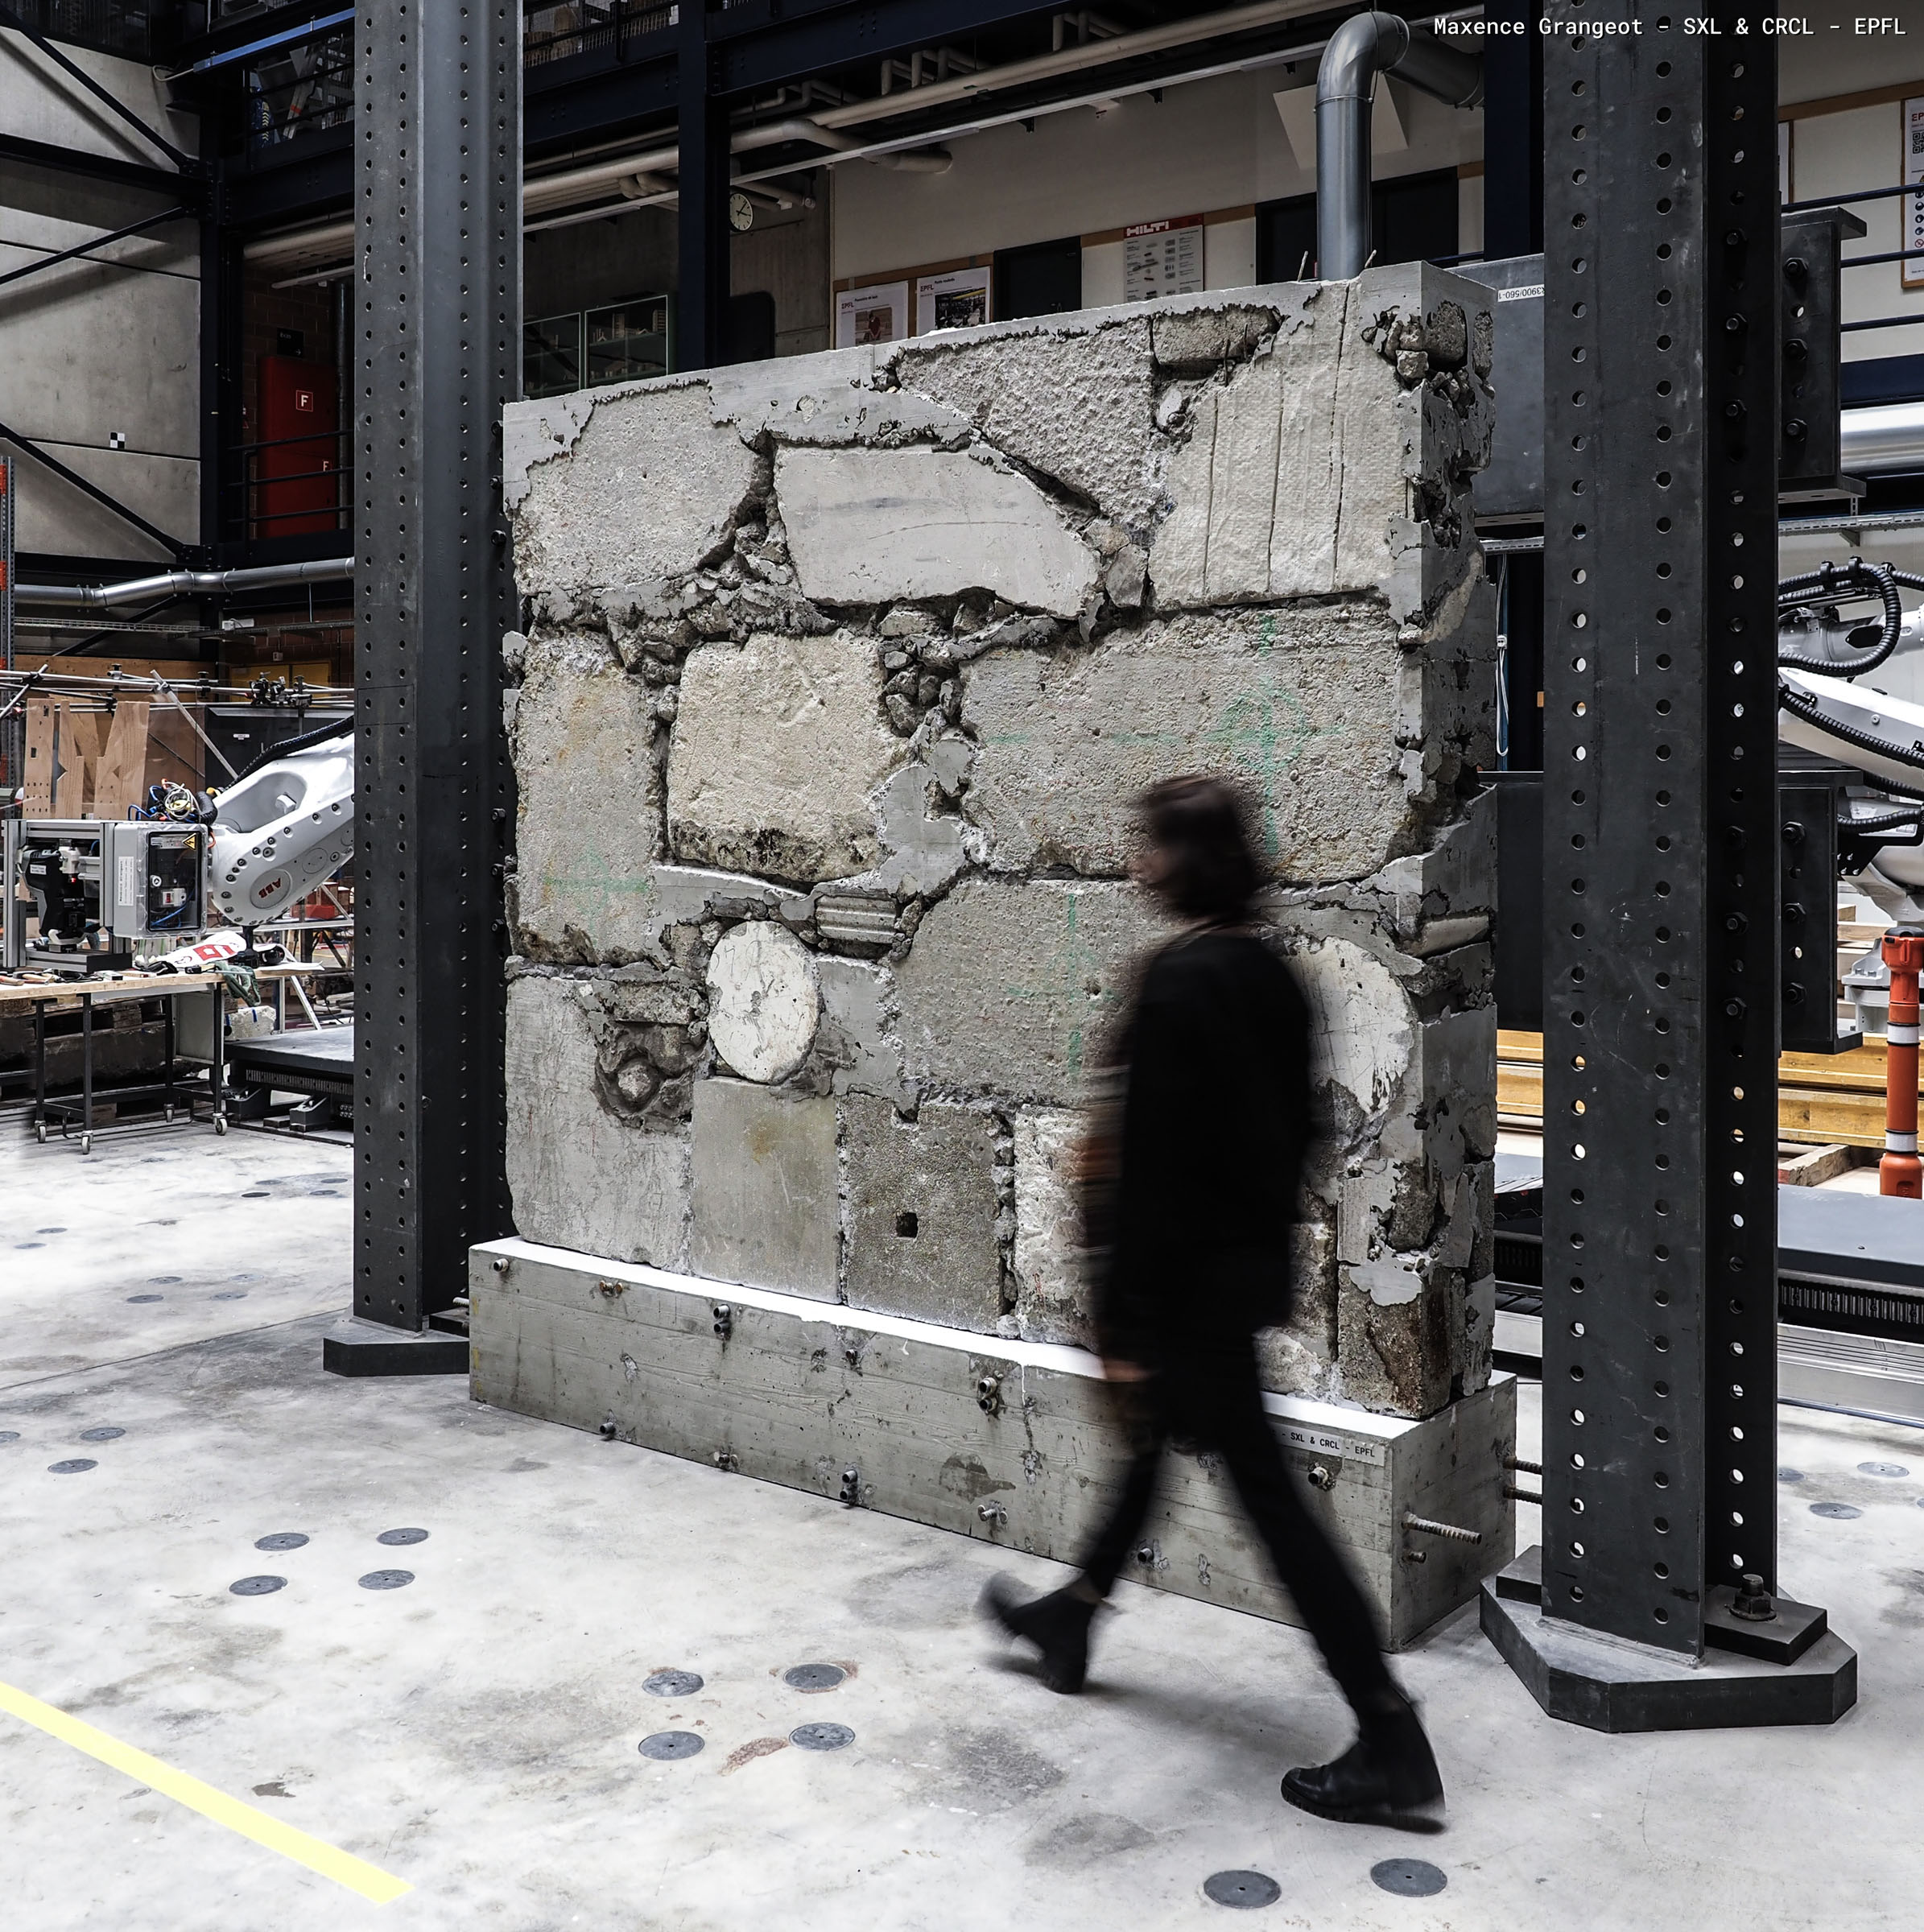
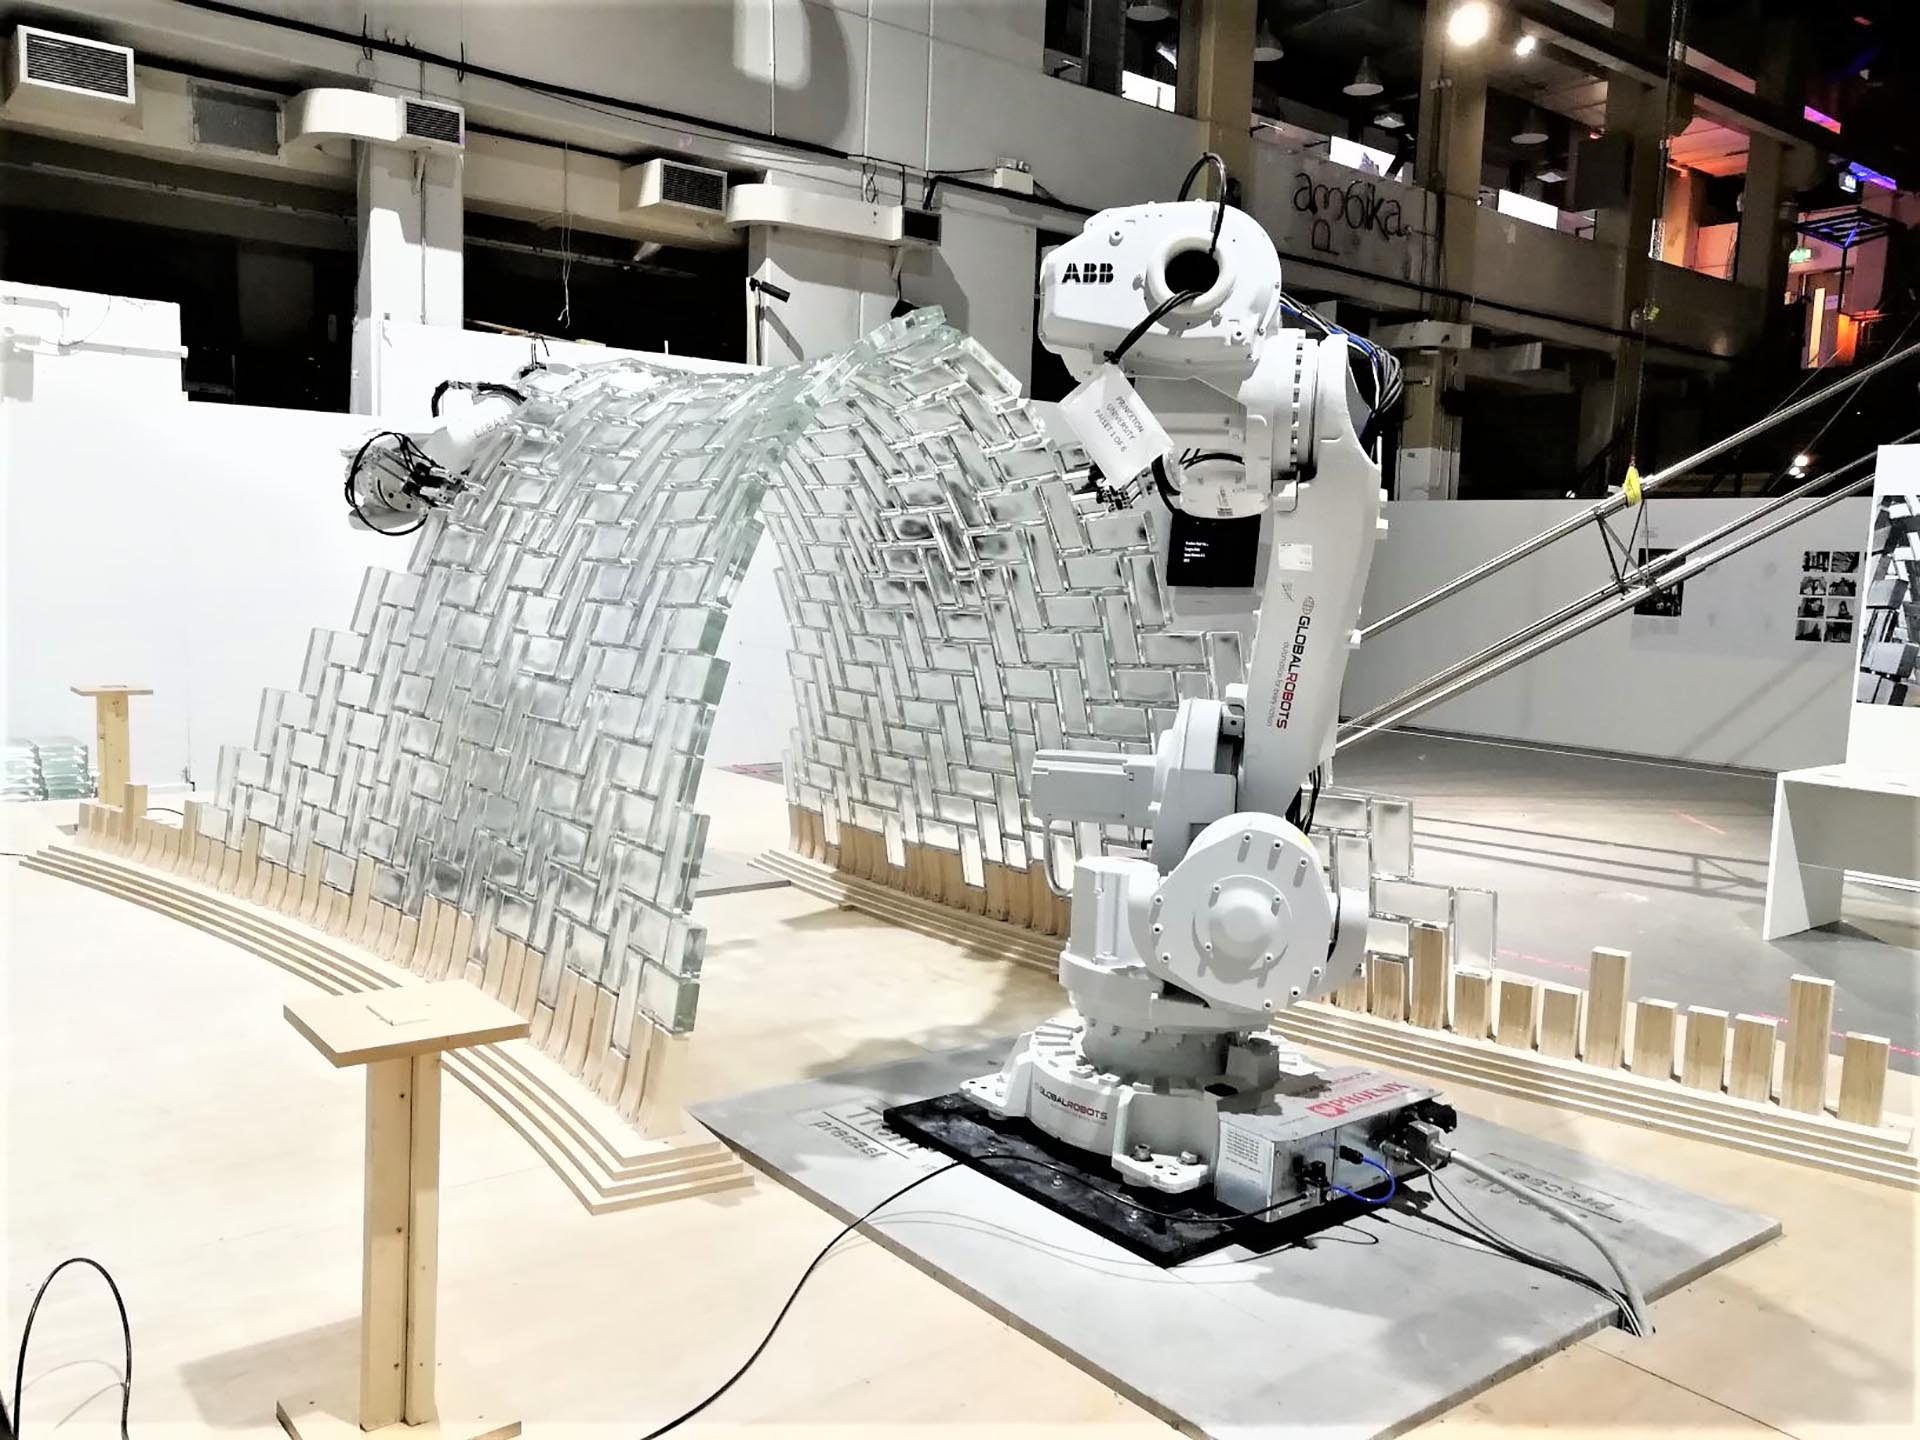
CRCL
Lab for Creative Computation

Prof. Dr. Stefana Parascho Email logo Instagram logo LinkedIn logo

 About 

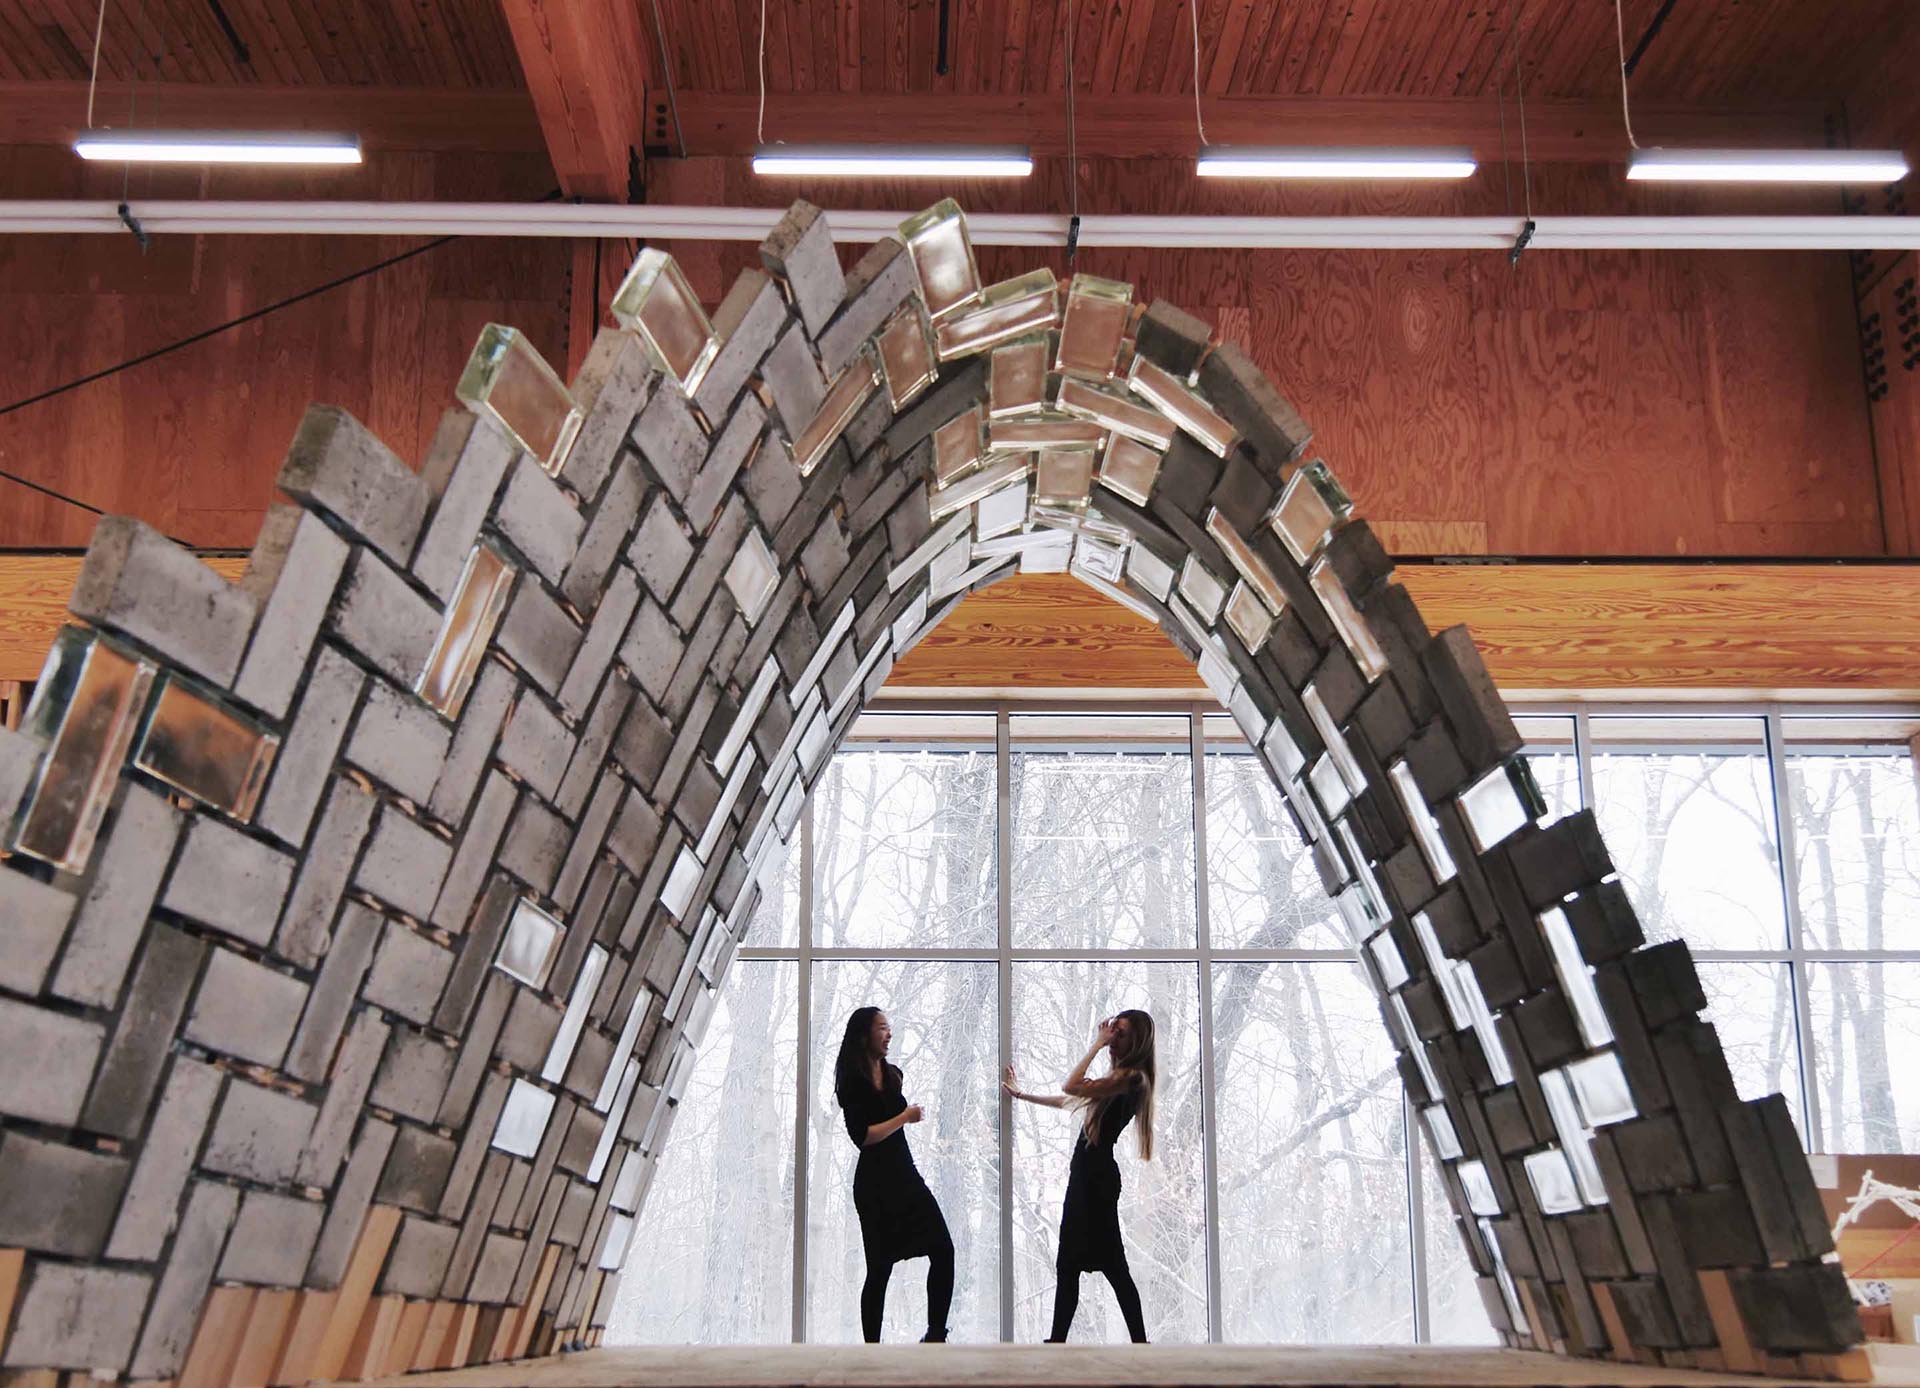
The Lab for Creative Computation - CRCL /ˈsəːkl/ - seeks to put forward non-linear construction processes that employ digital means from a human-centric perspective.

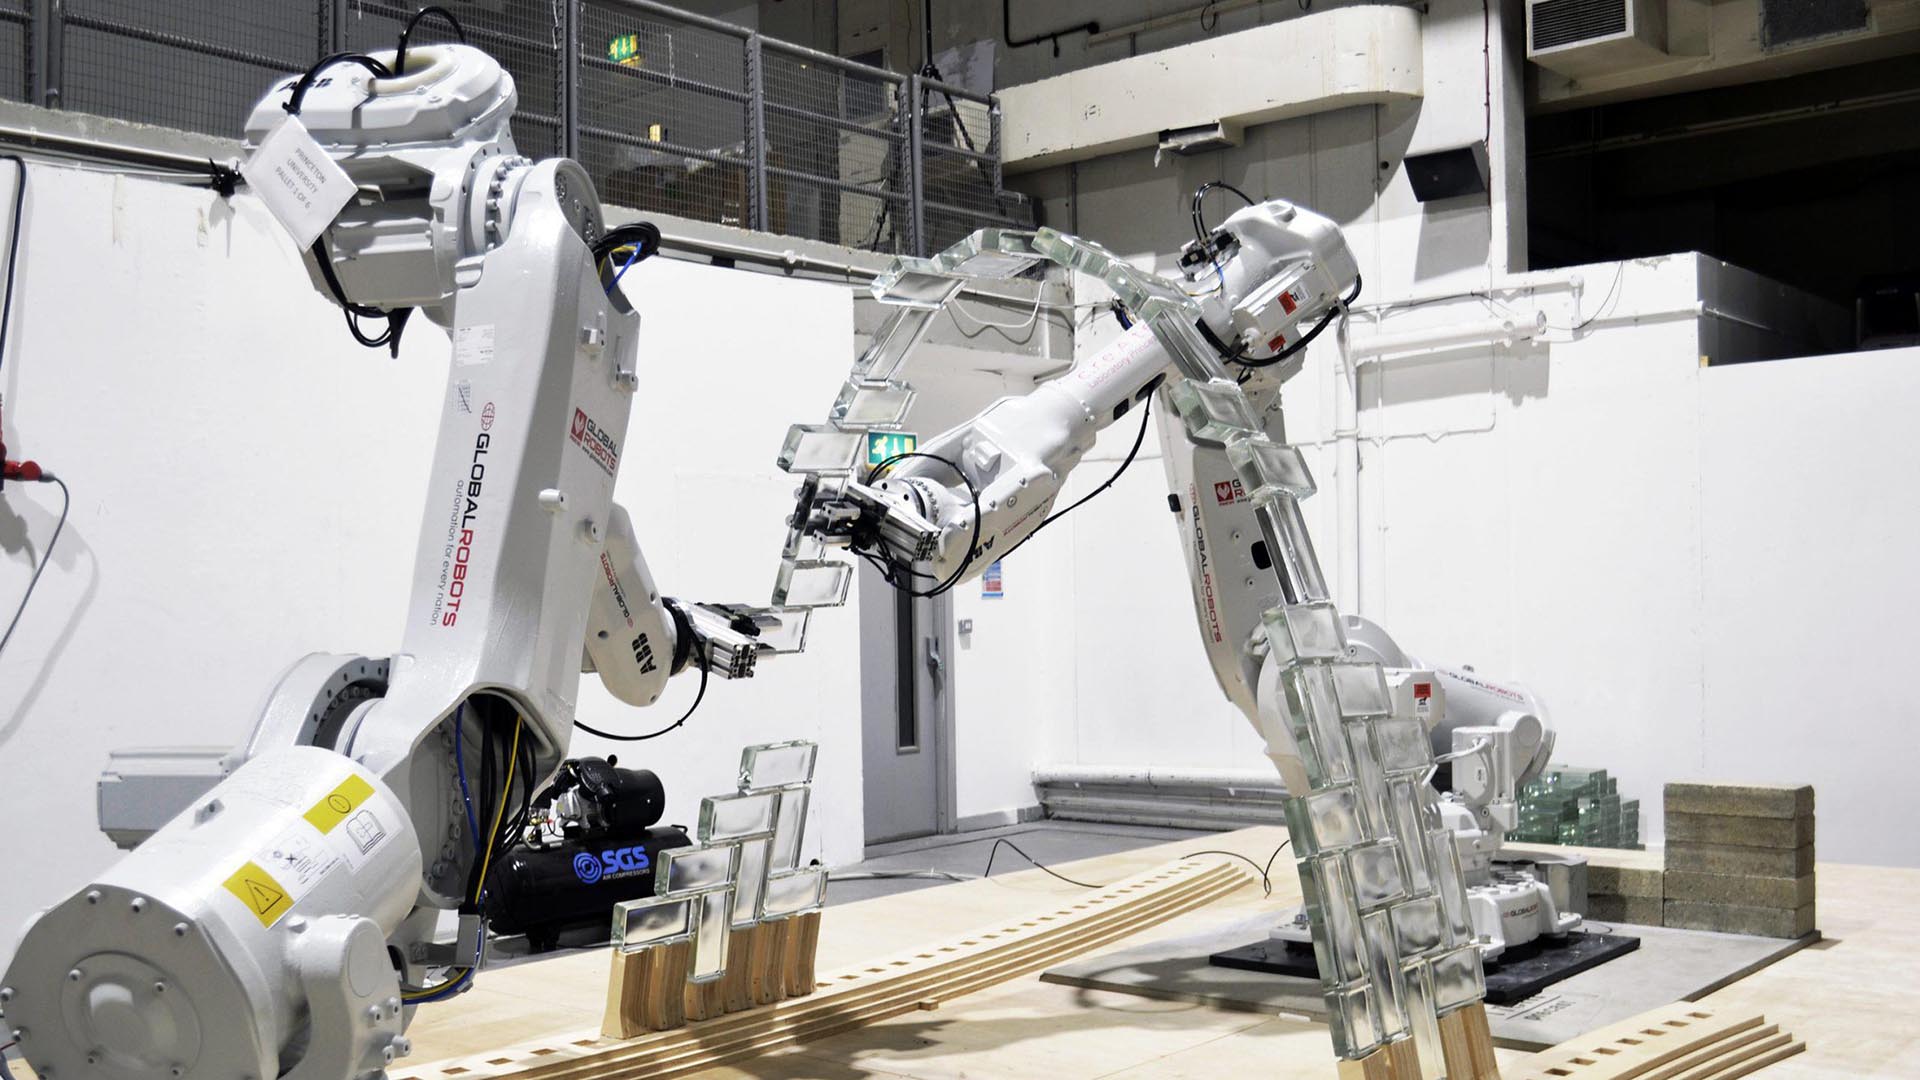
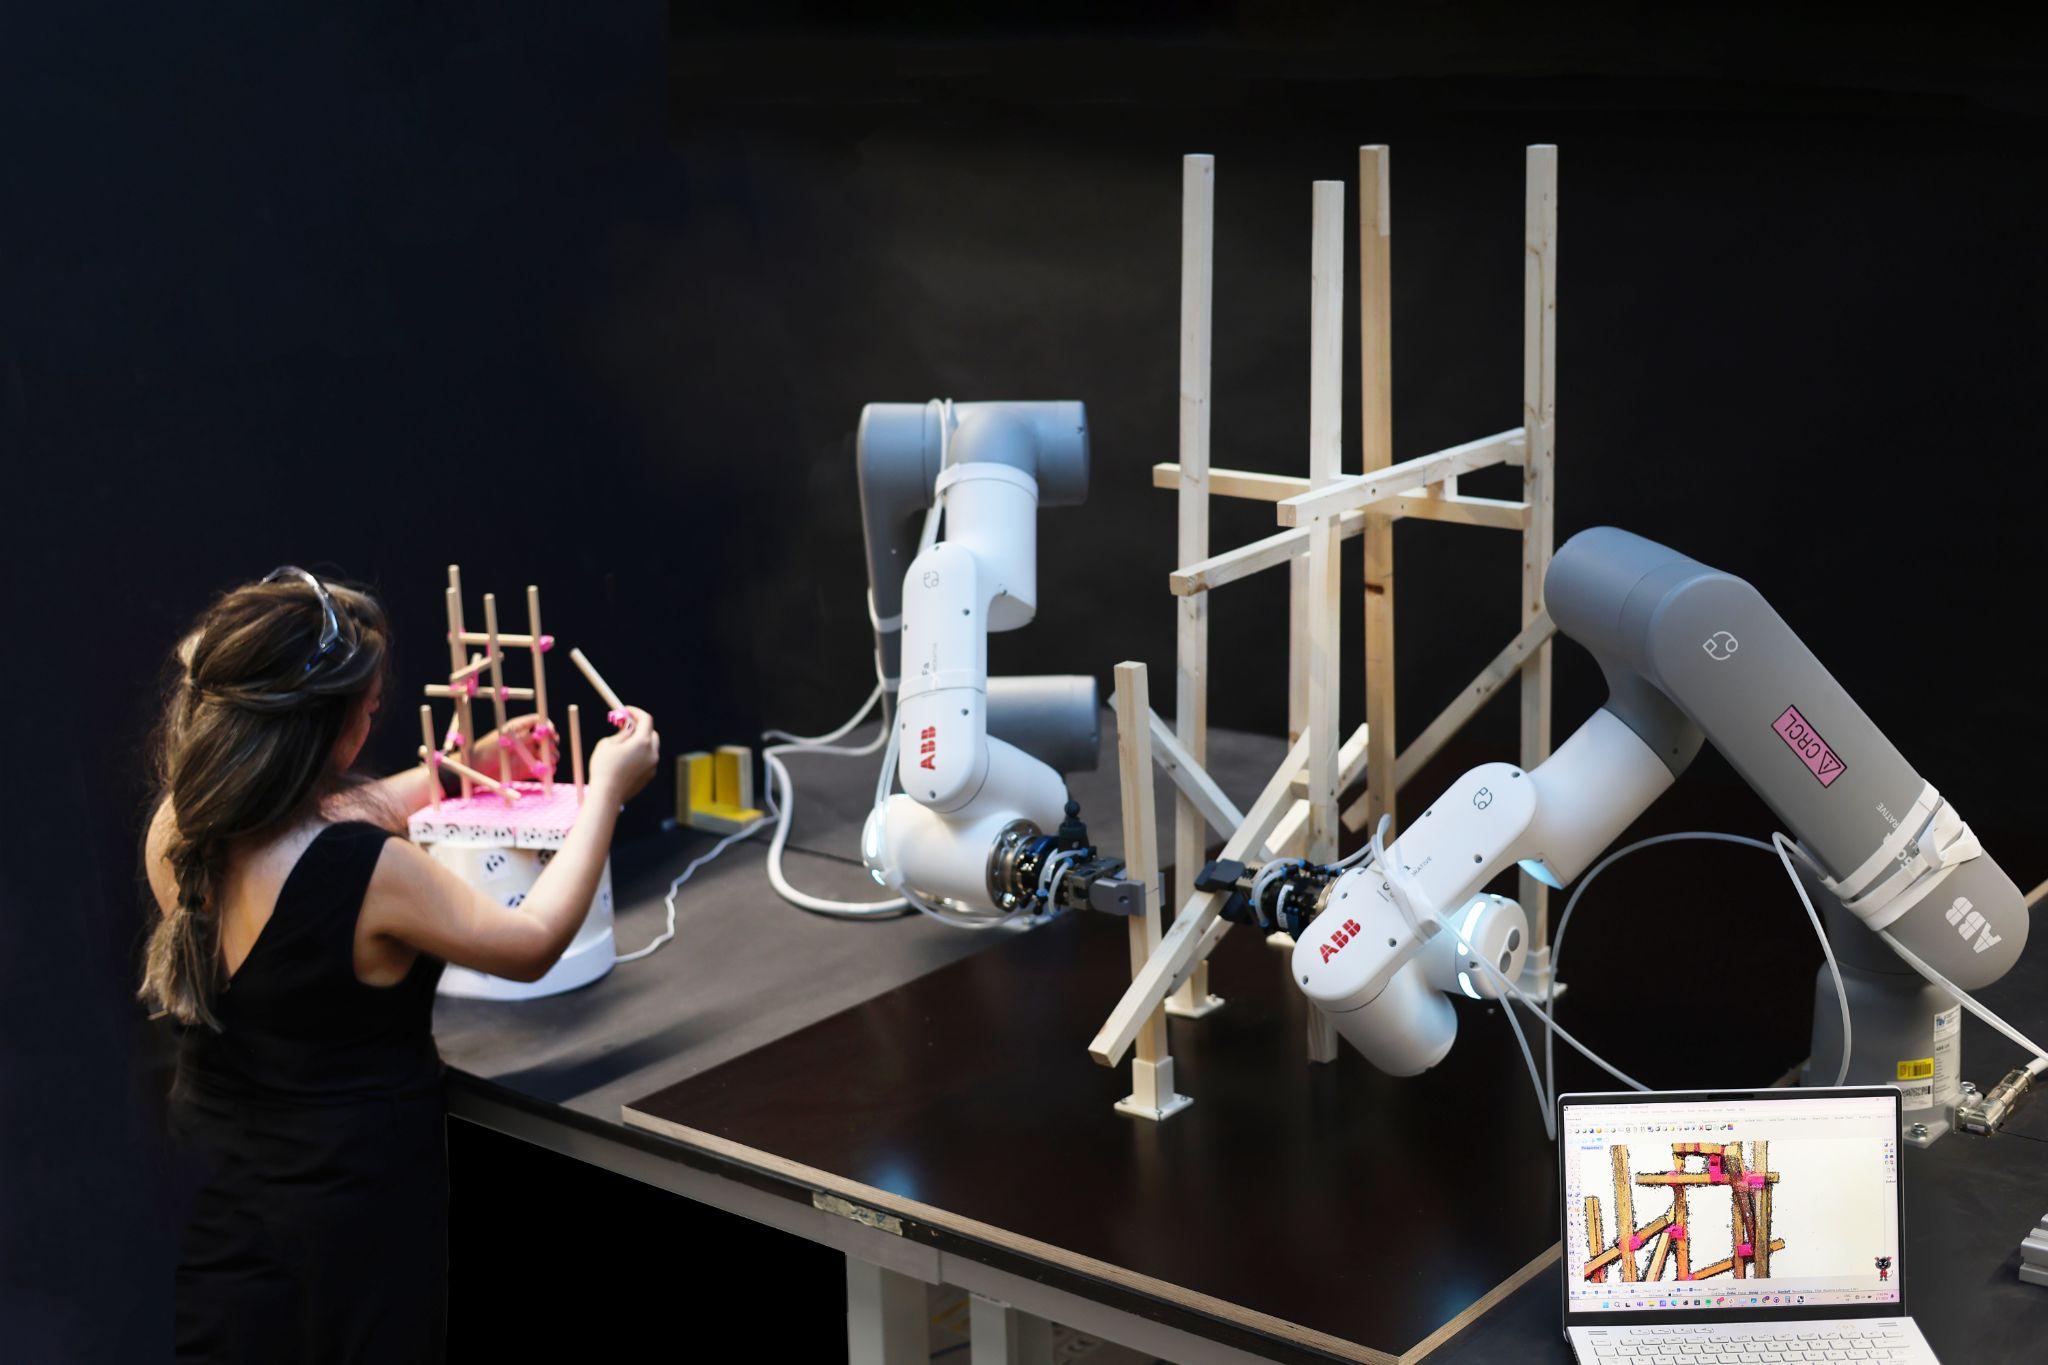
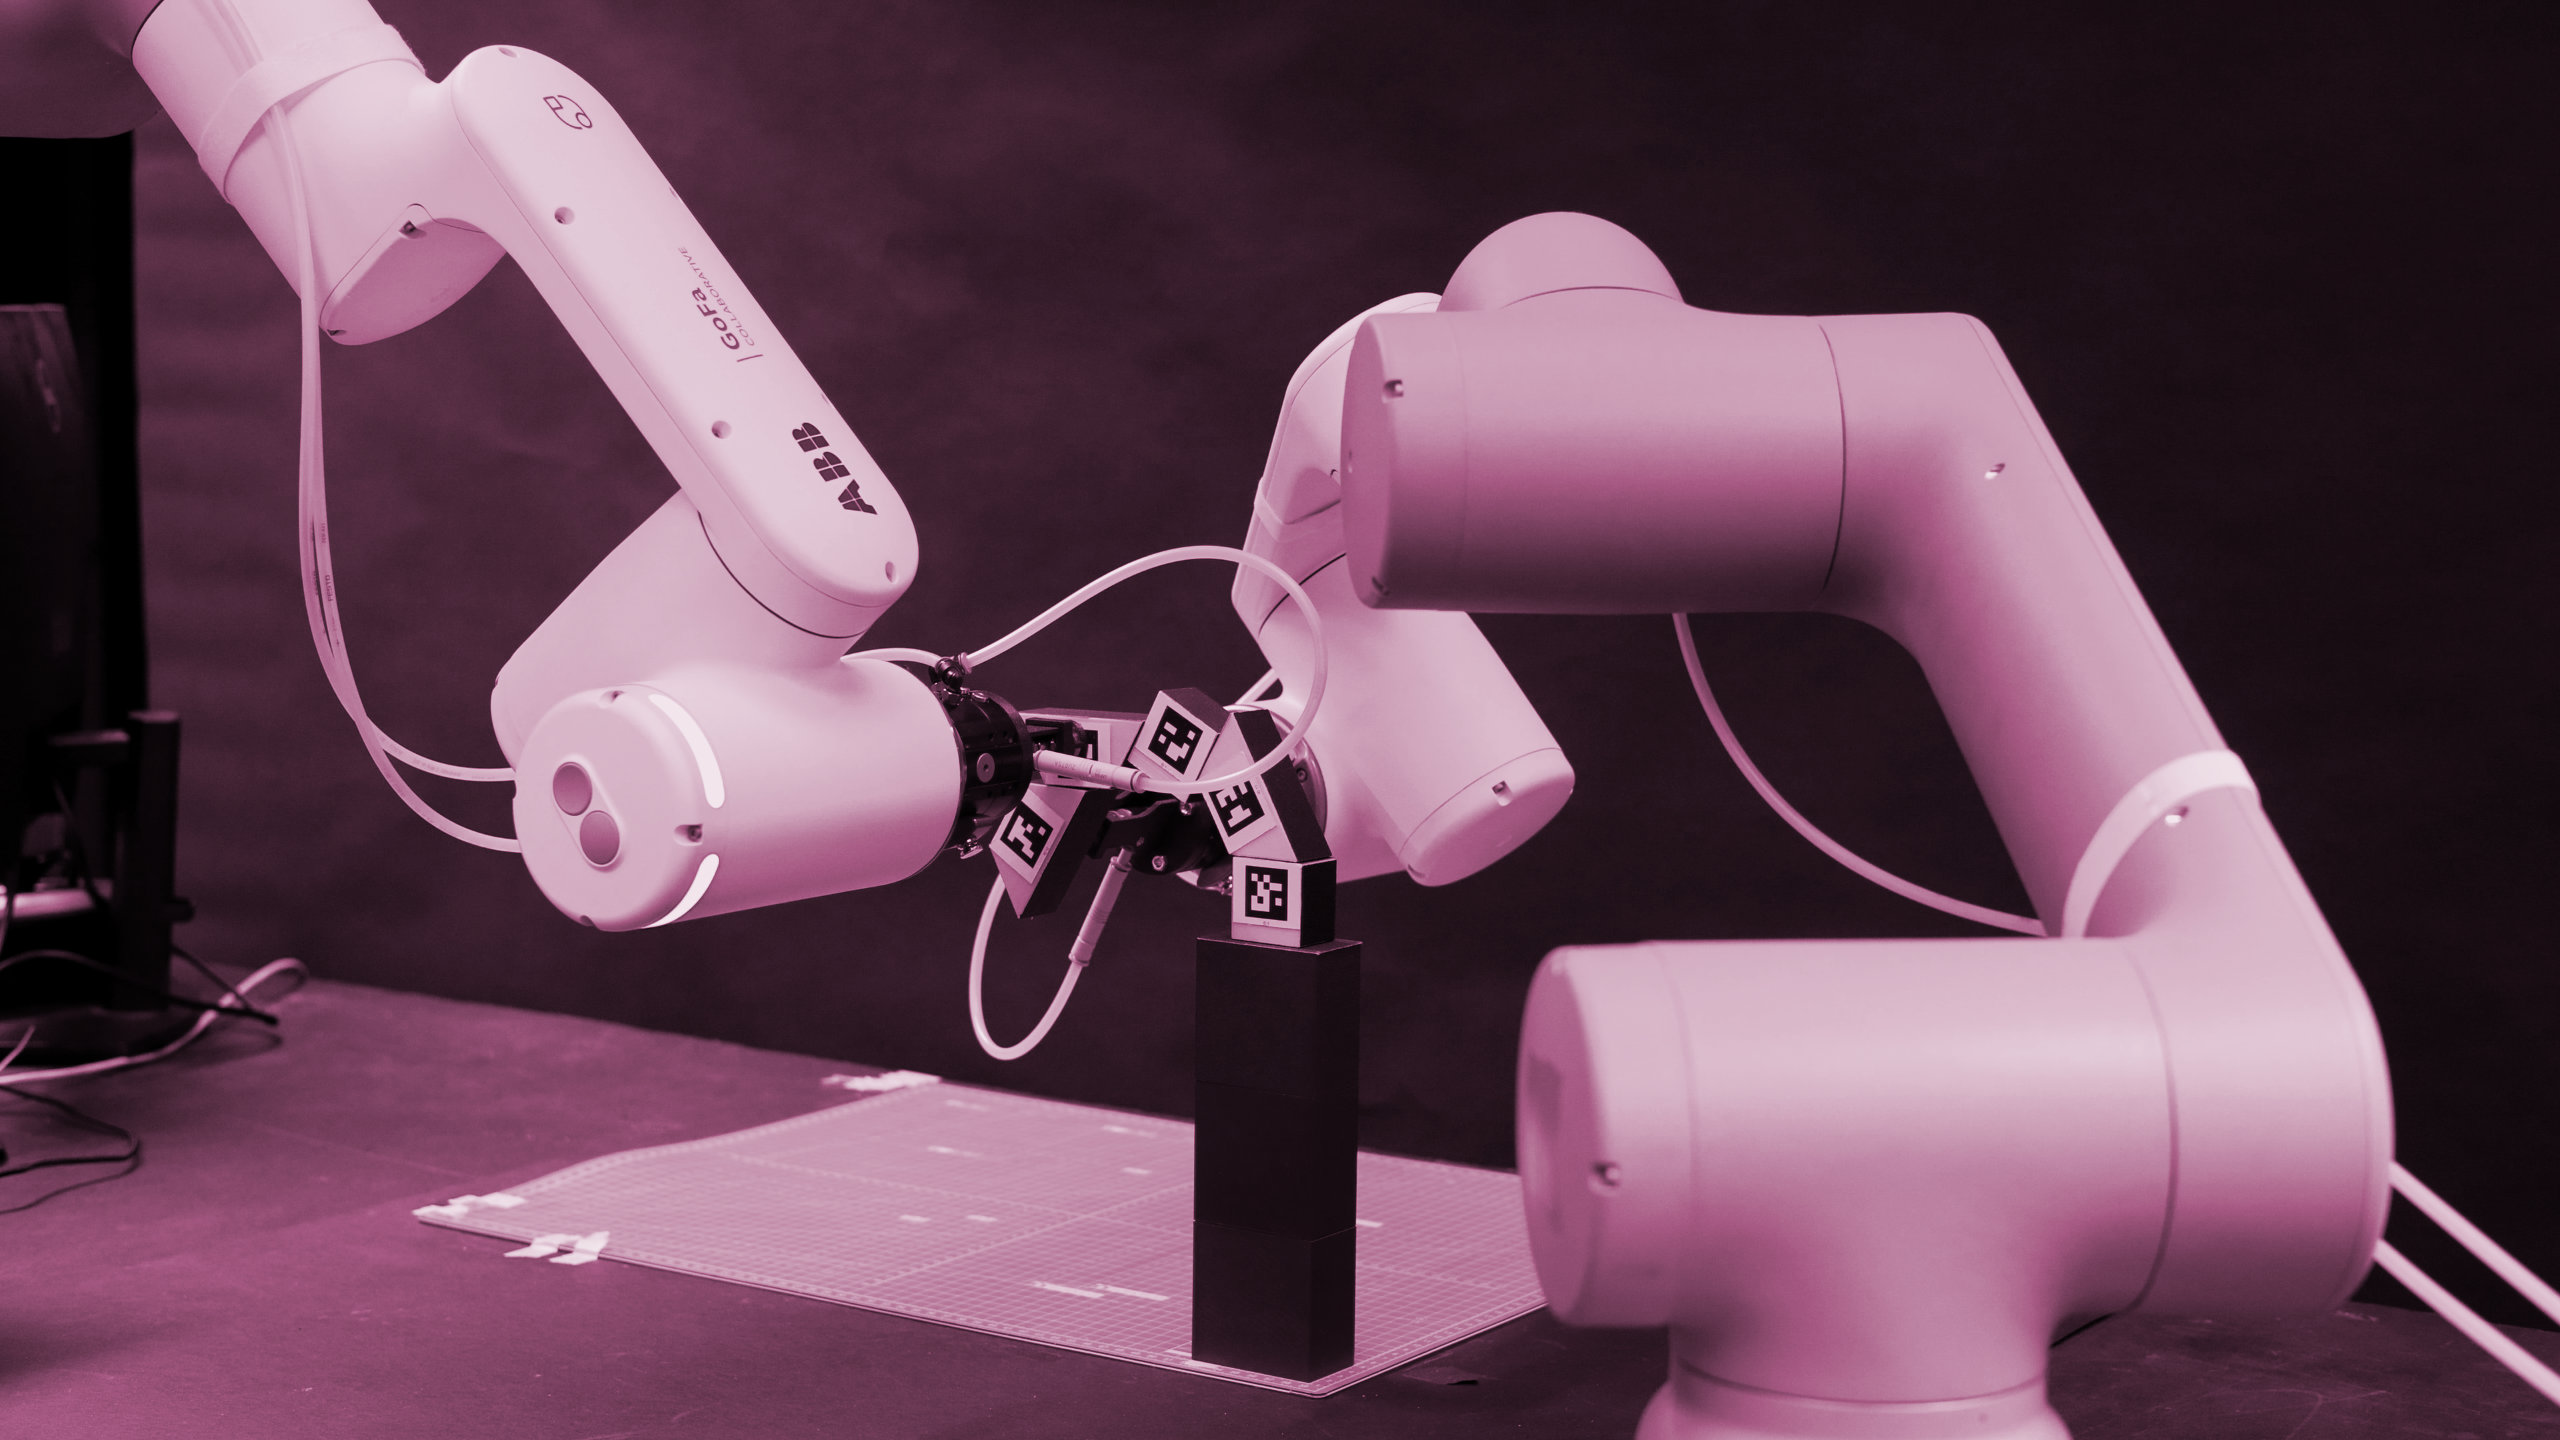
We explore new construction modes that combine robotics with human interventions and digital media, in pursuit of more creative solutions to contemporary design and construction challenges.

We question the linear workflows traditionally present in construction that promote digital means in pursuit of automating human labor, pushing humans into low-skill work or monitoring roles. Instead, we push for new modes of interaction where humans and machines support each other, where design evolves with and during construction, and where adaptability is at the core of any process.

Our work targets three fundamental challenges:

  • the climate crisis - We adapt to available materials and move away from standardized cheap but harmful ones
  • human labor - We prioritize the human experience over productivity while keeping construction efficient
  • accessibility and diversity - We strive for intuitive processes that are inclusive toward anyone who wants to engage with construction, regardless of physical abilities, gender, or background.

Showcasing scientific research and the rigor that it requires, combined with a playful and accessible approach to technical topics such as programming and robotics, CRCL strives to break down the barriers for novices to enter the field. We fully embrace experimentation, acknowledging and accepting the failures that inevitably accompany it.

Through this work, we are building towards new interaction experiences between humans and machines, where design and engineering, digital and analog work together.
 News 

  1. NEW

    Design Modelling Symposium 2026 banner, EPFL Lausanne and Fribourg, September 10-12
    In just a few days, the 2026 edition of the Design Modelling Symposium will kick off in Lausanne! CRCL will host the first part of the event, with speakers, a hackathon, and lab + exhibition tours!
    🎤💻🦾
  2. NEW

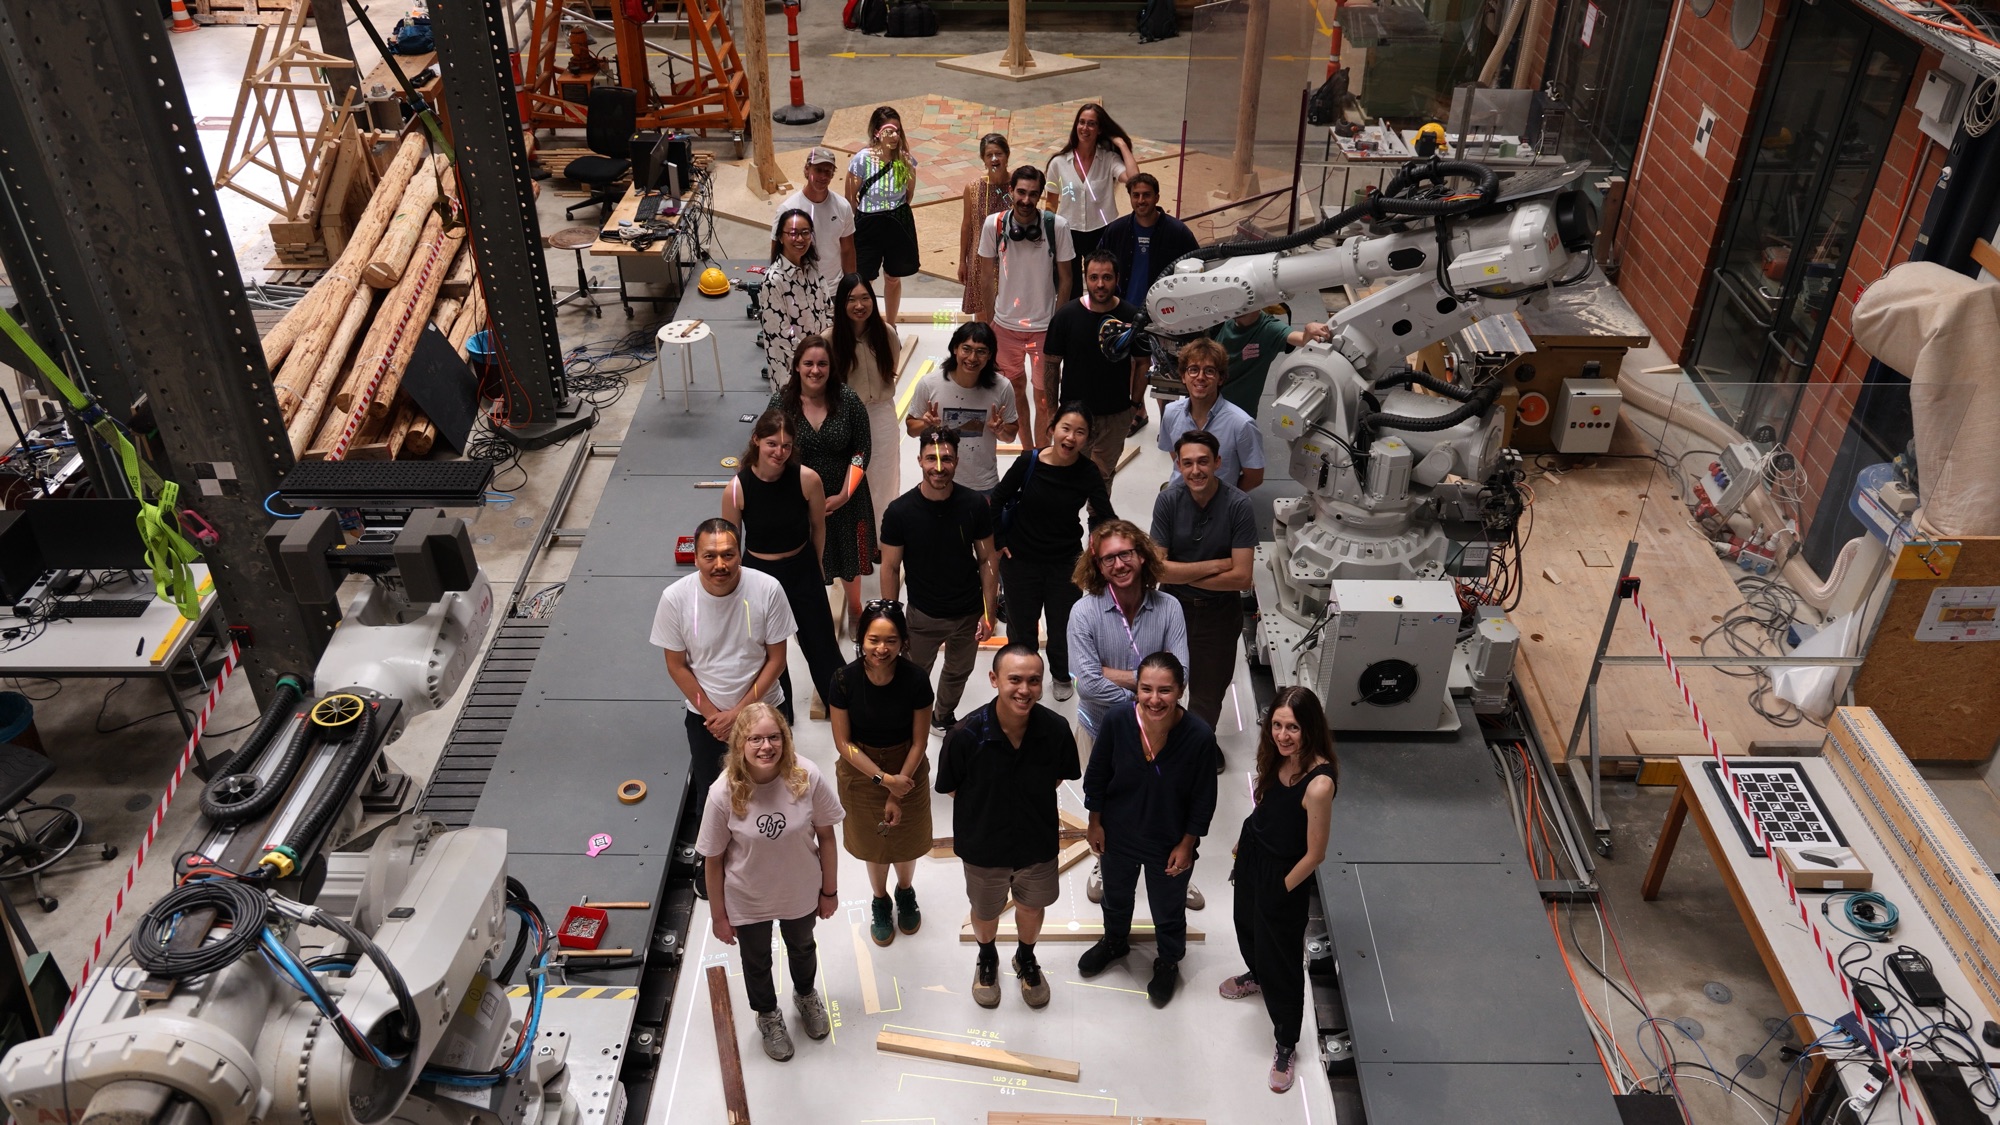
    Group photo of the Capitalizing on Uncertainty summer school participants between two industrial robots in the lab
    Our week of experimentation, discussion, and fabrication around the topic of uncertainty is now done! Thanks to all of the students and lecturers who were a part of Capitalizing on Uncertainty, and look forward to a publication to come!
    💡🧠💡
  3. NEW

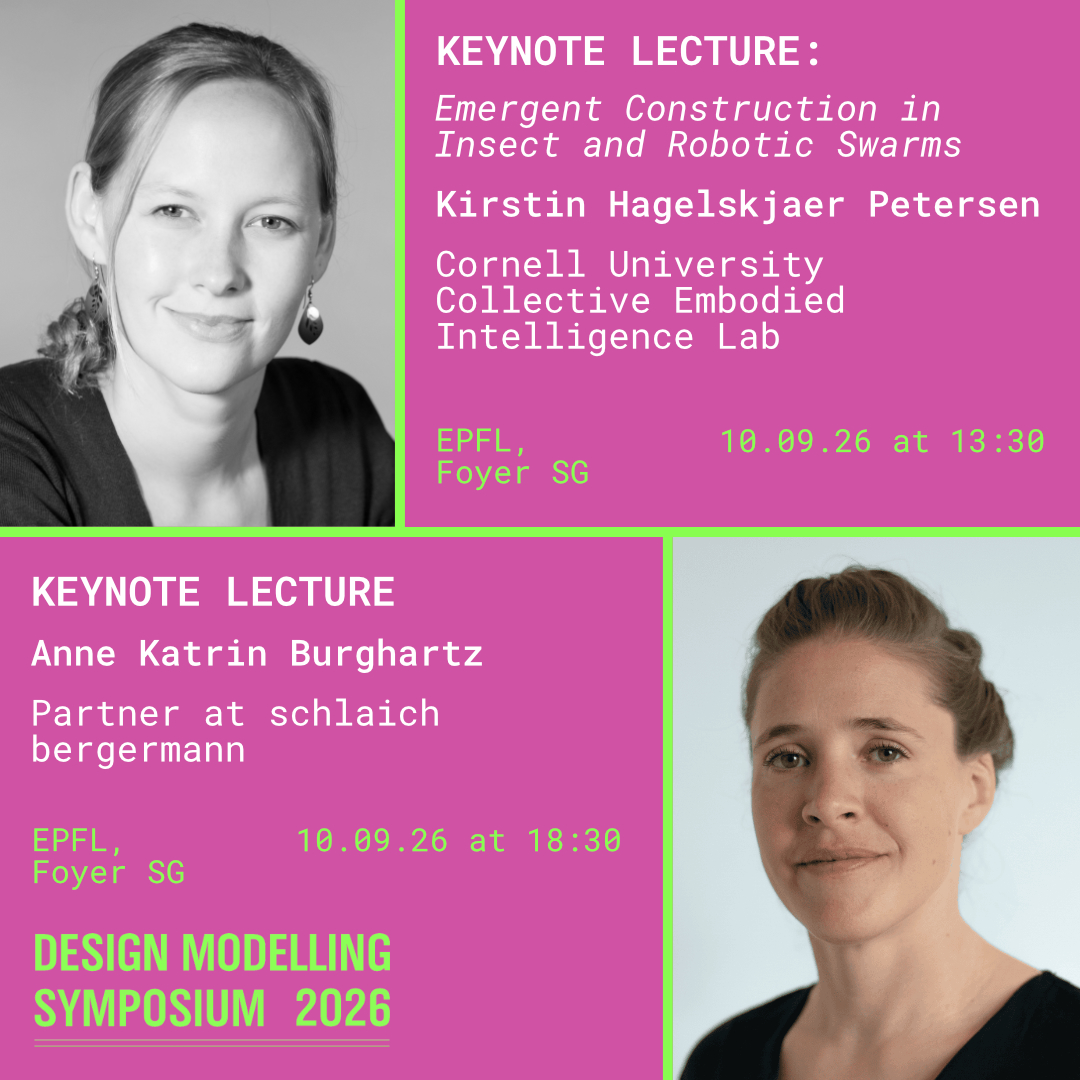
    Keynote lecture graphic for Kirstin Hagelskjaer Petersen and Anne Katrin Burghartz at the Design Modelling Symposium 2026

    We're excited to welcome two keynote speakers in Lausanne as part of the Design Modelling Symposium 2026 on Sept 10: Kirstin Hagelskjaer Petersen and Anne Katrin Burghartz.

    Join the public lectures to learn more about swarm robotics and engineering building-scale art pieces!


    🐝🤖🎨
  4. NEW

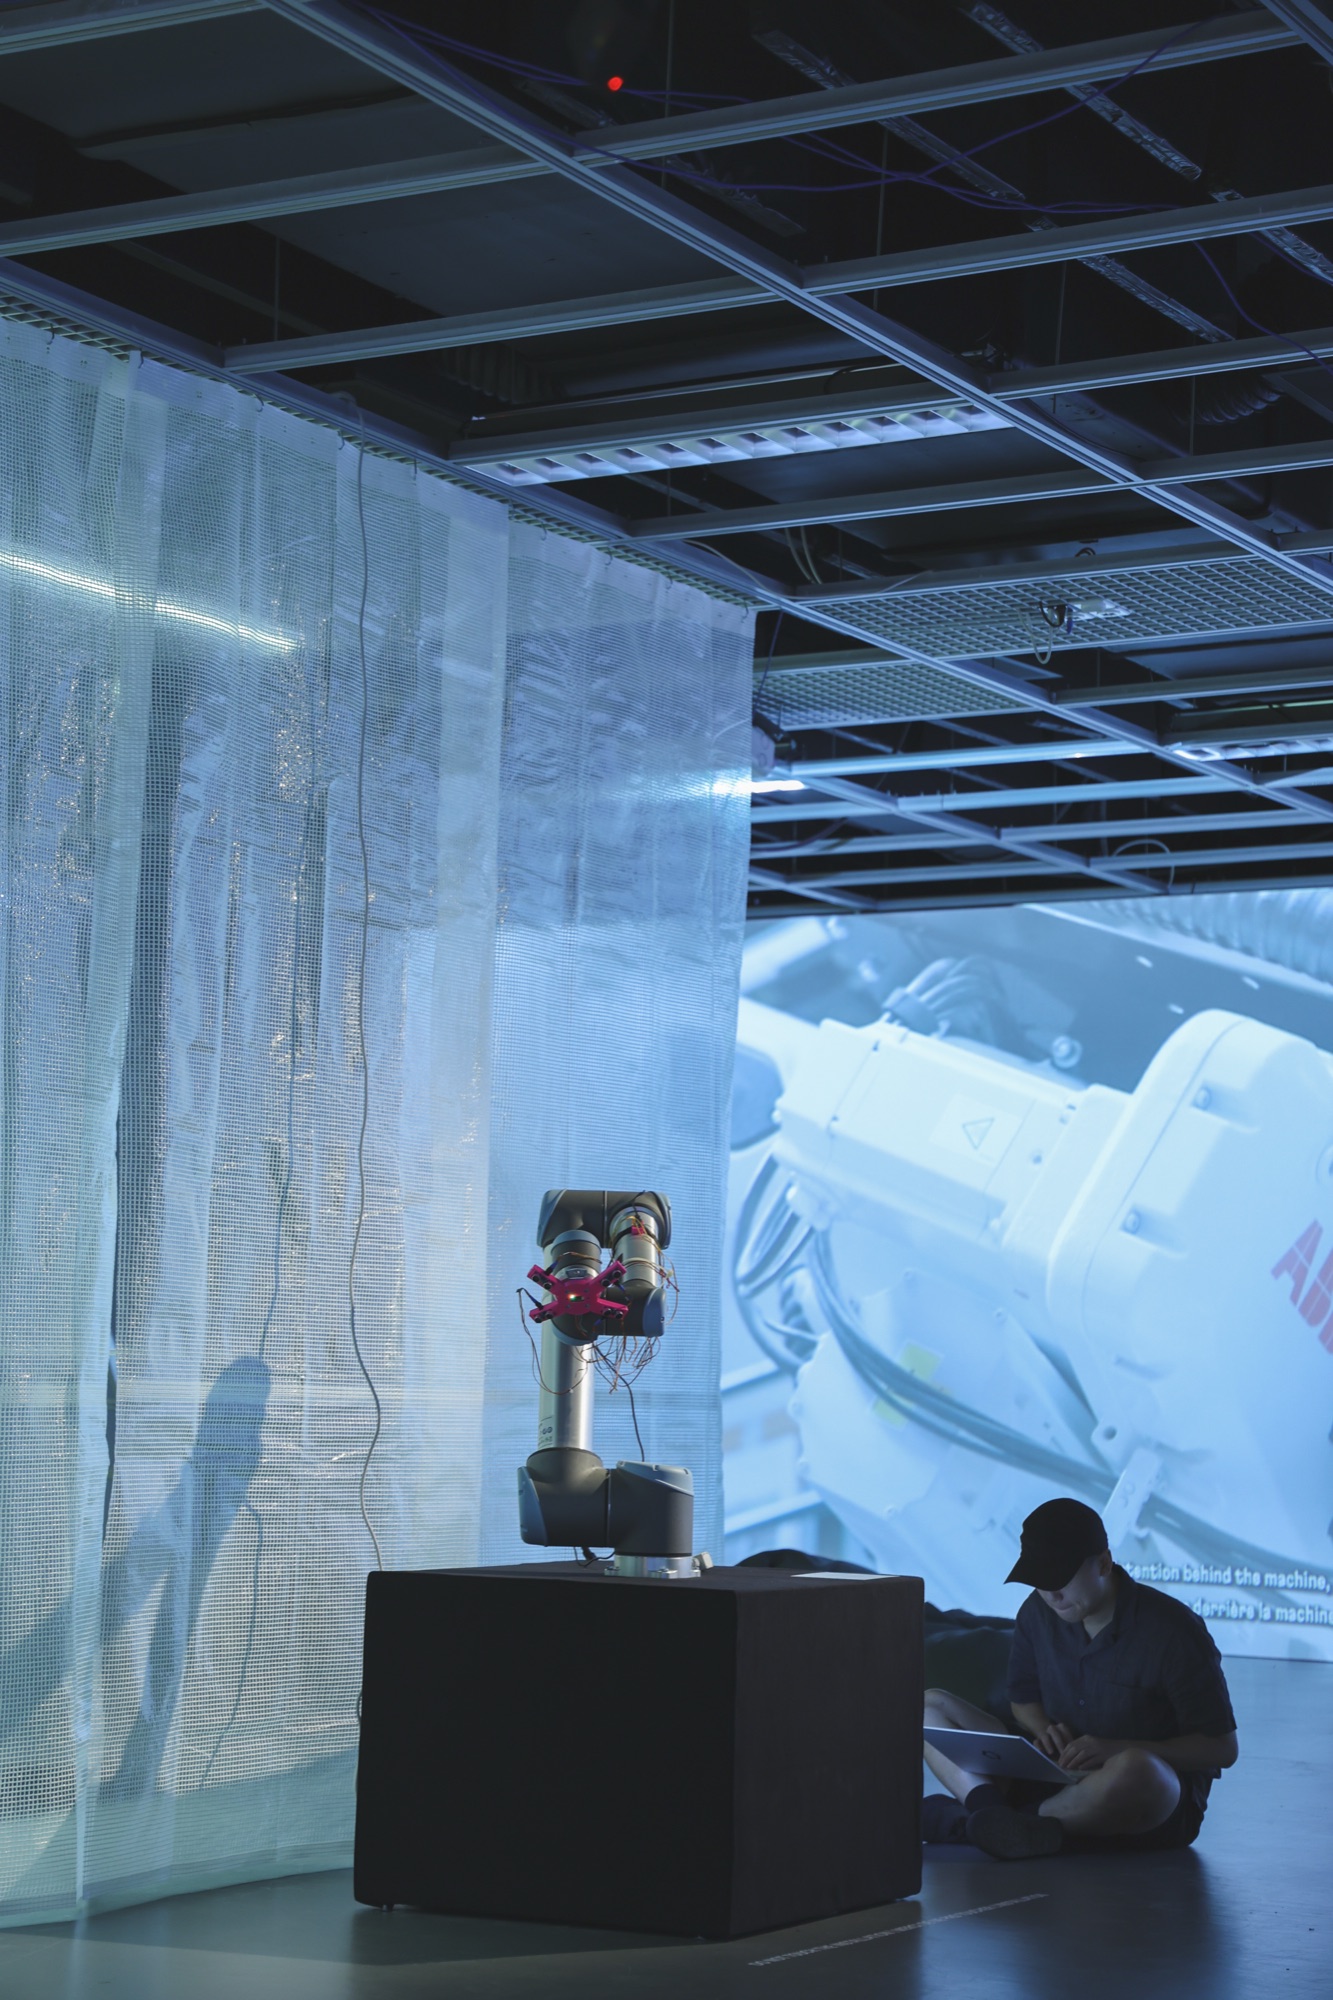
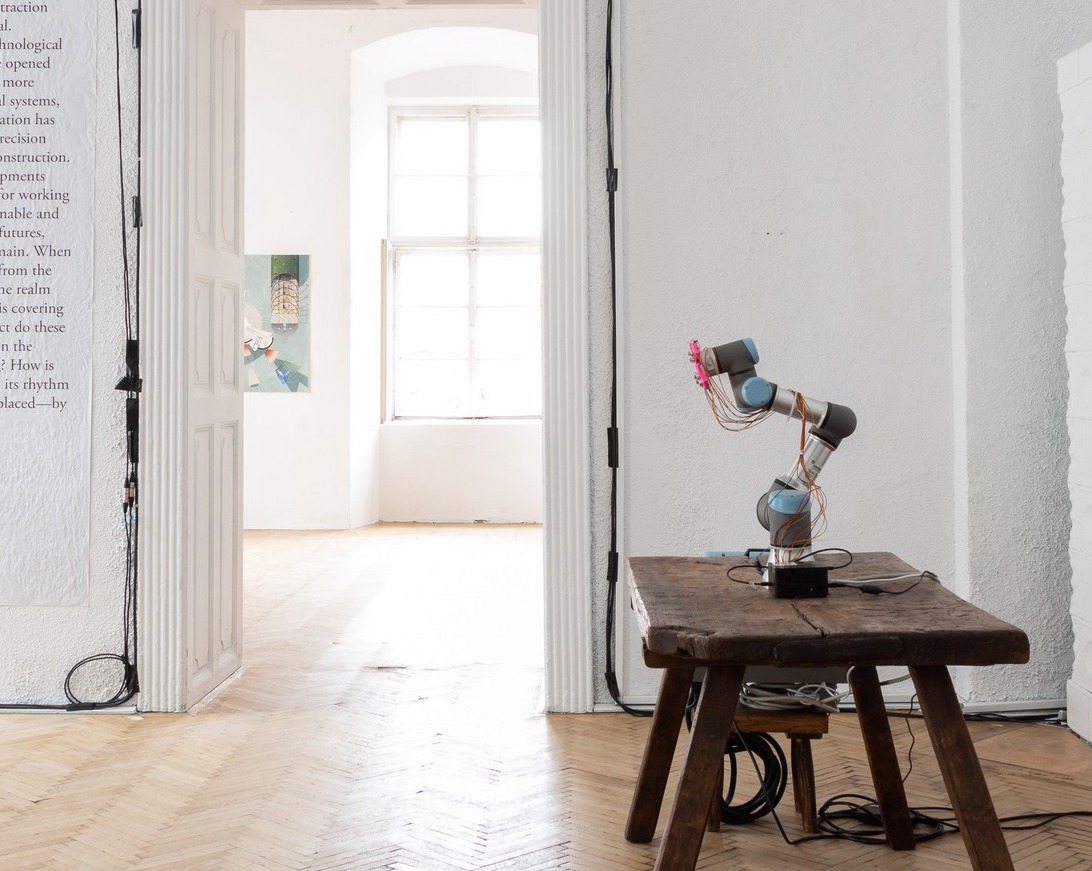
    Robot arm on a plinth in the exhibition at Archizoom, with a film projected on the wall behind

    Next week our exhibition will open! Do Robots Dream of Construction Sites? takes over Archizoom at EPFL with live robot demos, prototypes, films, and research from the lab, all asking what roles robots should play in construction.

    Join us for the vernissage on Tuesday, 8 September at 18:15, with a discussion between Stefana Parascho and Aude Billard, moderated by Pier Vittorio Aureli, followed by welcome drinks.

    Can't make the opening? The exhibition runs from 9 September to 5 December 2026.


    🤖💭🏗️
  5. NEW

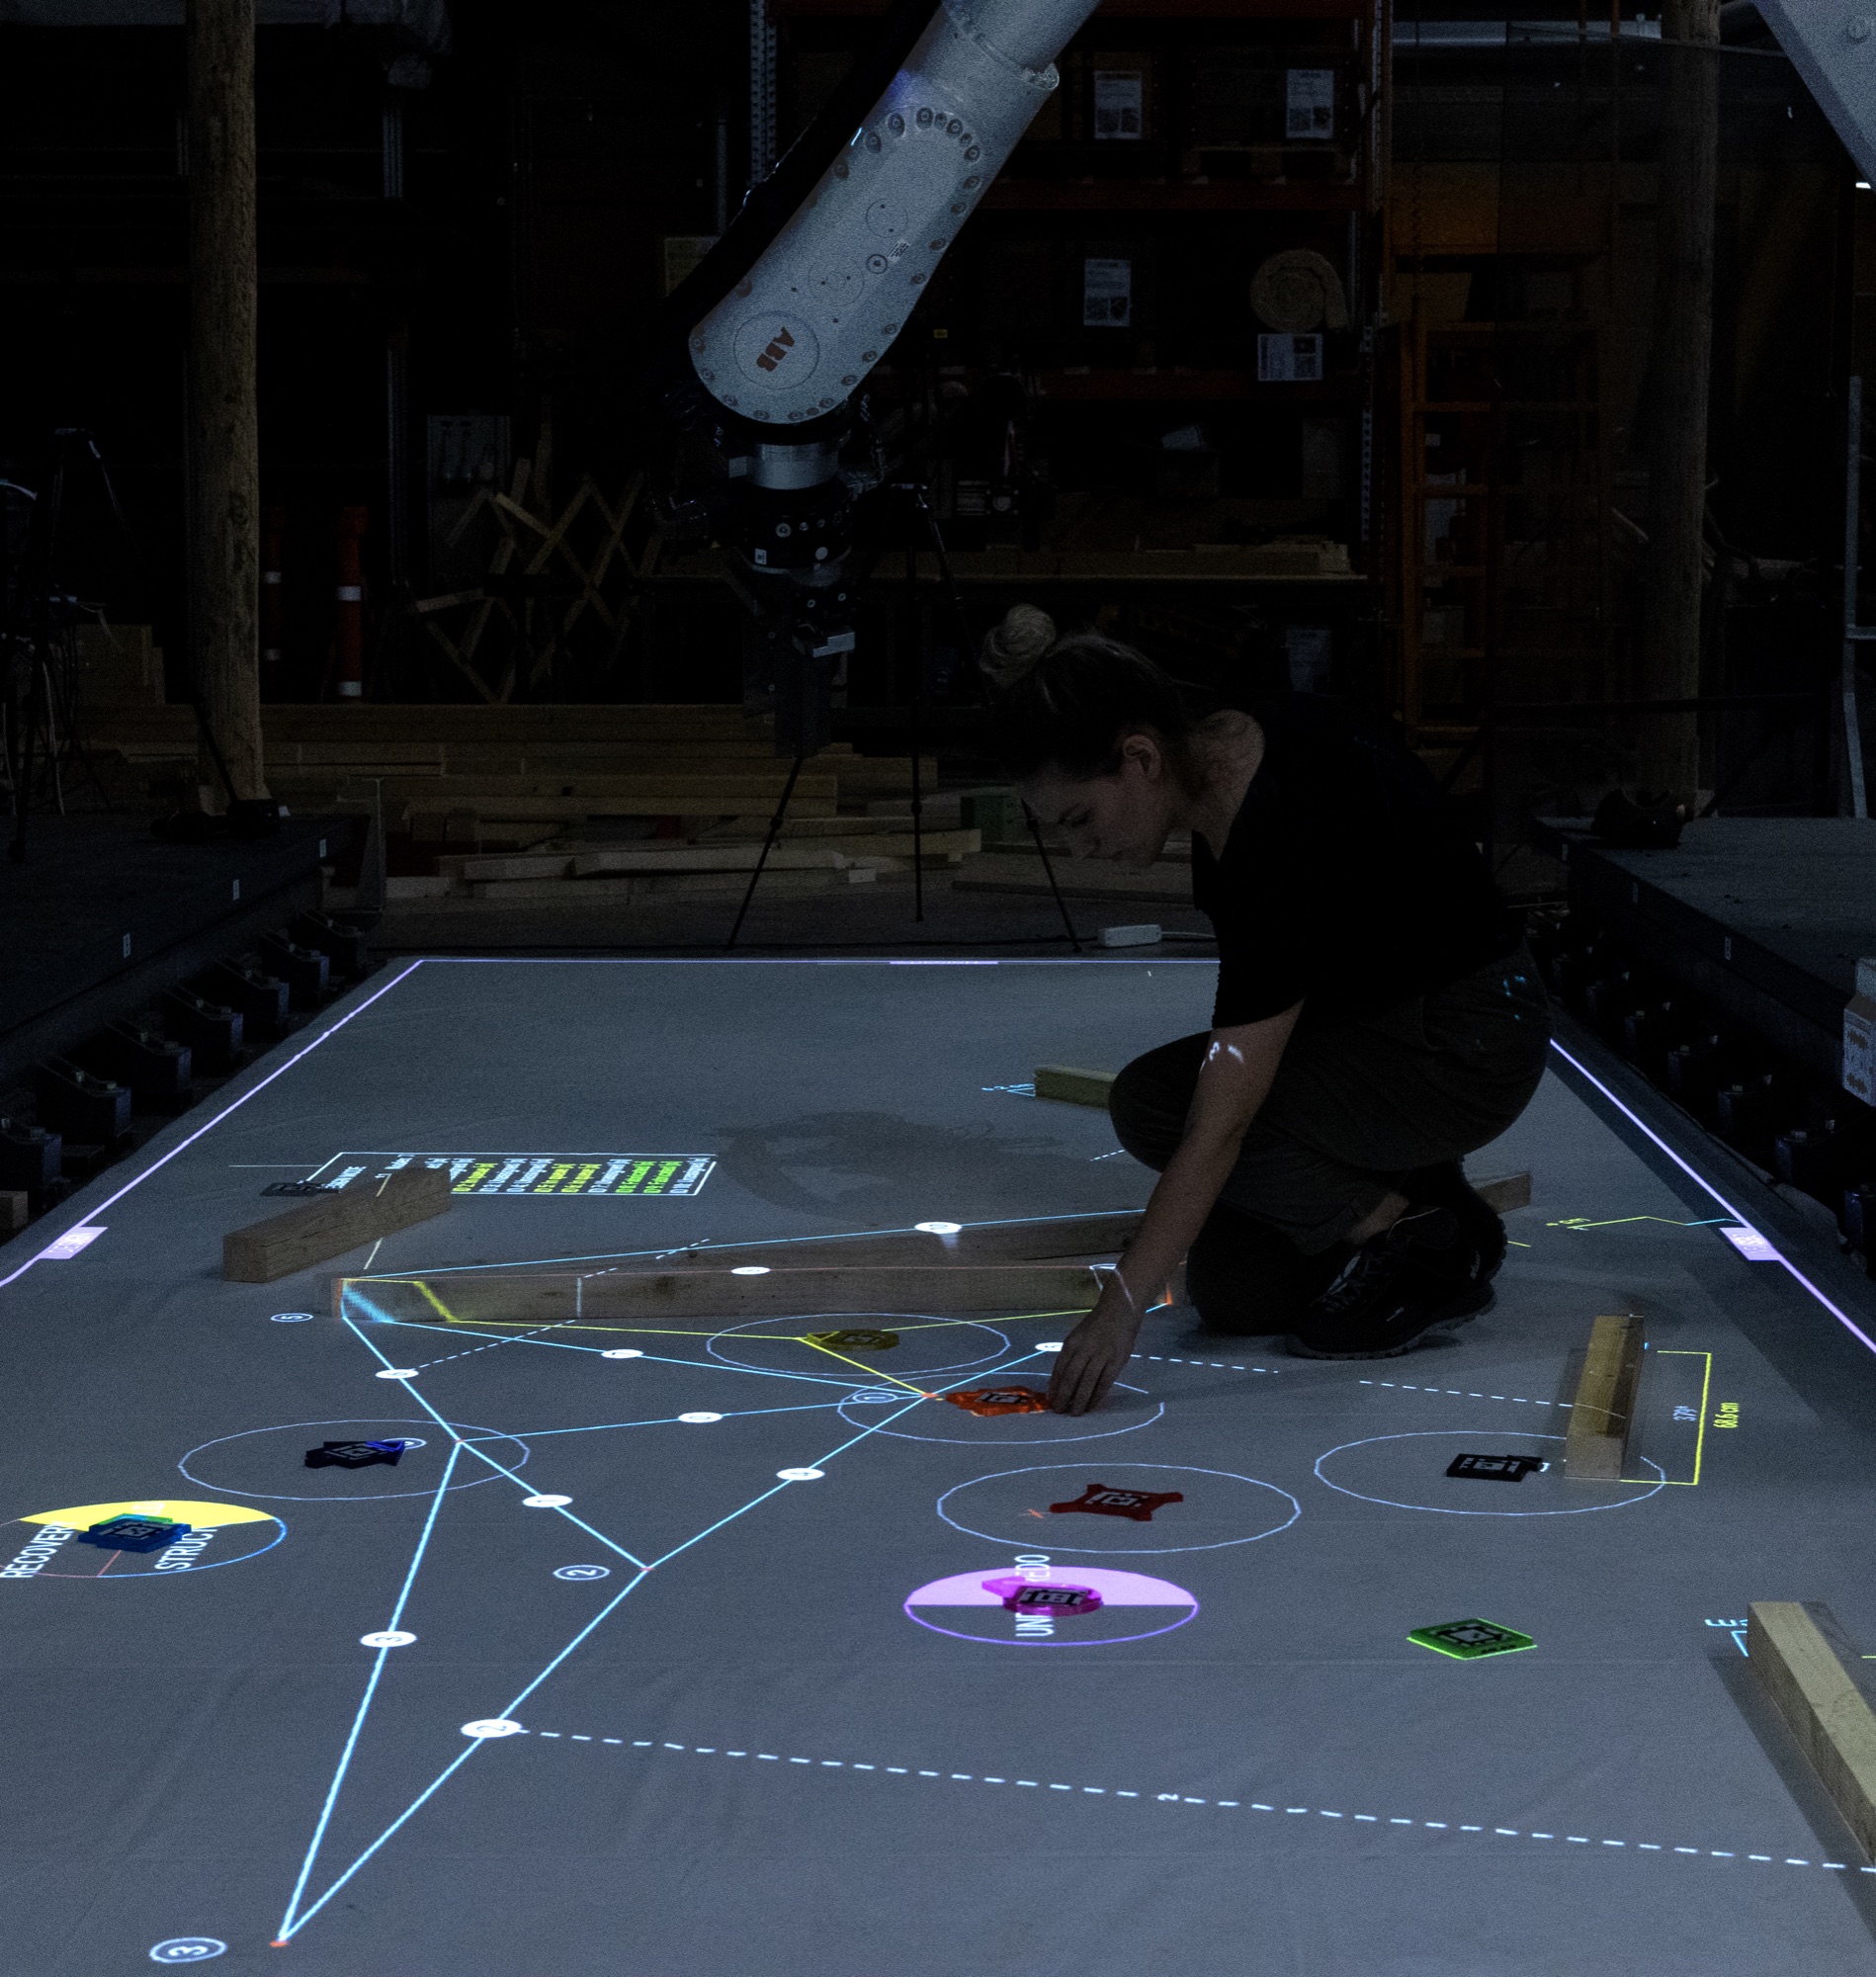
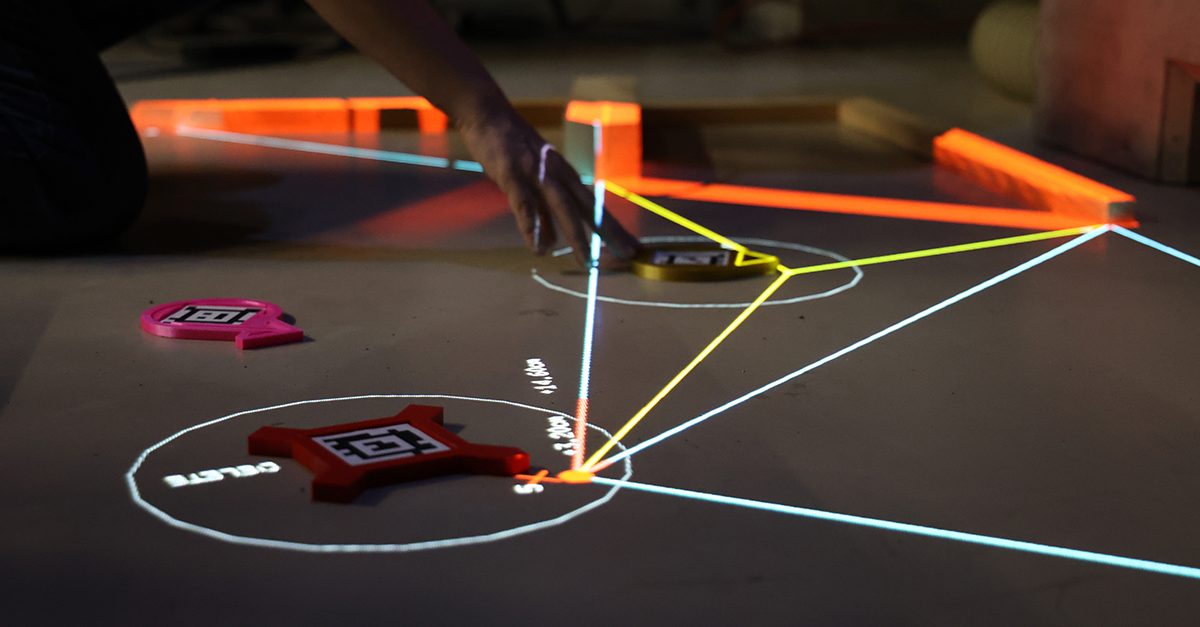
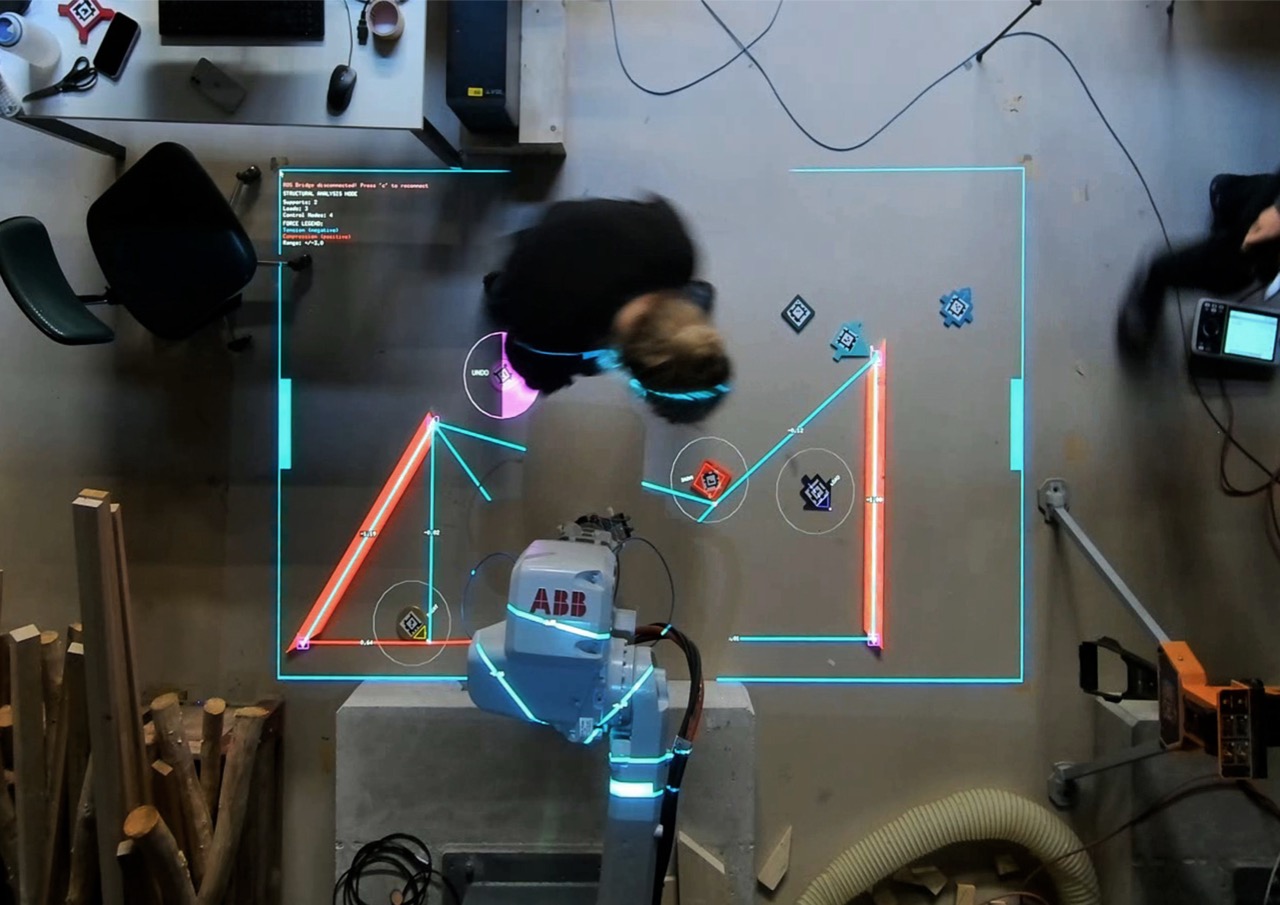
    Person arranging timber offcuts on a floor projection of a truss design, beneath a robot arm

    Eleni Skevaki will present our latest work, "Crafting structural timber trusses from irregular offcuts via human–robot interaction", at ROB|ARCH 2026 in Aarhus! Catch the talk on Thursday, 27 August in Paper Session 1 (09:30–10:45).

    Building on our Truss from Trash framework, the work adds real-time structural feedback and on-demand form-finding to the projection-based interface, so the design can adapt to the timber offcuts available at each stage of assembly.

    📄 Co-authored by Eleni Skevaki, Eric Duong, Hong-Bin Yang & Stefana Parascho. Read the paper here!


    🪵📐🤖
  6. NEW

    Poster for Capitalizing on Uncertainty summer school

    Find us at the Davos Tech Summit 2026, where we'll be presenting our lab and work as part of the Robot City!


    🏙️🤖🏙️
  7. NEW

    Poster for Capitalizing on Uncertainty summer school

    Jingwen will be presenting our work at the ICRA 2026 Uncertainty in Open-World Robotics Workshop!

    How can a robot build dry-stacked structures over long assembly horizons, when small placement deviations accumulate and reshape its future construction decisions?

    Our work explores uncertainty-aware, blueprint-free robotic assembly, combining reinforcement learning with closed-loop visual feedback to help robots adapt as the built structure evolves.

    See you at ICRA 2026!


    🧱🤖🧱
  8. Banner for Engineering Industry Day EPFL 2026
    Join us June 2 at IEEE ICRA 2026 in Vienna, where Stefana Parascho will be on the panel for session 2 of Advancing Sustainability in Robotics: From Green Design to Real-World Impact
    ♻️🦾♻️
  9. Poster for Capitalizing on Uncertainty summer school

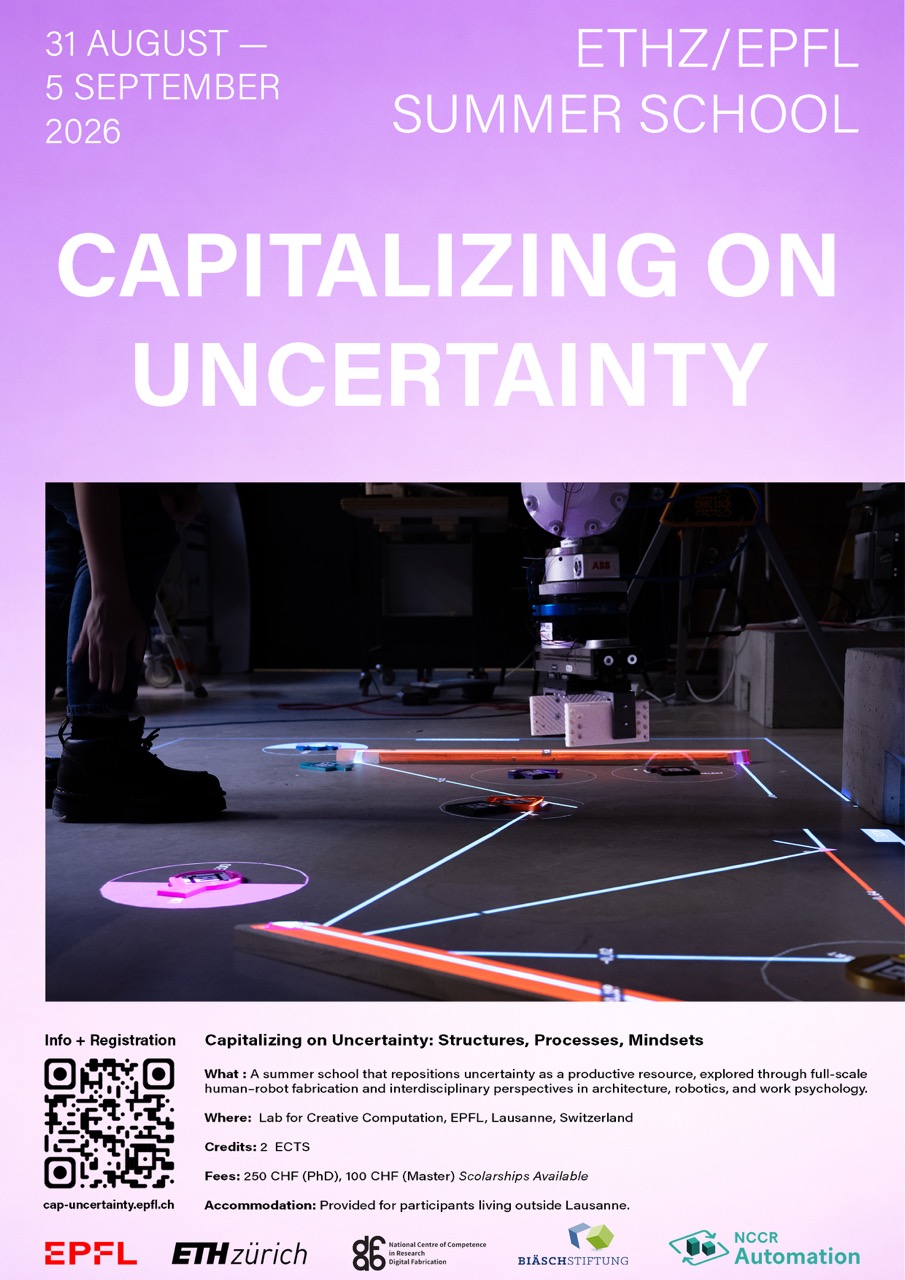
    This September, we are co-organizing a summer school with colleagues from EPFL and ETH. The program is intended for PhD students interested in exploring how uncertainty can become a productive resource through a real-world construction robotics challenge.

    The week will combine lectures across design, materials, robotics, and work psychology with a full-scale (1:1) timber build using irregular timber stock and an ABB industrial robot in a human–robot fabrication workflow.

    No previous robotics experience is required — only curiosity, openness, and your own perspective on how uncertainty shapes analysis, decision-making, and action in research and practice.

    International Students are also welcome to apply.

    More details on the program, dates, and registration are available on on the course website

    For questions: cap-uncertainty@epfl.ch


    🏗️🎓🤖
  10. Graphic for PhD position openings

    "Truss from Trash: A Human–Robot Framework for Adaptive Timber Assembly on the Construction Floor" is now published in Construction Robotics!

    The work explores how design can evolve alongside robotic fabrication, enabling real-time negotiation between design intent and material availability through situated, projection-based interaction.

    📄 Co-authored by Eleni Skevaki, Eric Duong, Hong-Bin Yang & Stefana Parascho


    🪵🤖📽️
  11. Banner for Engineering Industry Day EPFL 2026
    Find us tomorrow at Engineering Industry Day, where we'll be showcasing our latest robotic research and developments at our booth!
    📅🏭📅
  12. Photo of the robot demo from AMLD
    📸 @Samueldevantery
    If you missed the talk from Applied Machine Learning Days, you can catch up with the recording now available on YouTube! Featuring a robot demo prepared by our very own Jingwen and Megi!
    📹🎤📹
  13. Graphic for AMLD
    Join us on Tuesday, February 10th at the Applied Machine Learning Days Intelligence Summit in Lausanne! Stefana Parascho will be giving a keynote on Machine Learning for Autonomous Robotic Construction as part of the session Multimodal Intelligence in the Physical World.
    🧠🧠🧠
  14. Graphic for AMLD
    Stefana's keynote from Swiss Robotics Day, Under Construction: Building with Robots Beyond the Automation Myth is now on YouTube!
    🦾📹🦾
  15. Graphic for PhD position openings

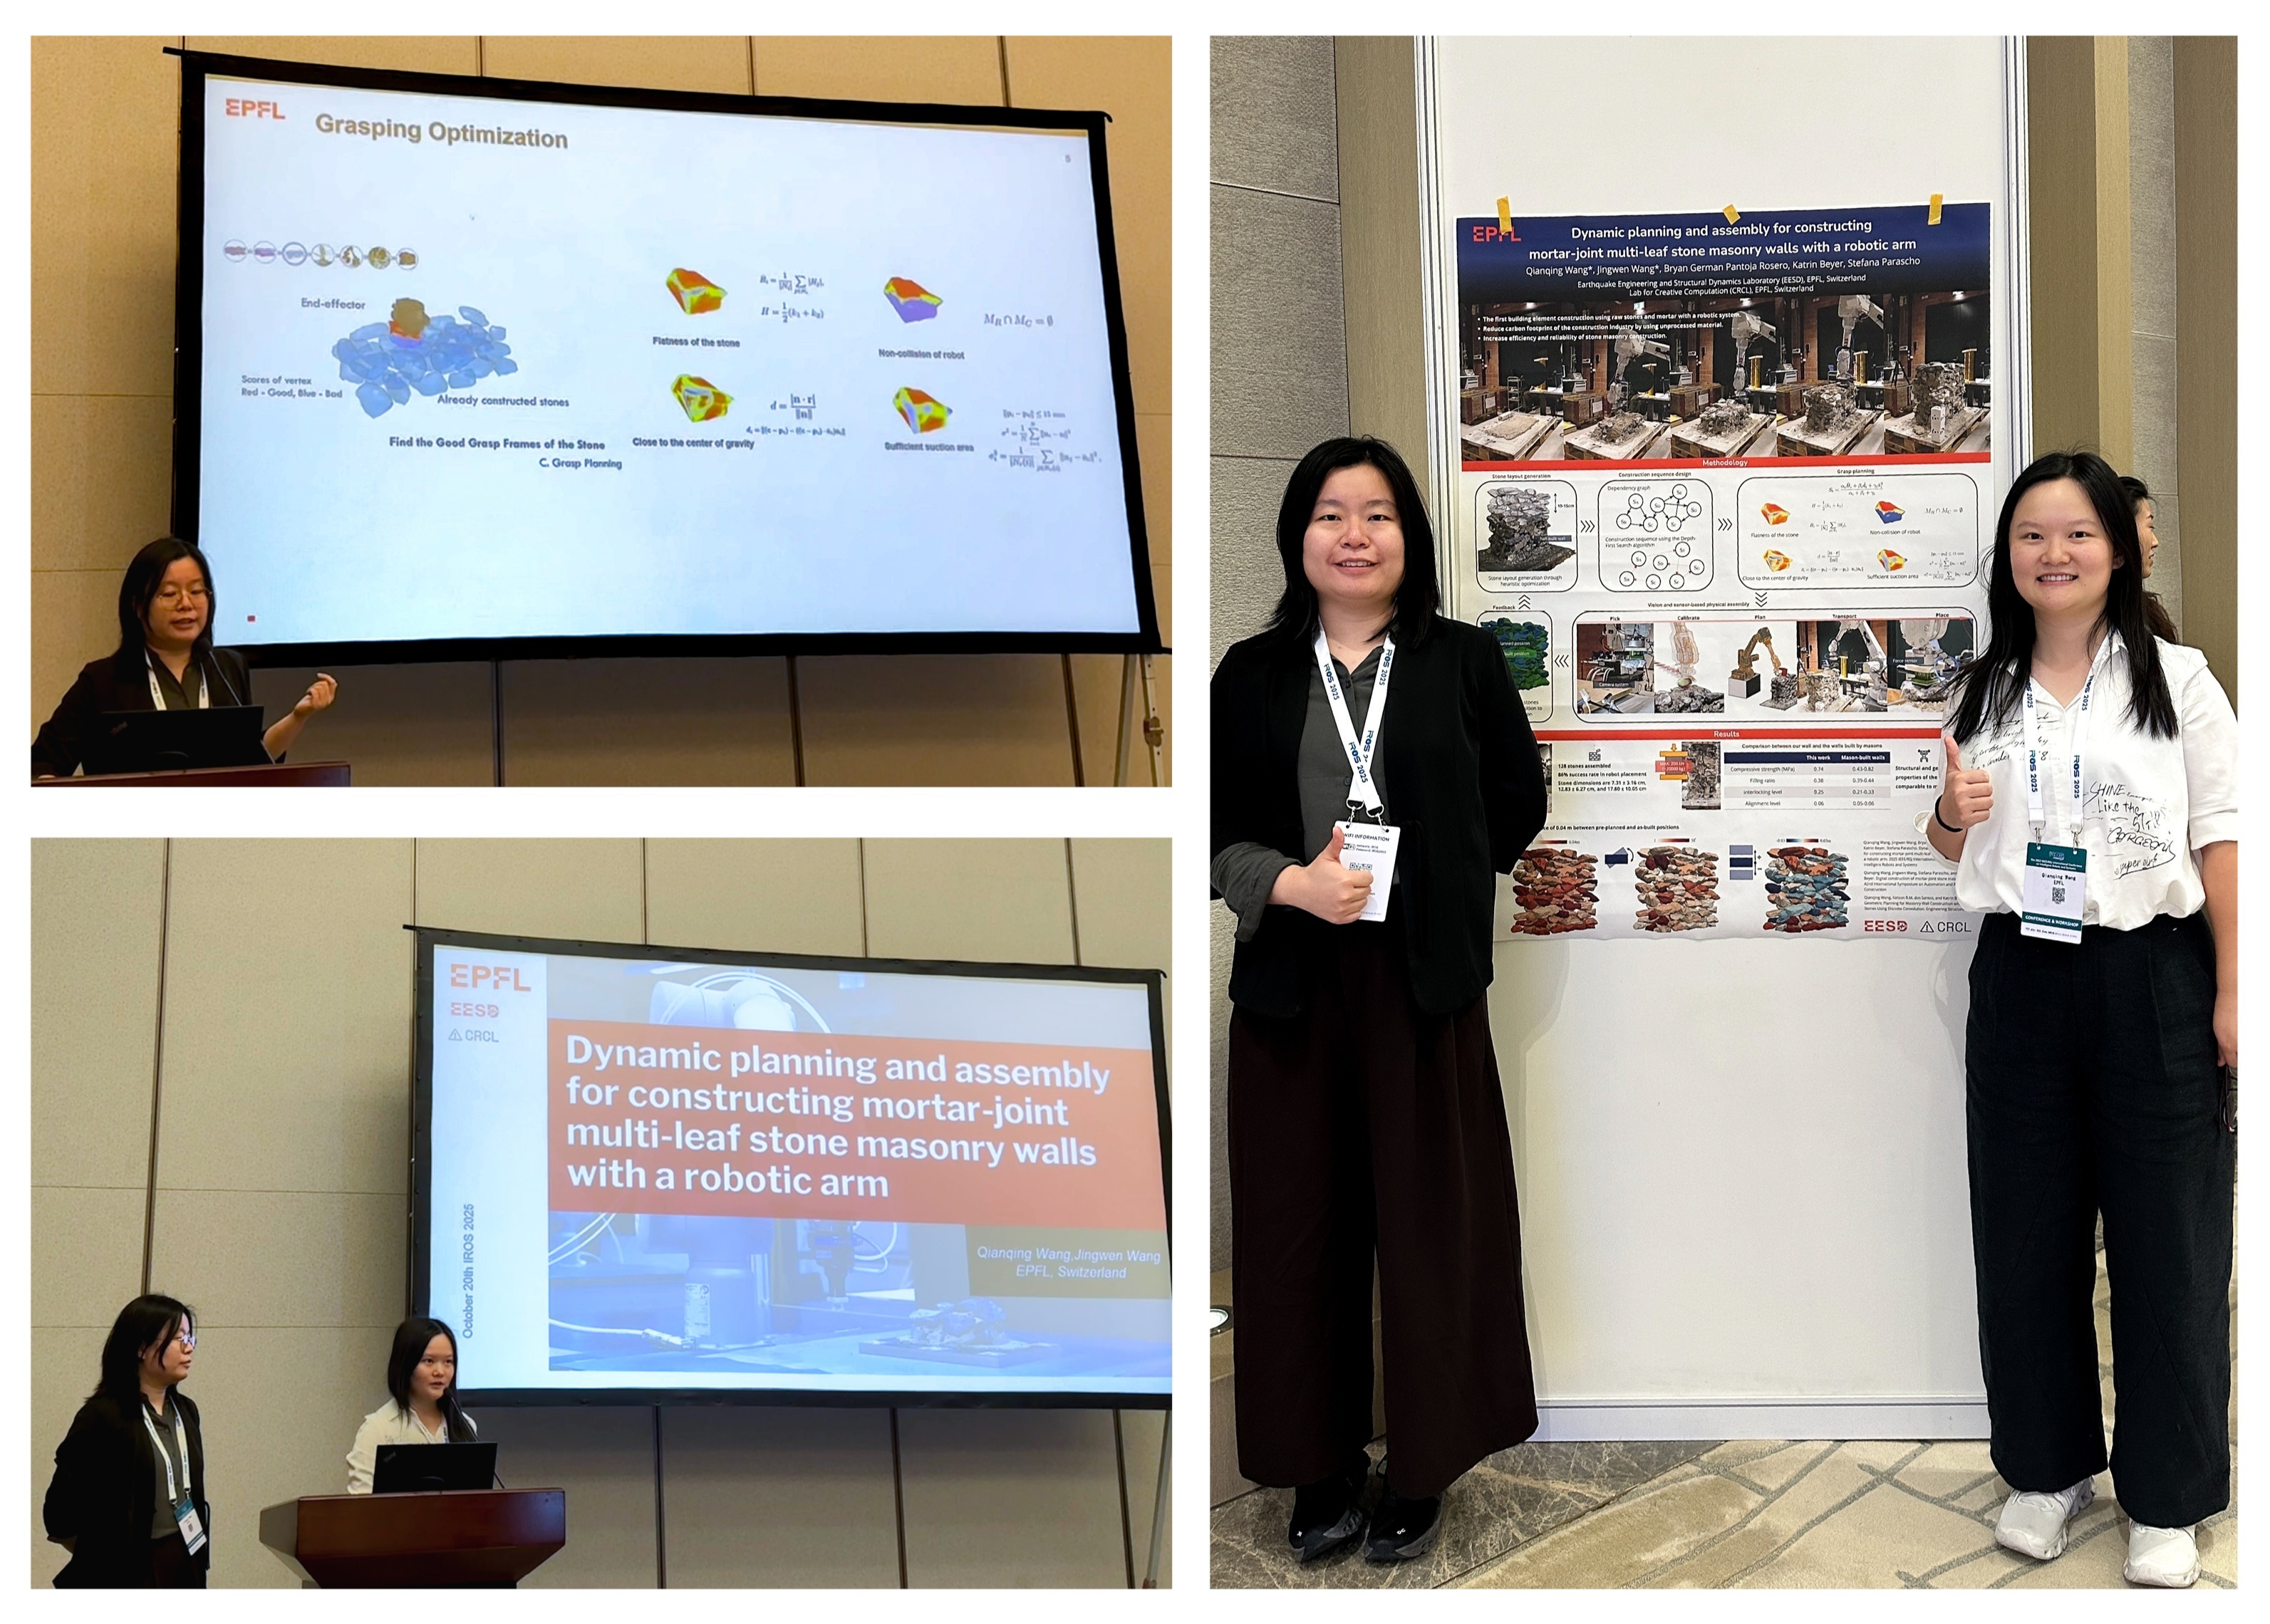
    Together with Qianqing Wang (EESD Lab – EPFL), Jingwen Wang presented their paper "Dynamic Planning and Assembly for Constructing Mortar-Joint Multi-Leaf Stone Masonry Walls with a Robotic Arm" at IROS 2025! The team built the first load-bearing wall from raw stones and mortar with a robotic arm.

    Co-authored by Qianqing Wang*, Jingwen Wang*, Bryan German Pantoja Rosero, Katrin Beyer, and Stefana Parascho.

    A proud step toward merging robotic precision and traditional craft in stone masonry!


    🪨🤖🪨
  16. Graphic for PhD position openings

    Eleni Skevaki and Marirena Kladeftira will present "TimberProxy: A Tangible Human–Robot Interface for Incremental Design and Fabrication of Timber Structures" at ACADIA 2025 in Miami, Florida on Friday, 7 November at 11:15 (local time).

    The paper is authored by Eleni Skevaki, Marirena Kladeftira, Ziqi Wang, Sihui Wu, Gudela Grote, and Stefana Parascho.

    Join us to explore new interfaces for construction robotics!


    ☀️🦾☀️
  17. Graphic for PhD position openings
    Stefana Parascho will be speaking at the third William F. Baker International Research and Design Forum in Madrid! Come to see her talk on November 6, alongside many other leading designers and researchers
    🇪🇸👩🇪🇸
  18. Graphic for PhD position openings
    We are hiring PhD students! If you are interested in human-robot collaborative workflows for timber construction, apply here now! Application review begins on October 25th.
    ⚠️⚠️⚠️
  19. eCAADe 2025 conference banner with robotic fabrication theme
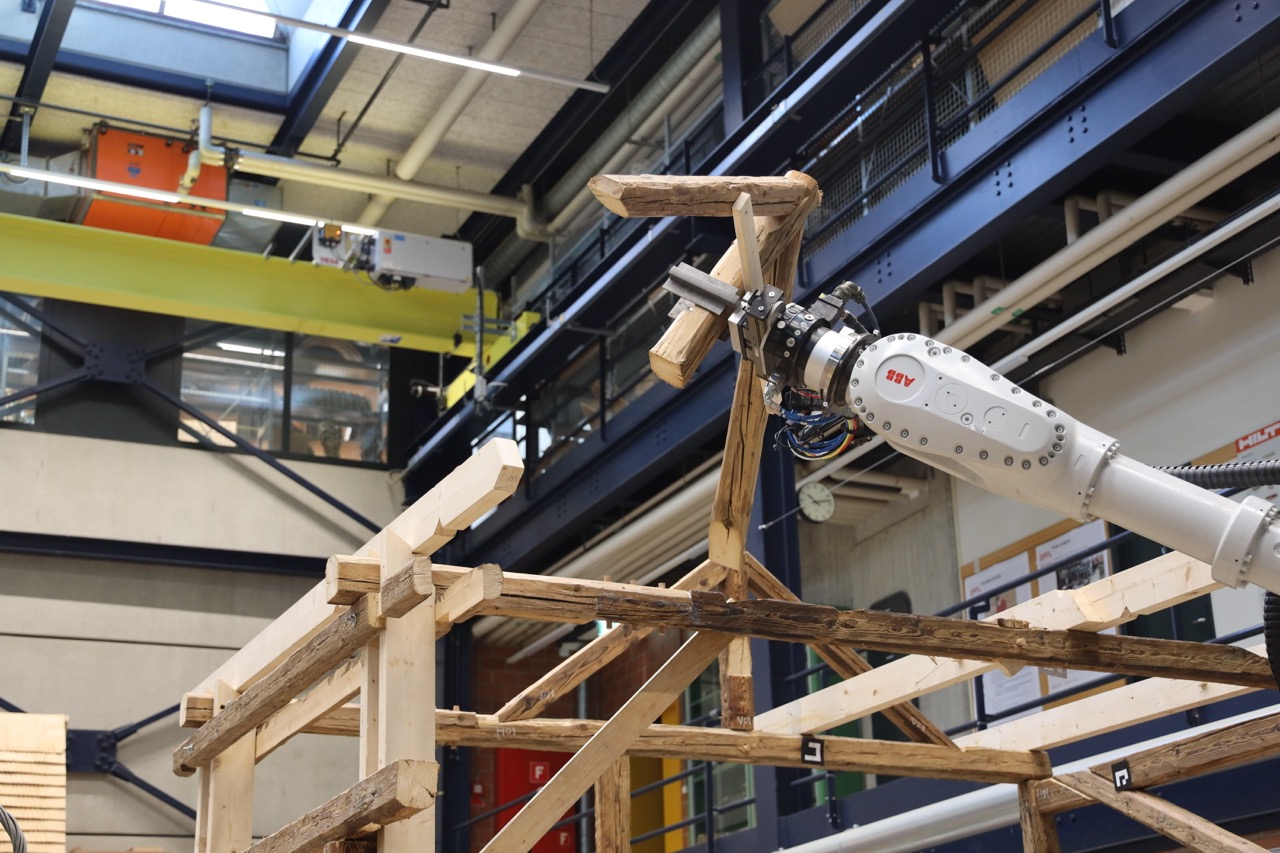
    Alberto Johnsson presents his research "Crafted by Hand and Machine: Human-robot fabrication workflow for the use of curved wood in construction" at eCAADe 2025 in Ankara, Turkey! Tune in to hear about human-robot collaboration methods for working with curved wood elements in construction.
    🪵🤖🪚
  20. Swiss Robotics Day 2025 event banner
    Prof. Stefana Parascho will be giving a keynote lecture on Sustainability in Robotics at Swiss Robotics Day 2025! The event brings together leading experts in robotics research and industry, featuring talks, workshops, and demonstrations focused on sustainable robotics solutions.
    🇨🇭🤖🌱
  21. Design Modelling Symposium 2026 announcement
    We're excited to announce the 10th edition of the Design Modelling Symposium will take place at EPFL Fribourg from 10-12 September 2026! This edition will focus on the shifting relationship between designers and intelligent machines through three key areas: Designing with Materials, Designing with People, and Designing with Ethics.
    🇨🇭🚧🇨🇭
  22. SIGGRAPH 2025 conference banner
    Jingwen Wang will be presenting the paper 'Learning to Assemble with Alternative Plans' at SIGGRAPH 2025 in the Robots in the World session! The paper explores robotic assembly planning through disassembly and will be presented today at 9:00am PDT.
    🧩🤖🧩
  23. Re:Config project installation at Time Space Existence 2025
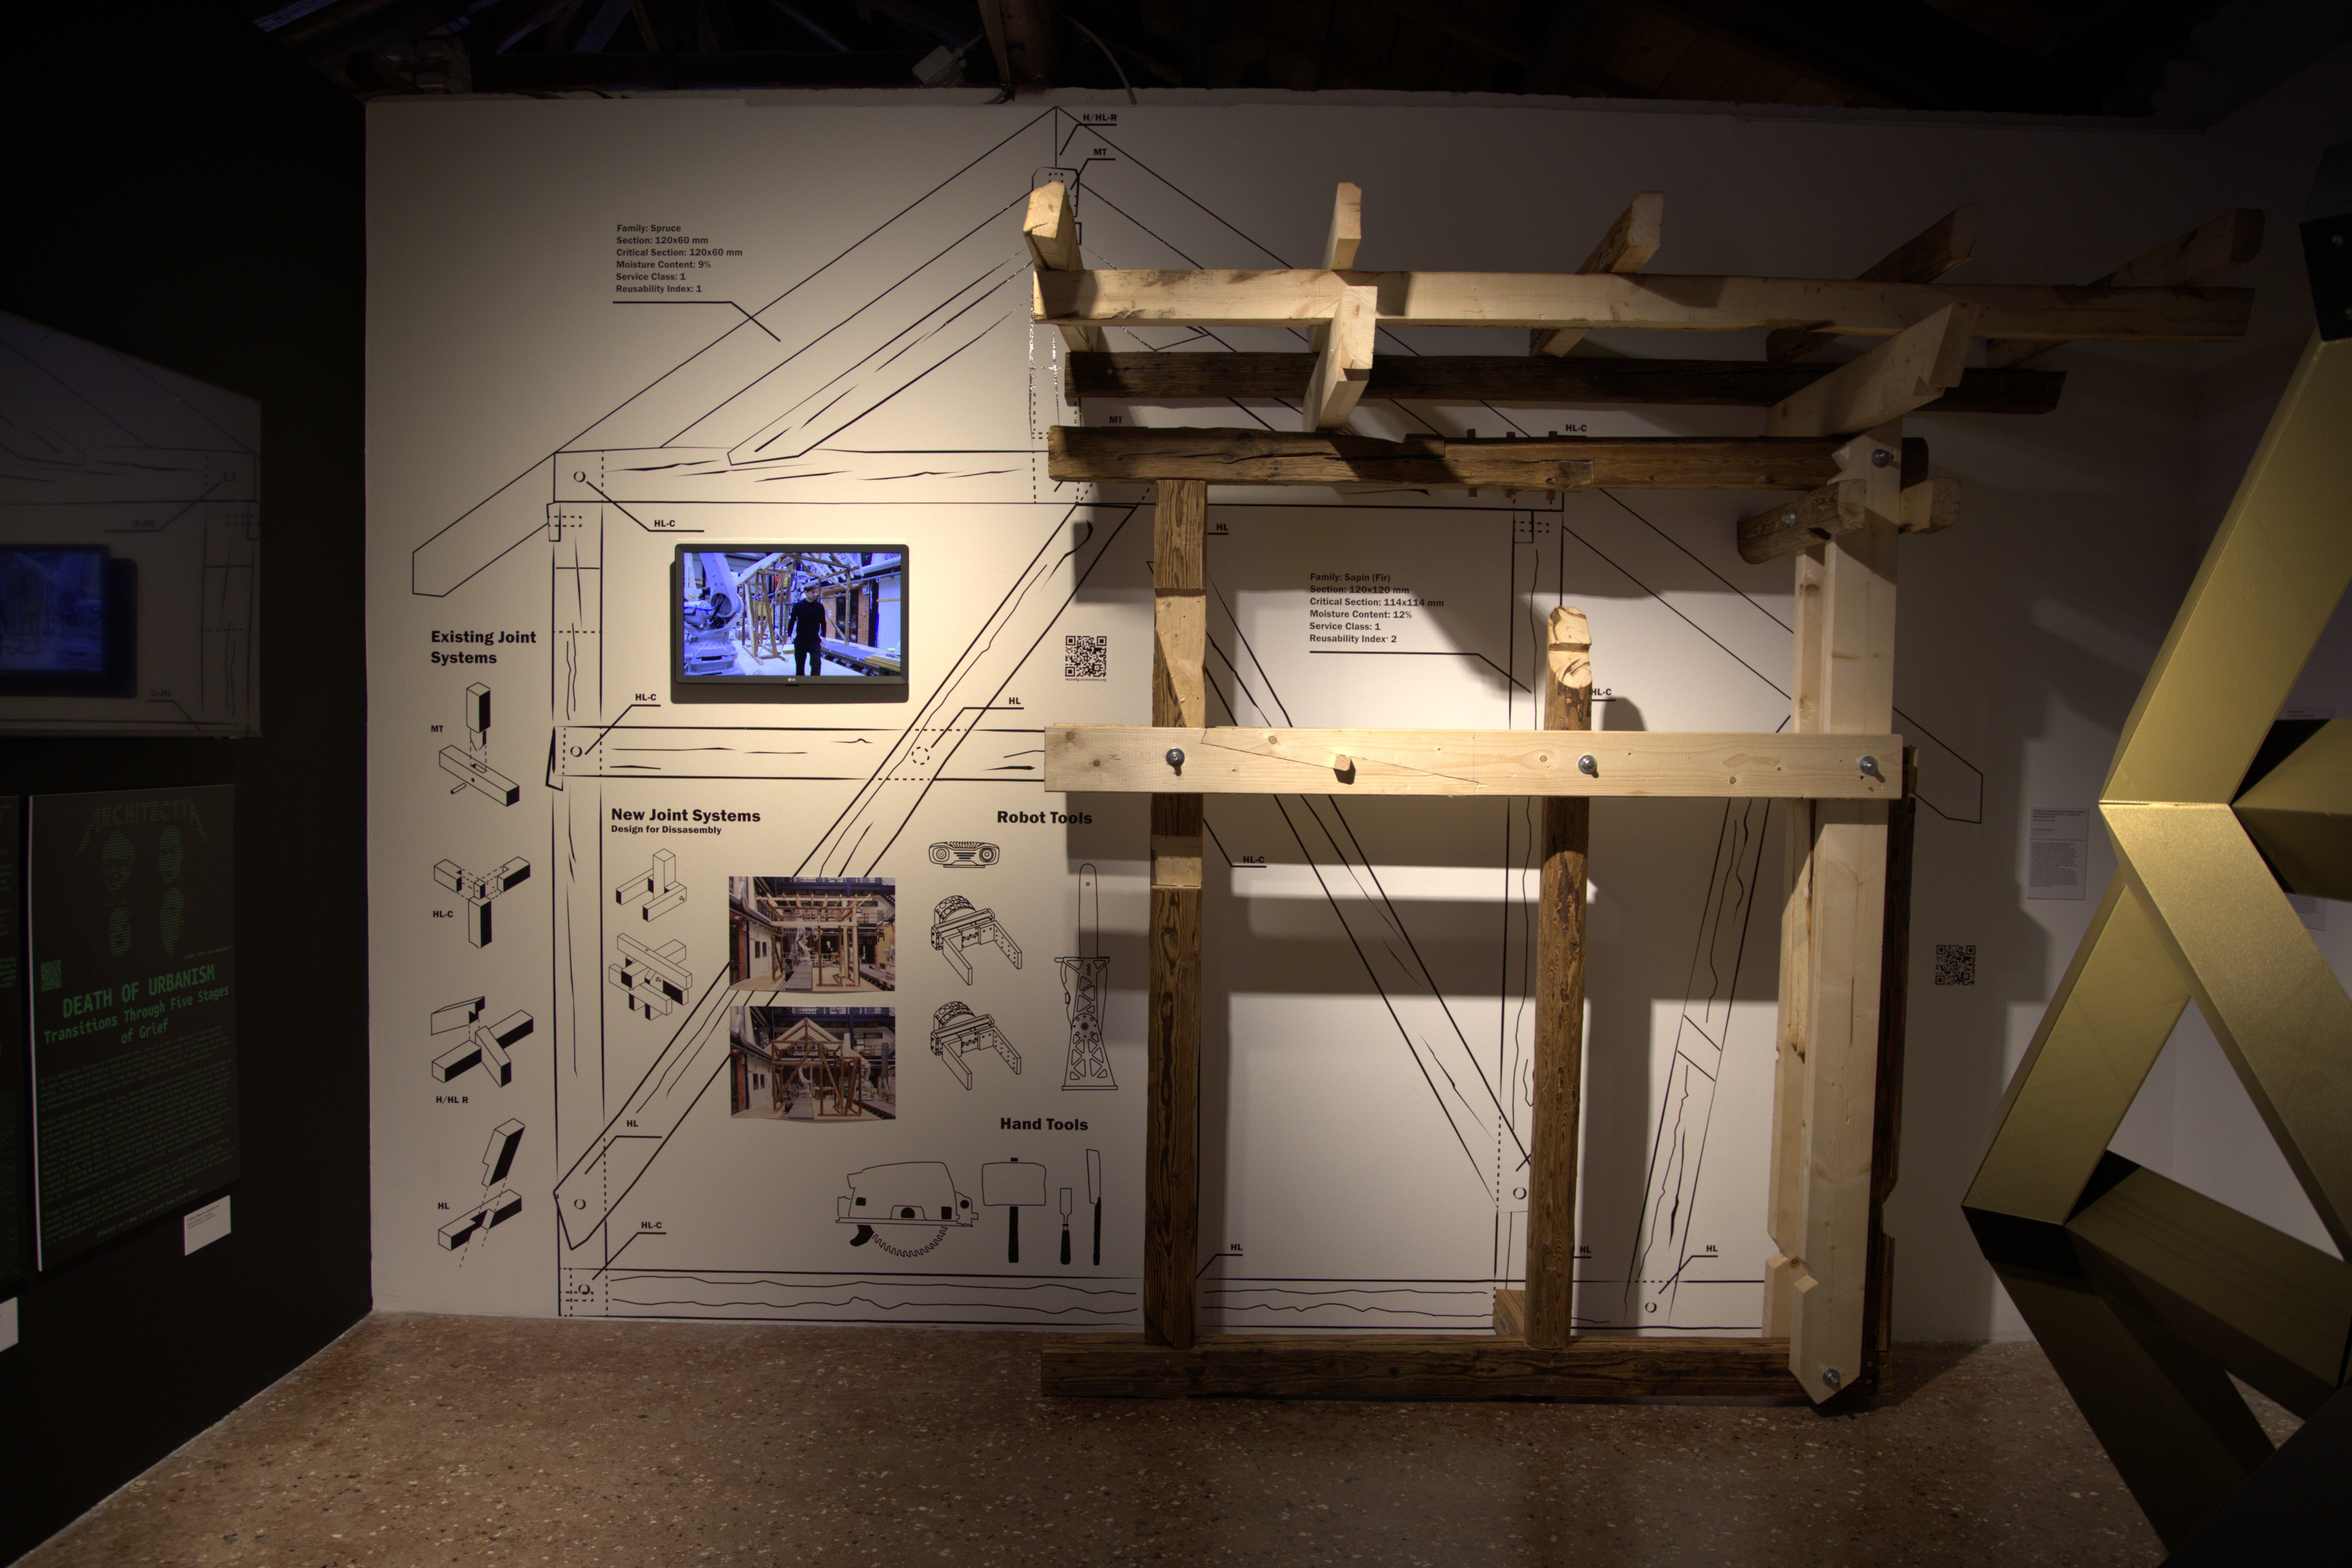
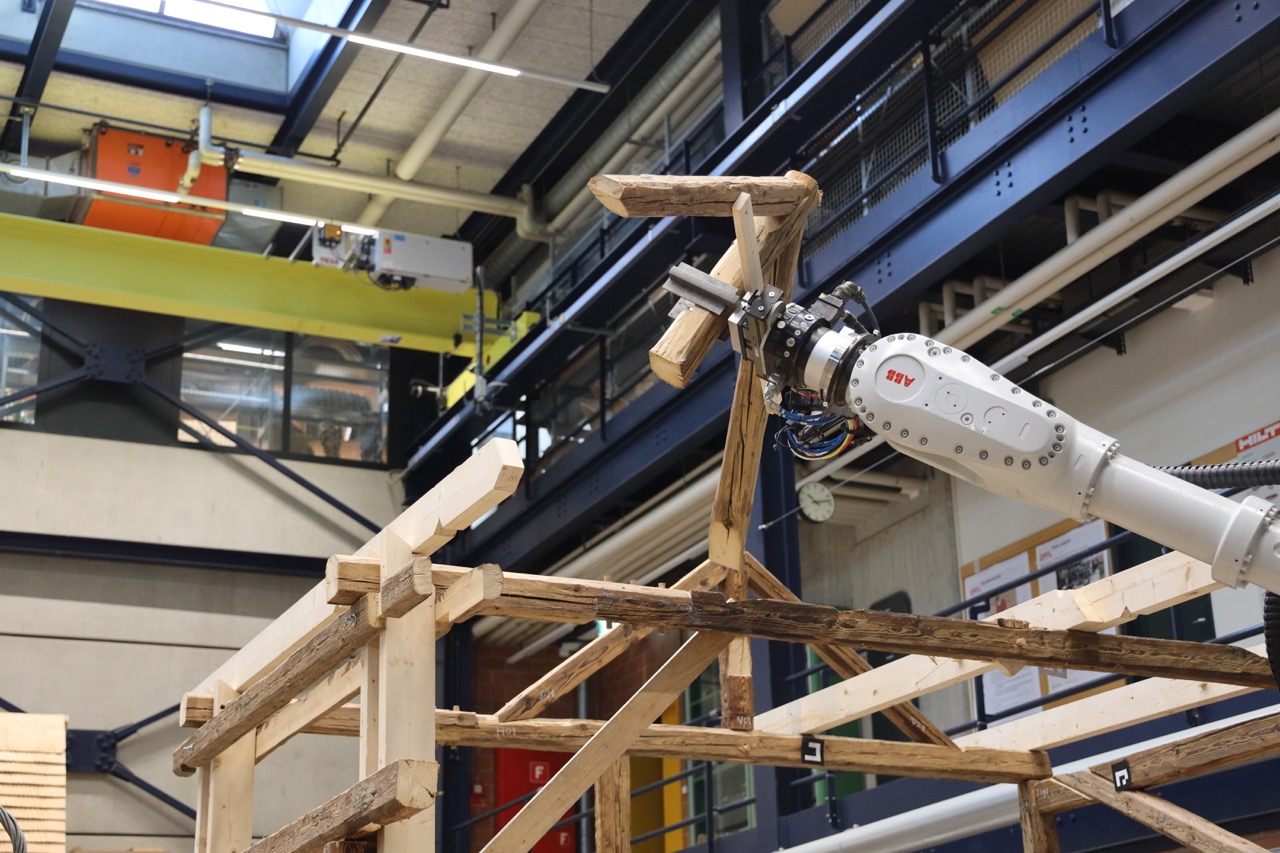
    Our Re:Config project is now on display at Time Space Existence 2025 in Venice! The installation showcases our human-robot adaptive workflows for disassembly, repair, and construction of timber structures. Come explore the project at Palazzo Mora until November 23rd!
    🏛️🪵🤖
  24. Banner for technician position
    The GIS platform at ENAC is searching for an automation and robotics technician or engineer to complete their team! CRCL works closely with GIS for technical support, so please consider applying if you are interested in working with us.
    🦾🛠️🦾
  25. Image of a wooden structure under construction
    CRCL will be in Venice for Time Space Existence, beginning May 10. Come by to see the structure we are building and adapting with robots as part of Re:Config!
    🪵🪚🪵
  26. A small scale wood structure
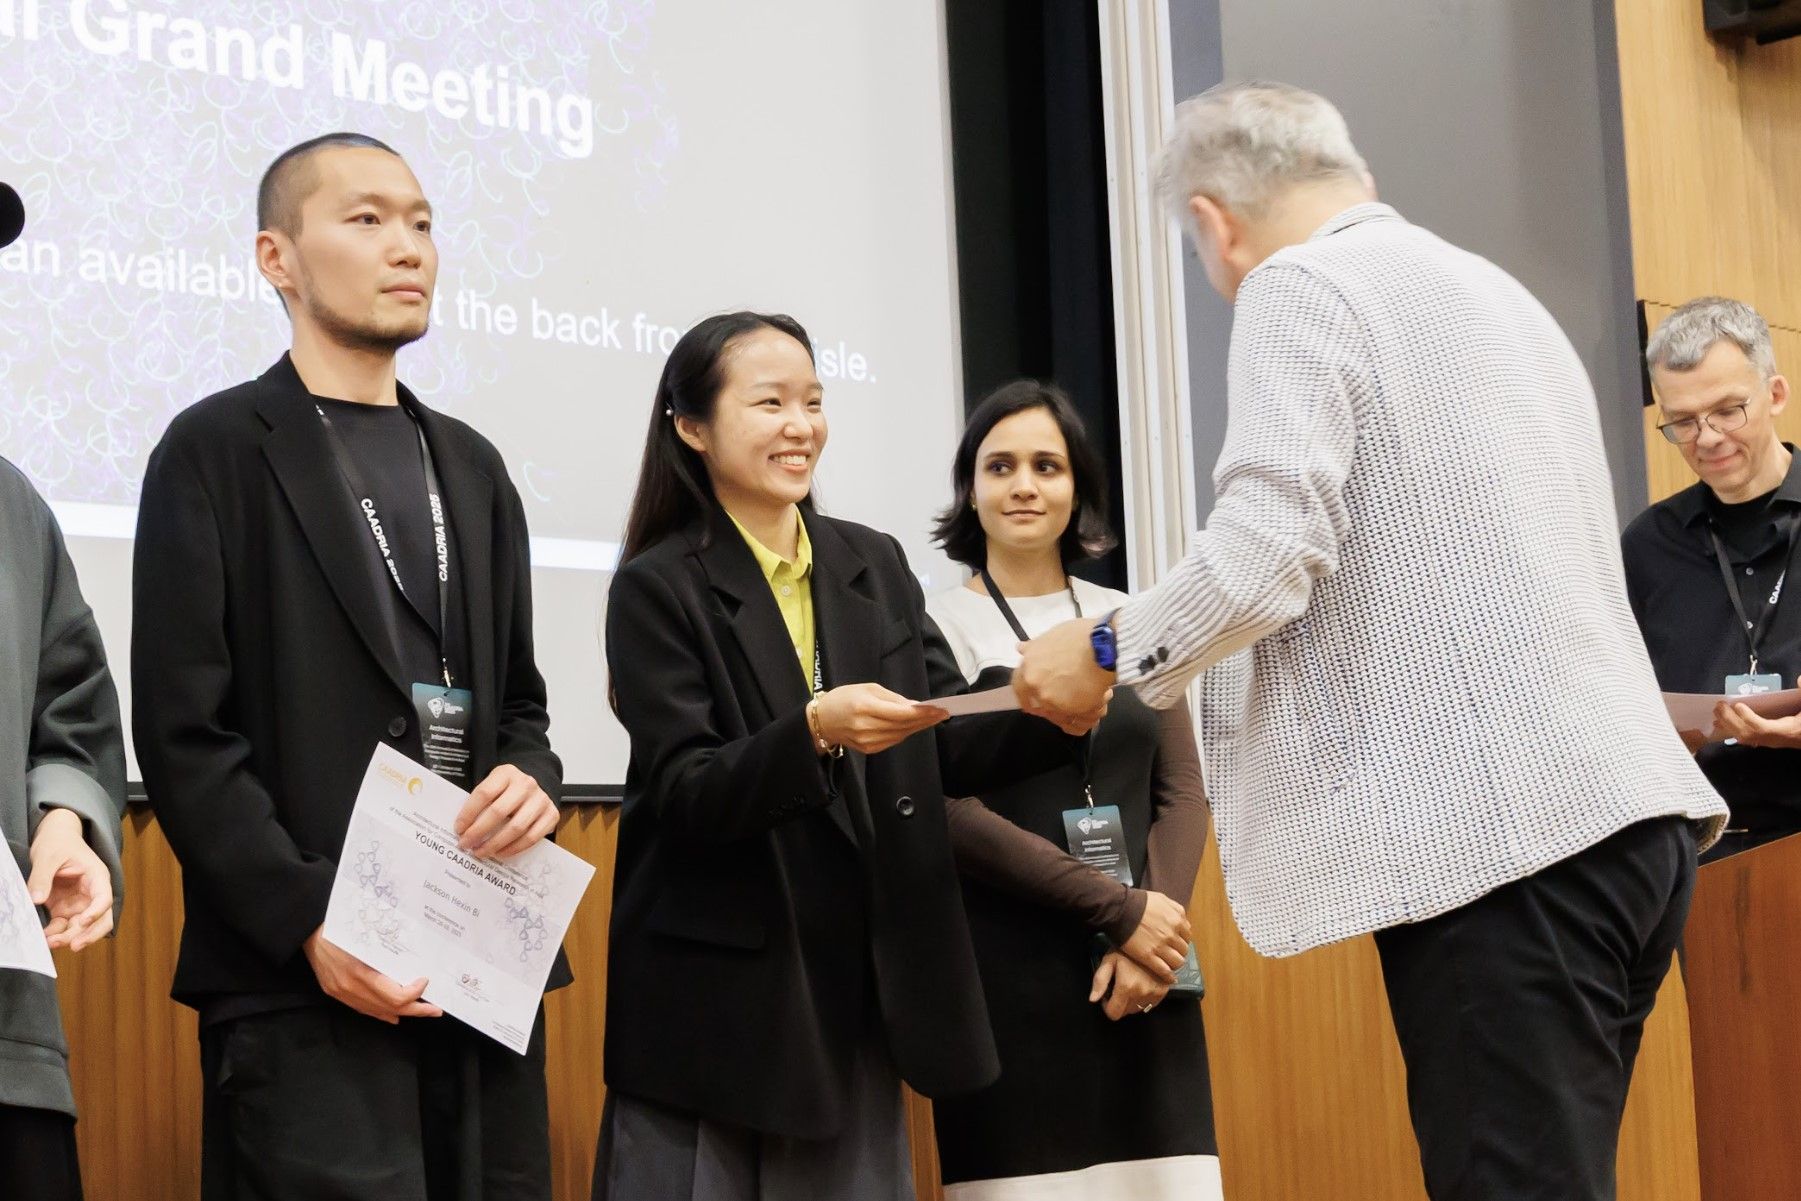
    Congrats to Isla Xi Han for winning the Young CAADRIA Award at this year's conference for her paper, From Words to Actions: A large language model (LLM) approach for human-robot interaction in design-fabrication settings!
    🏆💬🏆
  27. CAADRIA 2025 graphic
    Bravo to Alex Pittiglio and Xiliu Yang for presenting their paper, Augmented Human-Robot Collaborative Bending: Human-robot collaboration for biogenic material bending-active assemblies, at CAADRIA 25!
    🎍🗾🎍
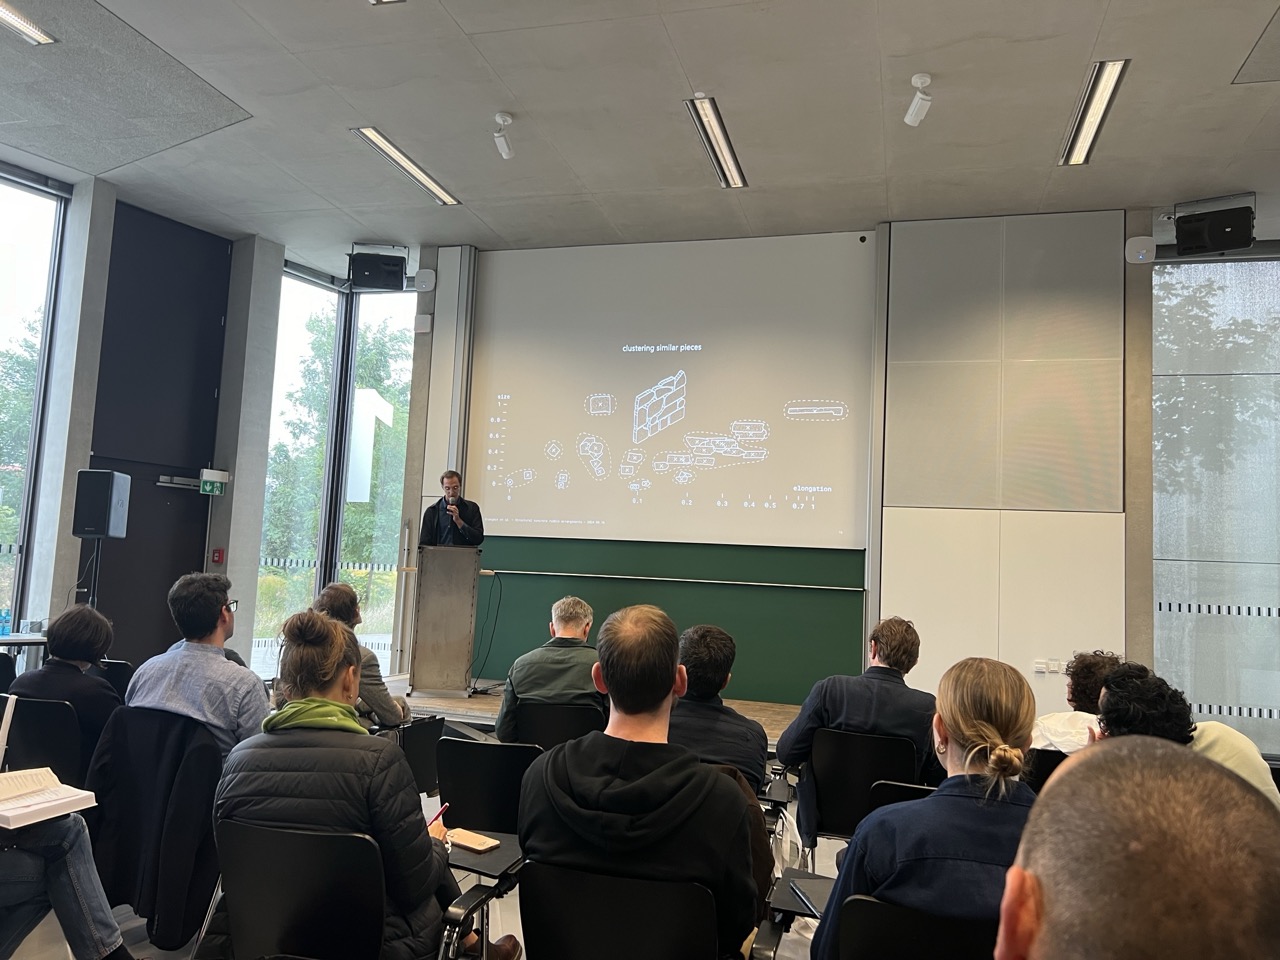
  28. Edvard presenting his research
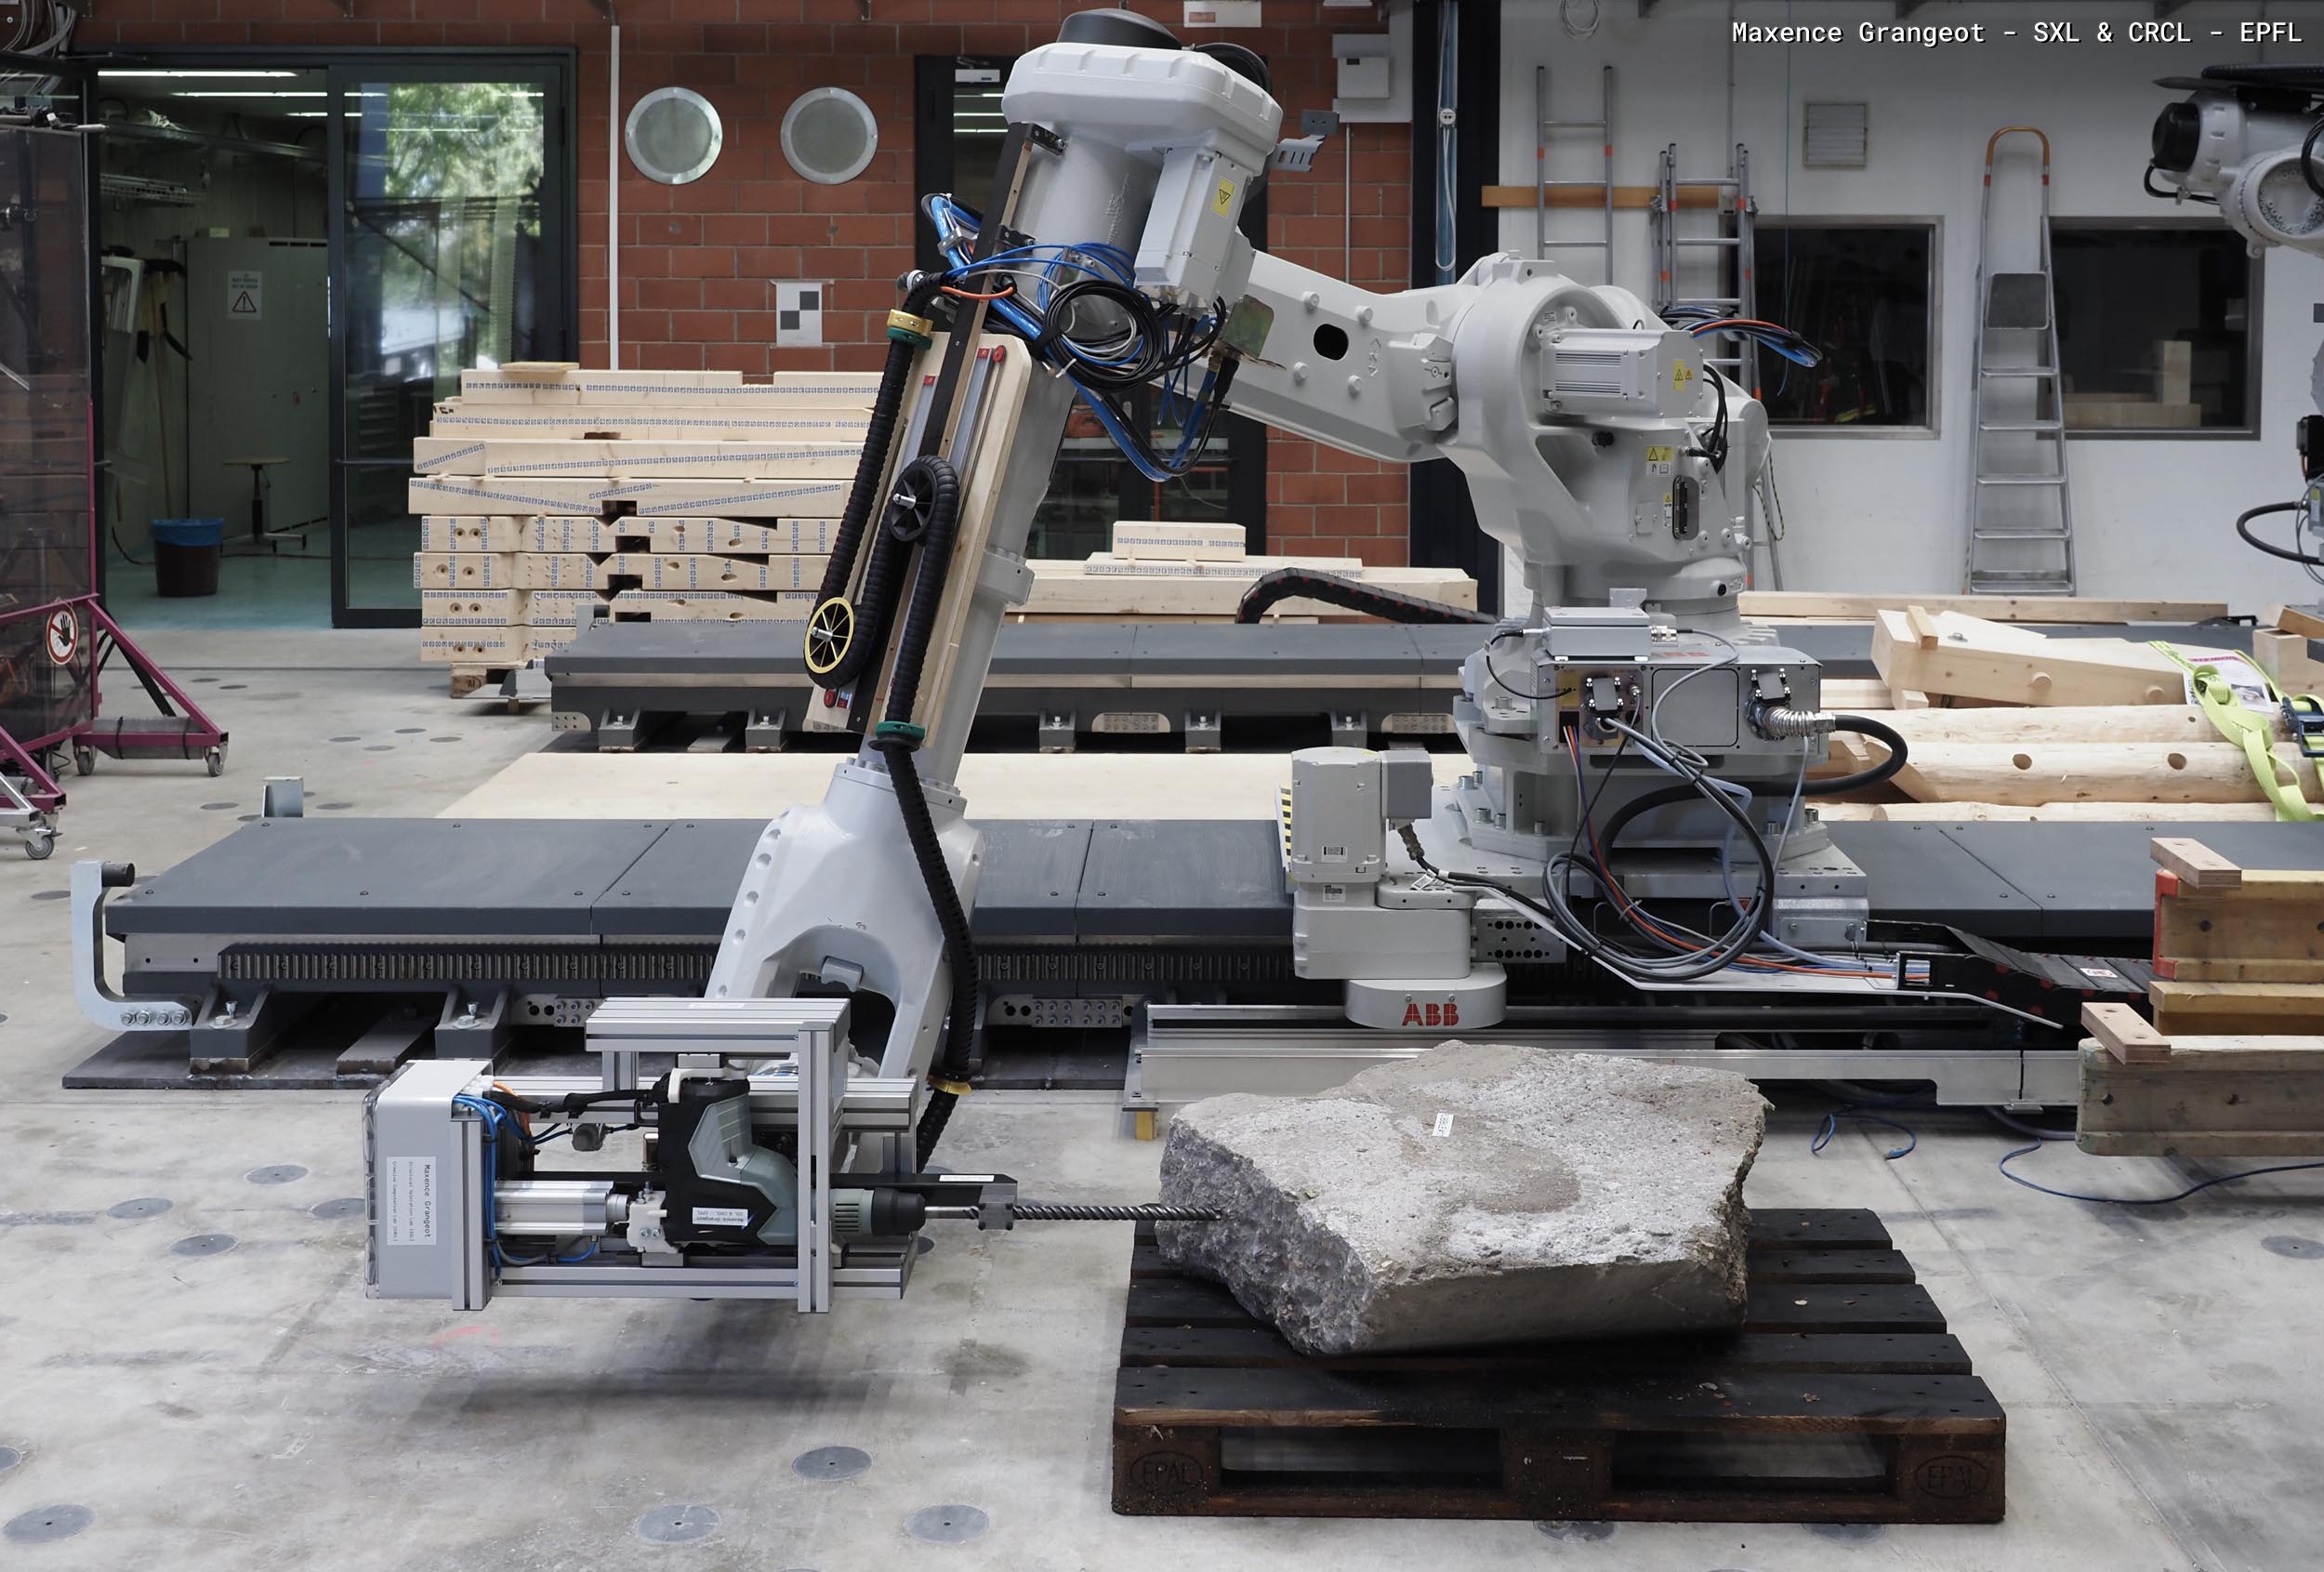
    CRCL in Germany! Maxence presented Structural Concrete Rubble Arrangements at the Design Modeling Symposium 2024 in Kassel
    🪨🎤🪨
  29. Robot installation at Beta 2024
    We're showing 'I am not a robot' at Beta 2024 - the Timișoara Architecture Biennale! Created by Eric Duong, Stefana Parascho, and Zara Pfeiffer, the installation deconstructs our relationships to robots through a recontextualization of behavior, sense, and control
    🦾🧠💥
  30. A small scale wood structure
    CRCL will be hosting a workshop on human-robot interaction (HRI) as part of this year's Design Modeling Symposium in Kassel, Germany. The workshop will introduce participants to a novel workflow that enables more dynamic and reconfigurable fabrication processes with HRI. It will include interactive discussions and tutorials aiming to develop technical skills, methods of experimentation, and new creative possibilities! Registration is now open online.
    🧑 🤝 🤖
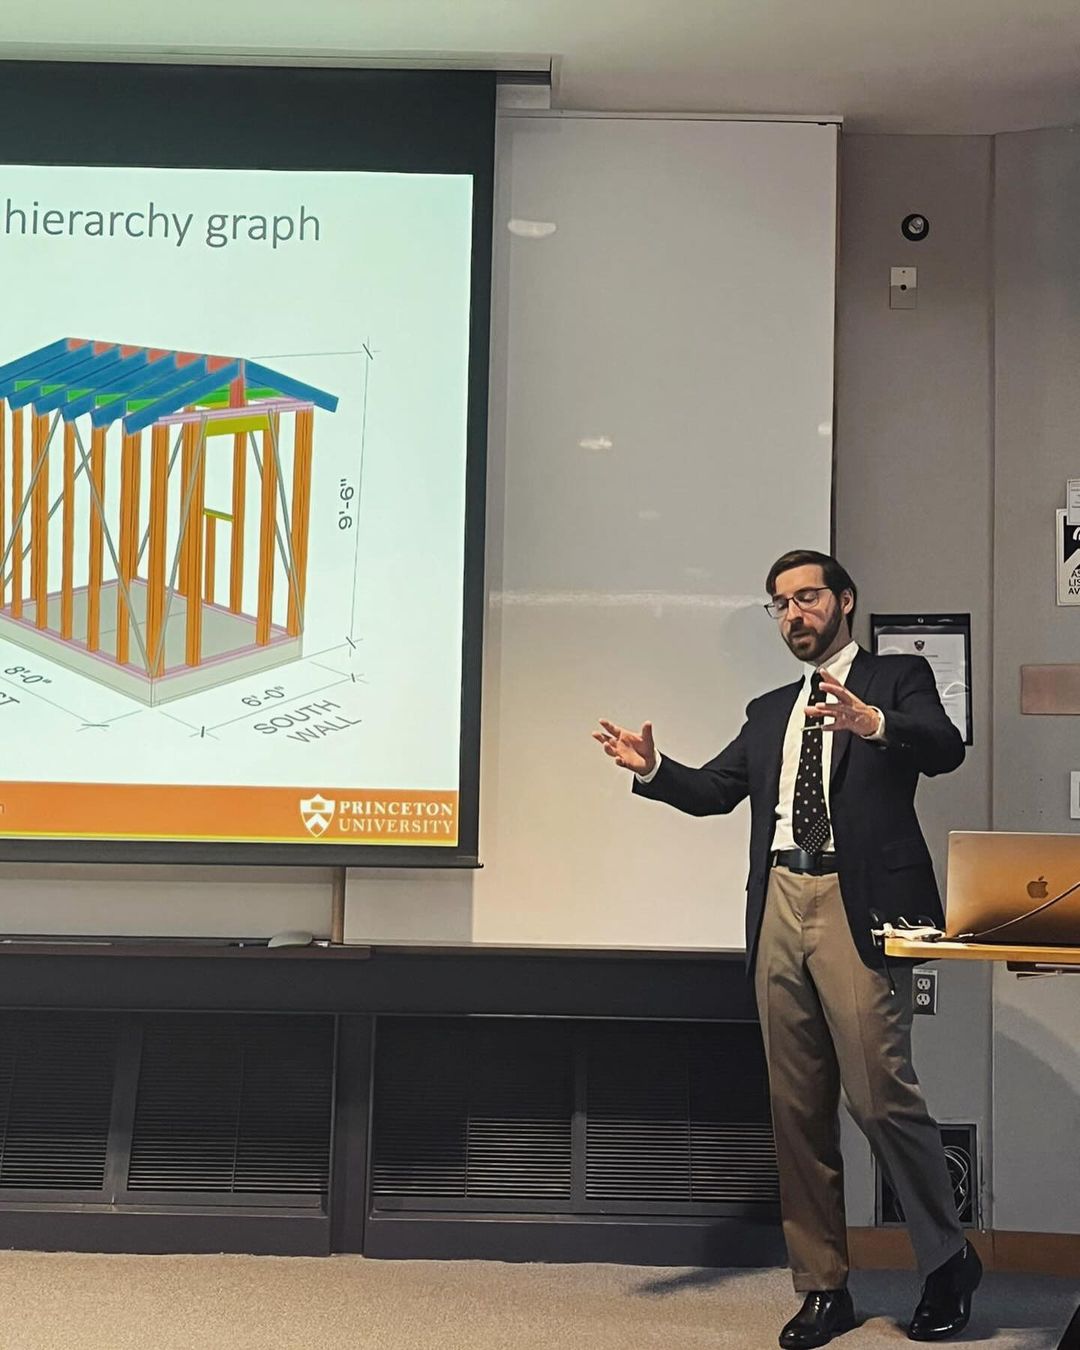
  31. Edvard presenting his research
    Congratulations to Edvard P. G. Bruun for passing his doctoral examination and being officially awarded the title of PhD! Edvard was co-advised by Prof. Adriaenssens at the Princeton Forming Finding Lab and Prof Parascho at CRCL.
    🎉 🎓 🎉
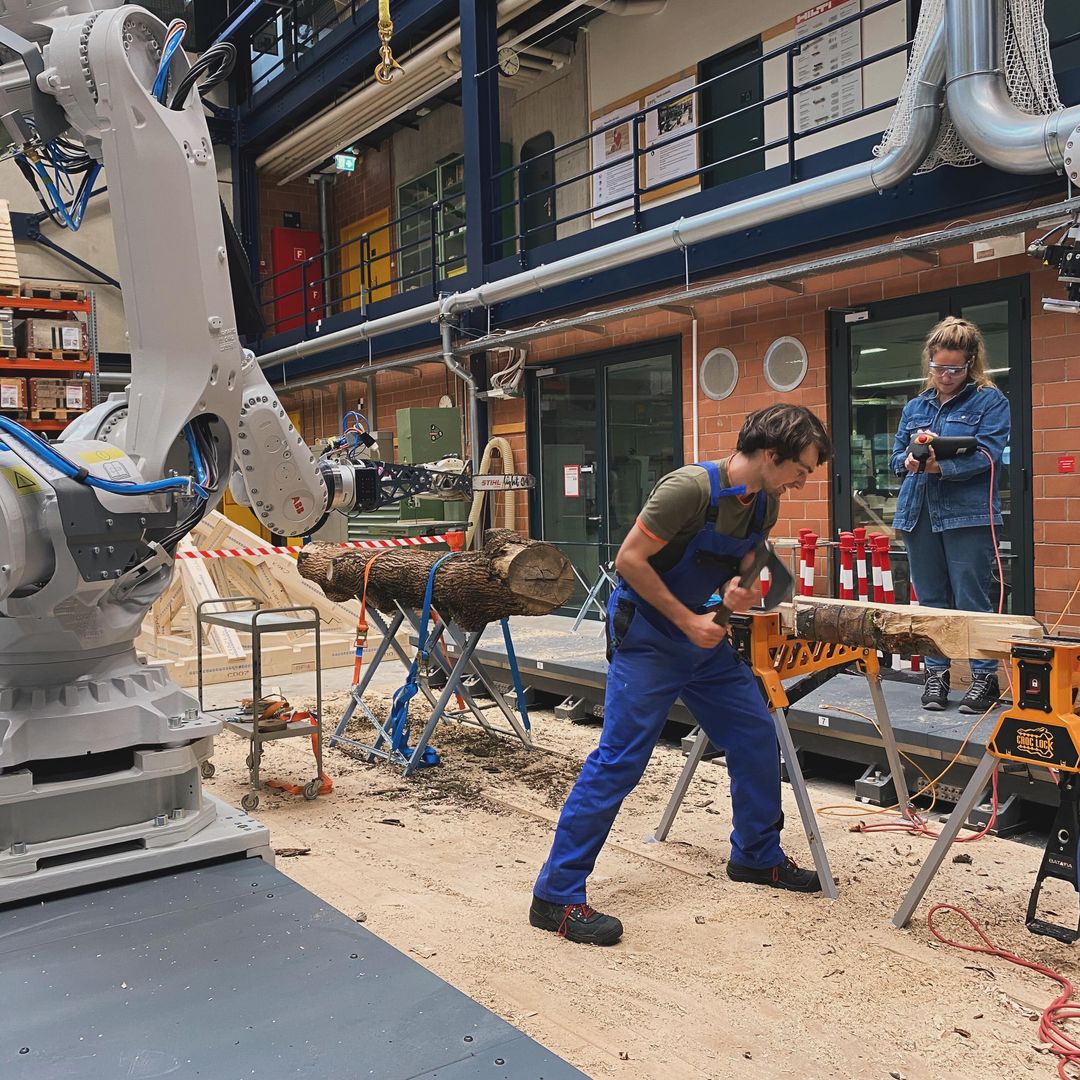
  32. Alberto cutting wood and Eleni operating a robot
    Today marks the completion of Alberto Johnsson's master's thesis, Digital Woodcraft, conducted with Eleni Skevaki and Stefana Parascho. Congrats to Alberto for an amazing year of work in human craft, robotic precision and material properties for a new woodworking experience!
    🦾 👷 🪵
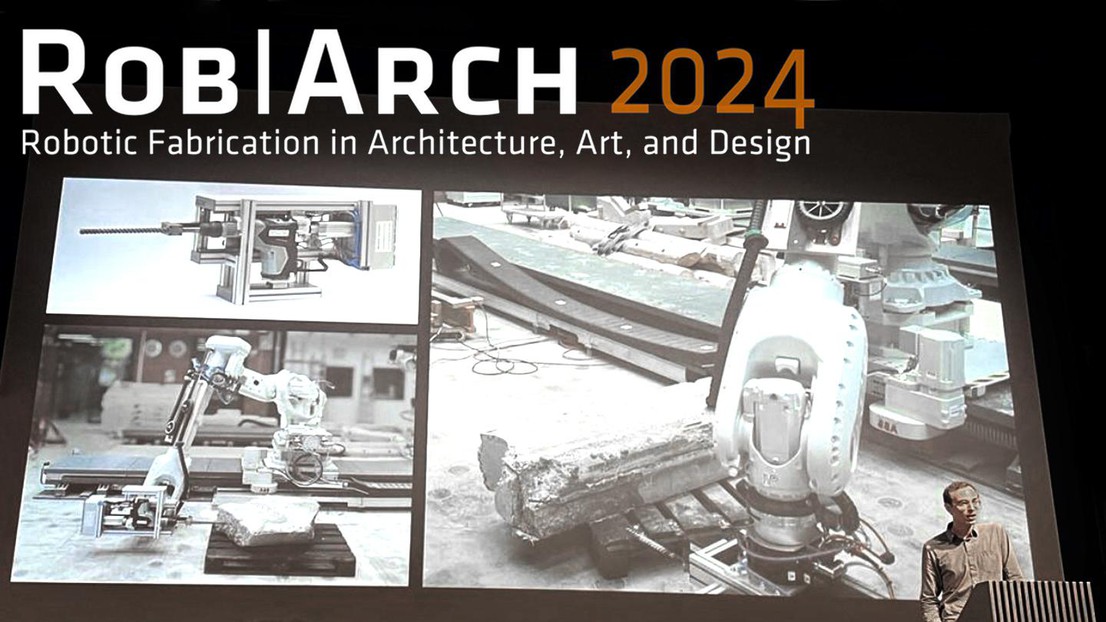
  33. Maxence presenting his paper at RobArch 2024
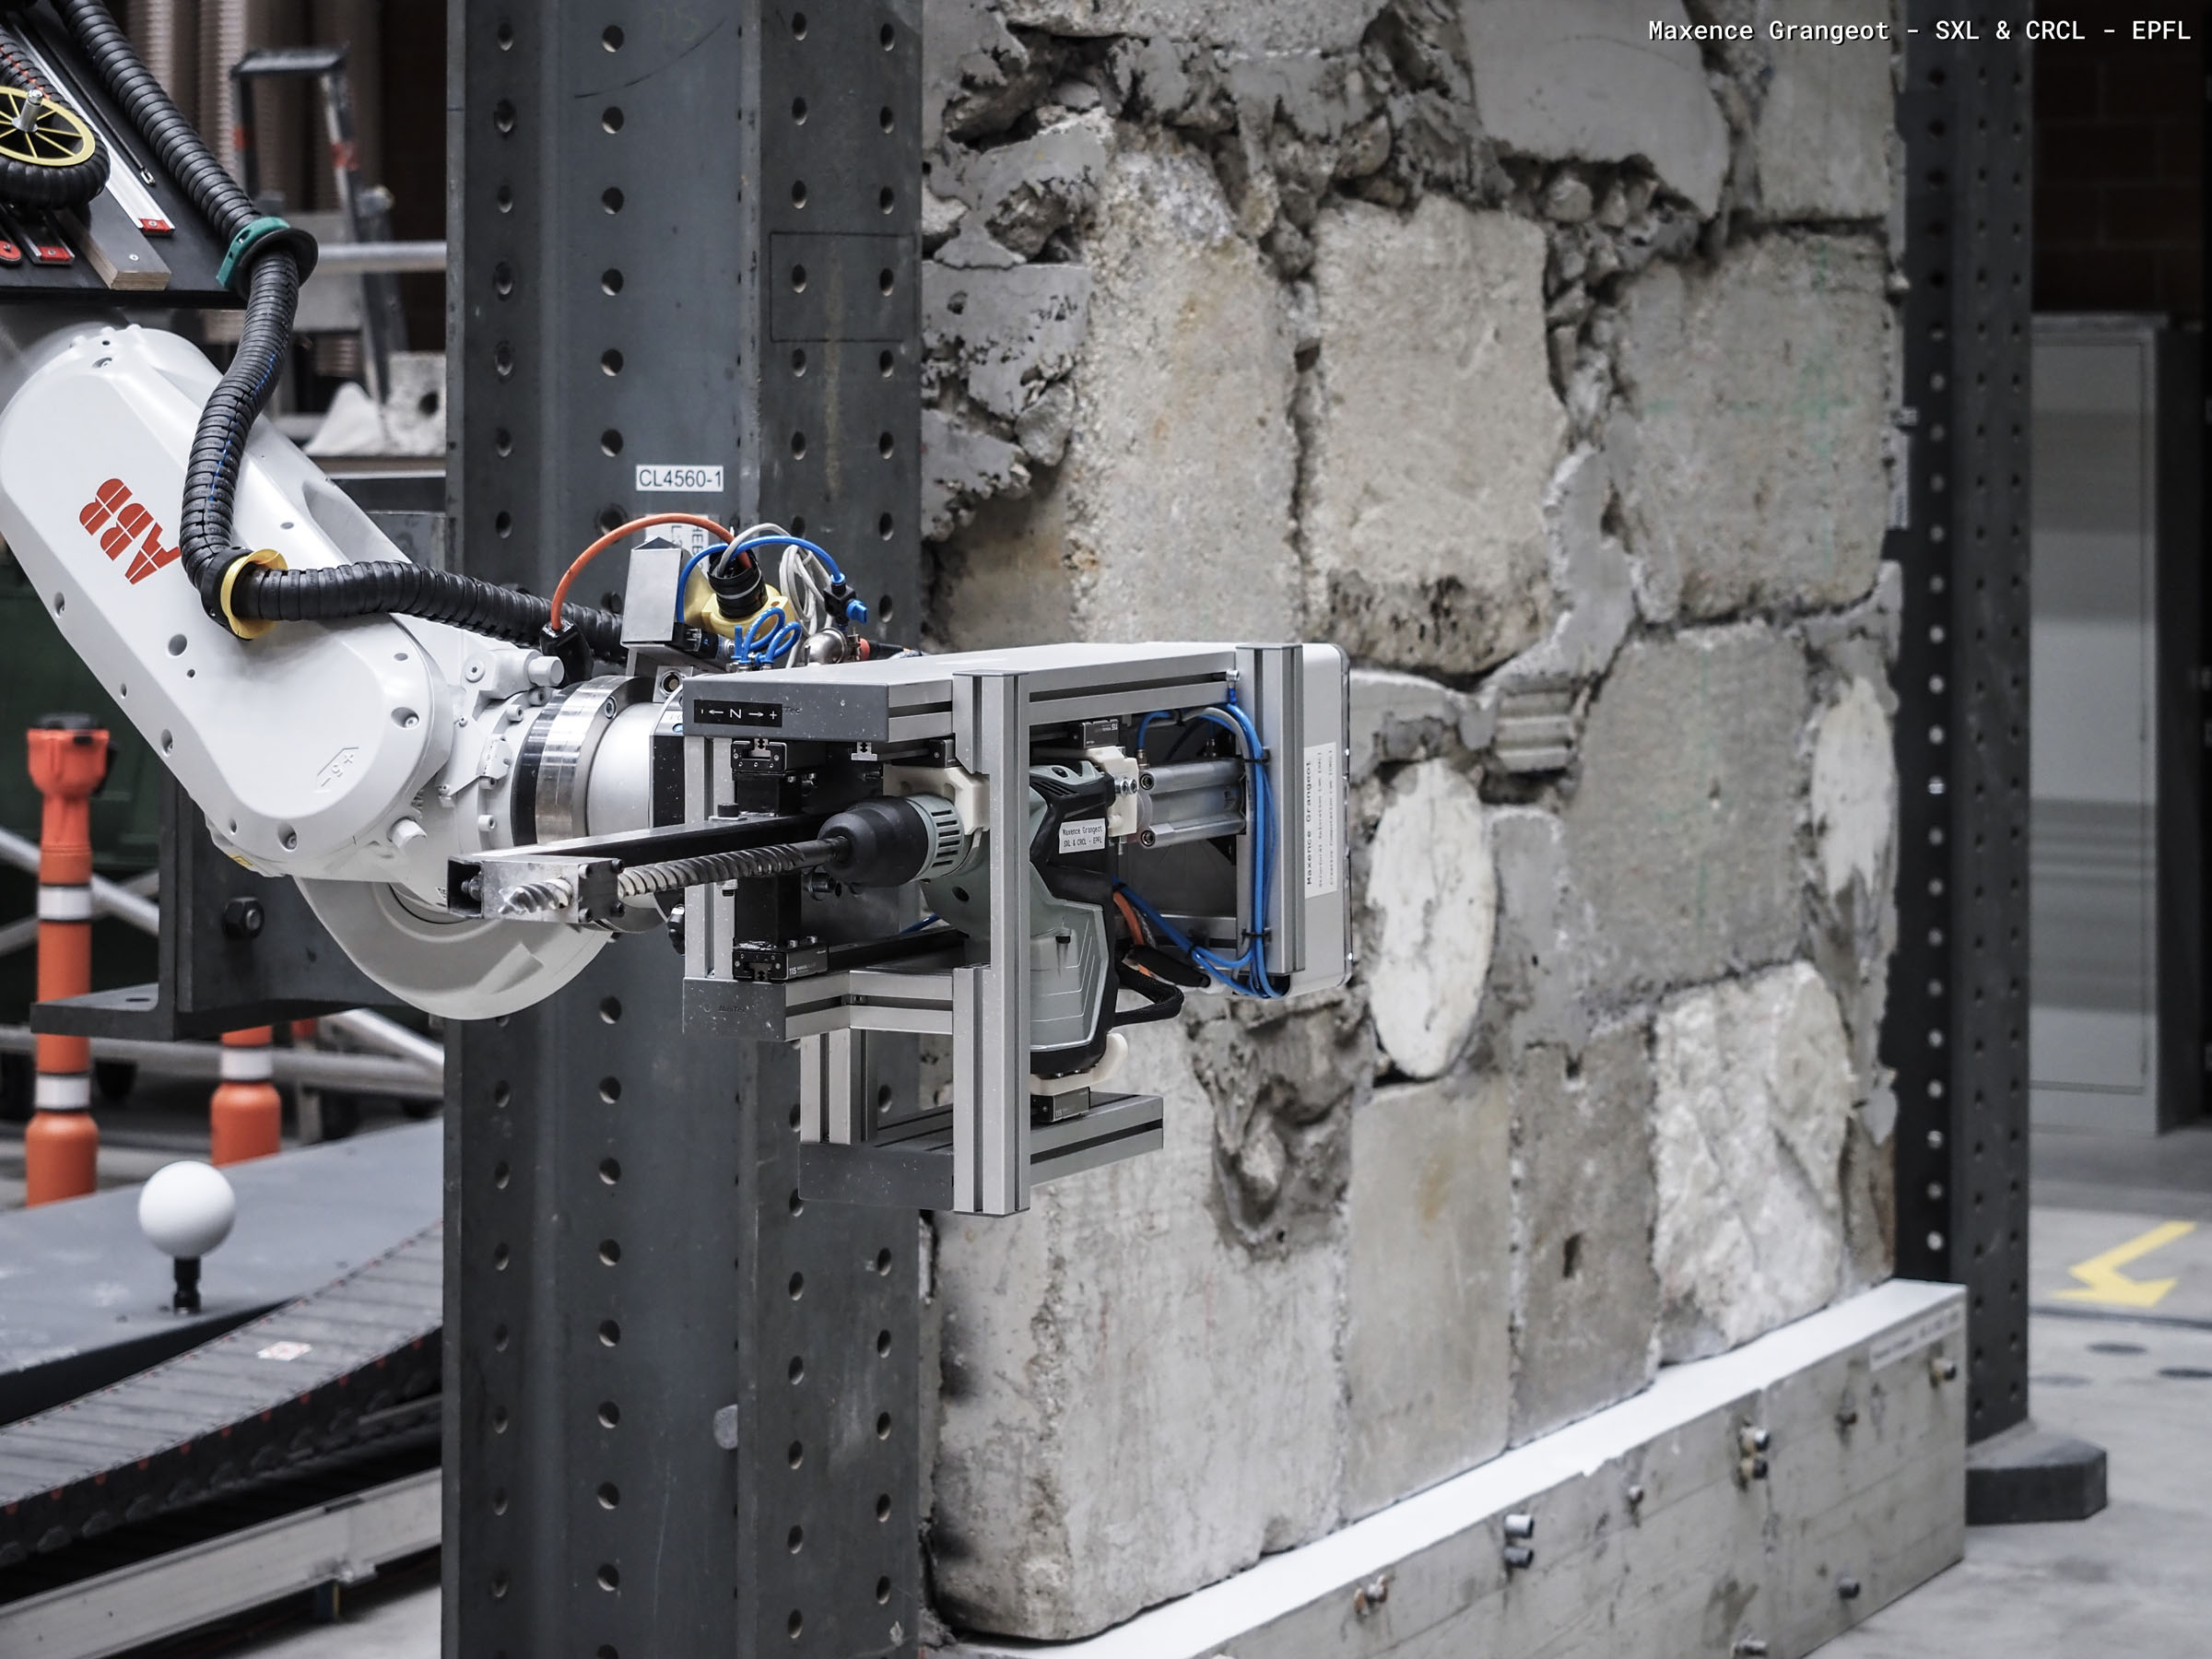
    Congratulations to Maxence Grangeot for winning the New Frontiers Runner-up award at Rob|Arch 2024! His paper, "Rising from the rubble - Leveraging existing construction tools for upcycling concrete waste into slender walls" was co-authored with Qianqing Wang (EESD), Katrin Beyer (EESD), Corentin Fivet (SXL) and Stefana Parascho (CRCL).
    🪨 🏆 🪨
  34. RobArch promotional header image
    Isla Xi Han and Maxence will be presenting their papers at the upcoming Rob|Arch 2024! Keep an eye on Paper Session 1 for Isla's presentation of "Spontaneous Tensegrity: Exploring Improvisational Design and Robotic Fabrication in Tensegrity Structures" and Paper Session 2 for Maxence's presentation of "Rising from Rubble: Leveraging Existing Construction Tools for Upcycling Concrete Waste into Slender Walls"!
    🦾 🎤 🦾
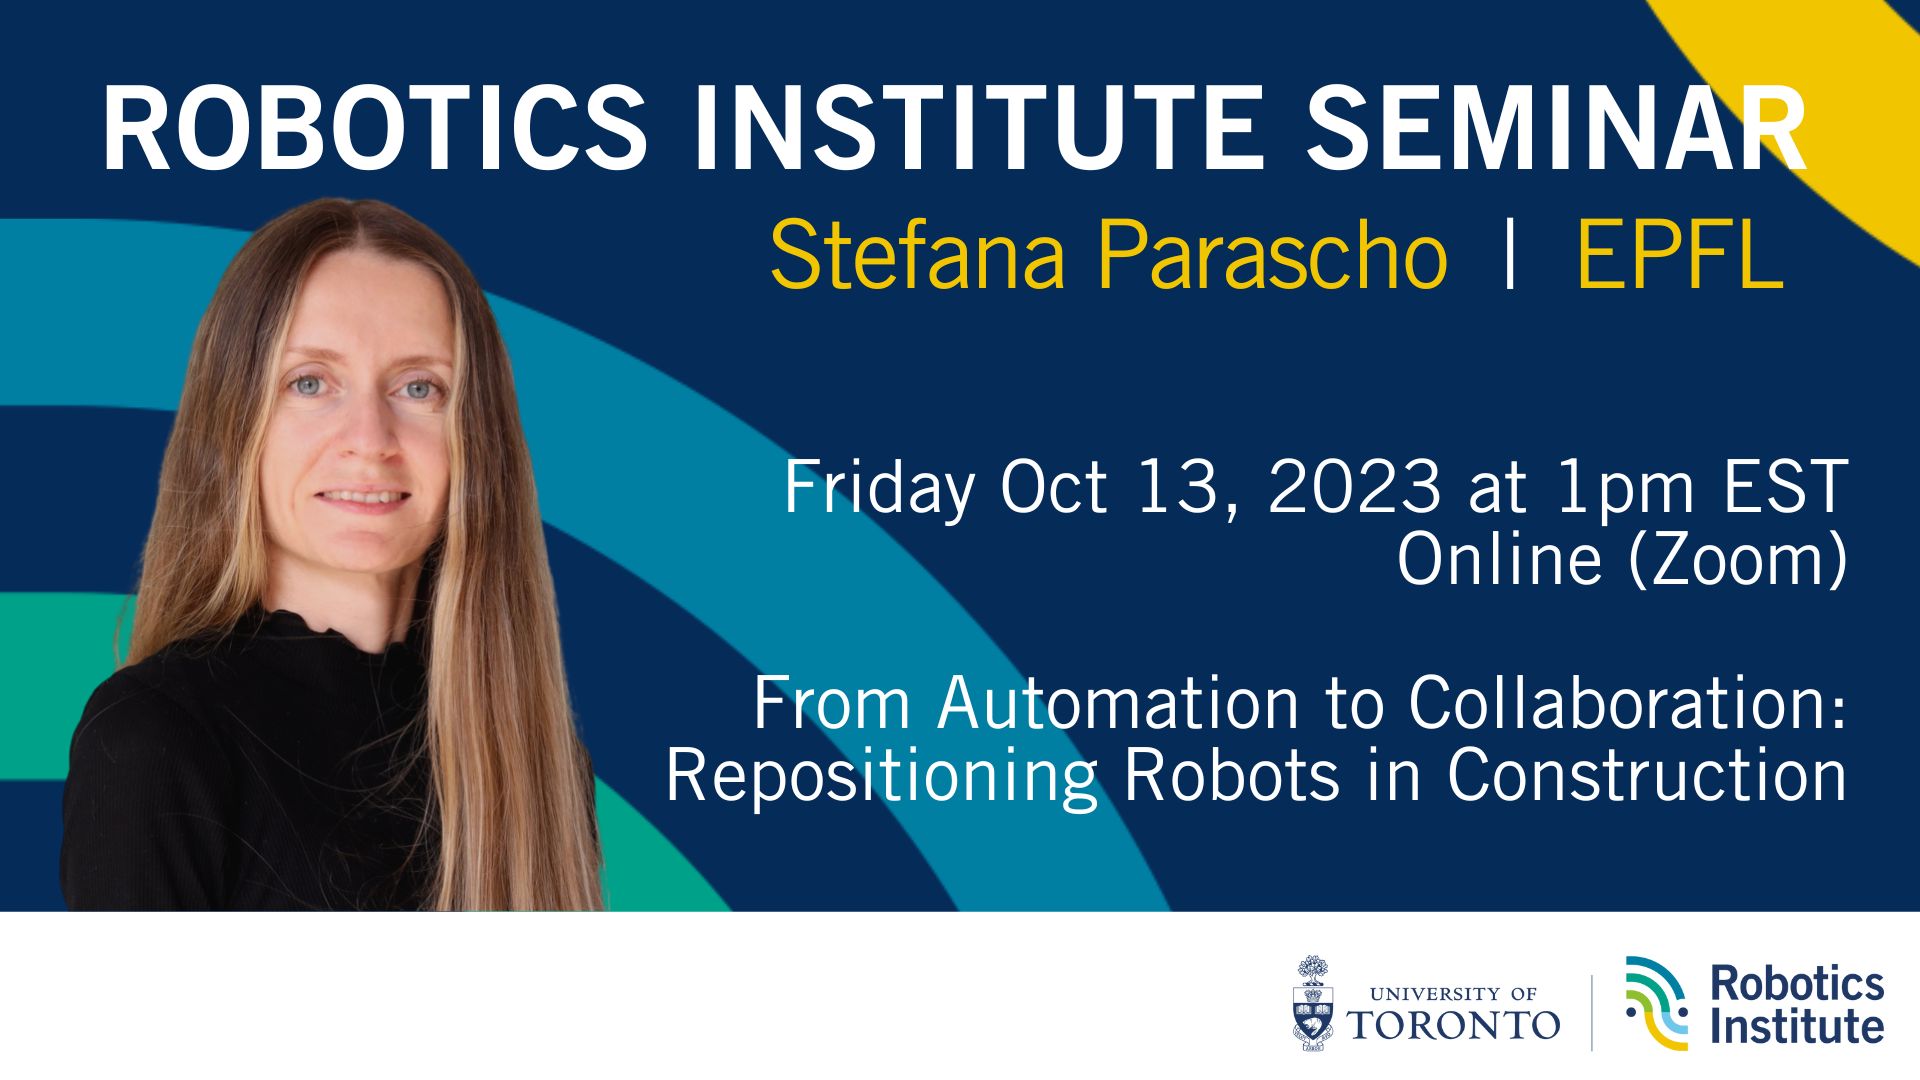
  35. Prof. Parascho lecture event at University of Toronto
    Prof. Parascho was invited to give a lecture on multi-agent robotic processes at the University of Toronto Robotics Institute.
    🎤 👩‍💻 💬
  36. Scientific Chair of AAG 2023
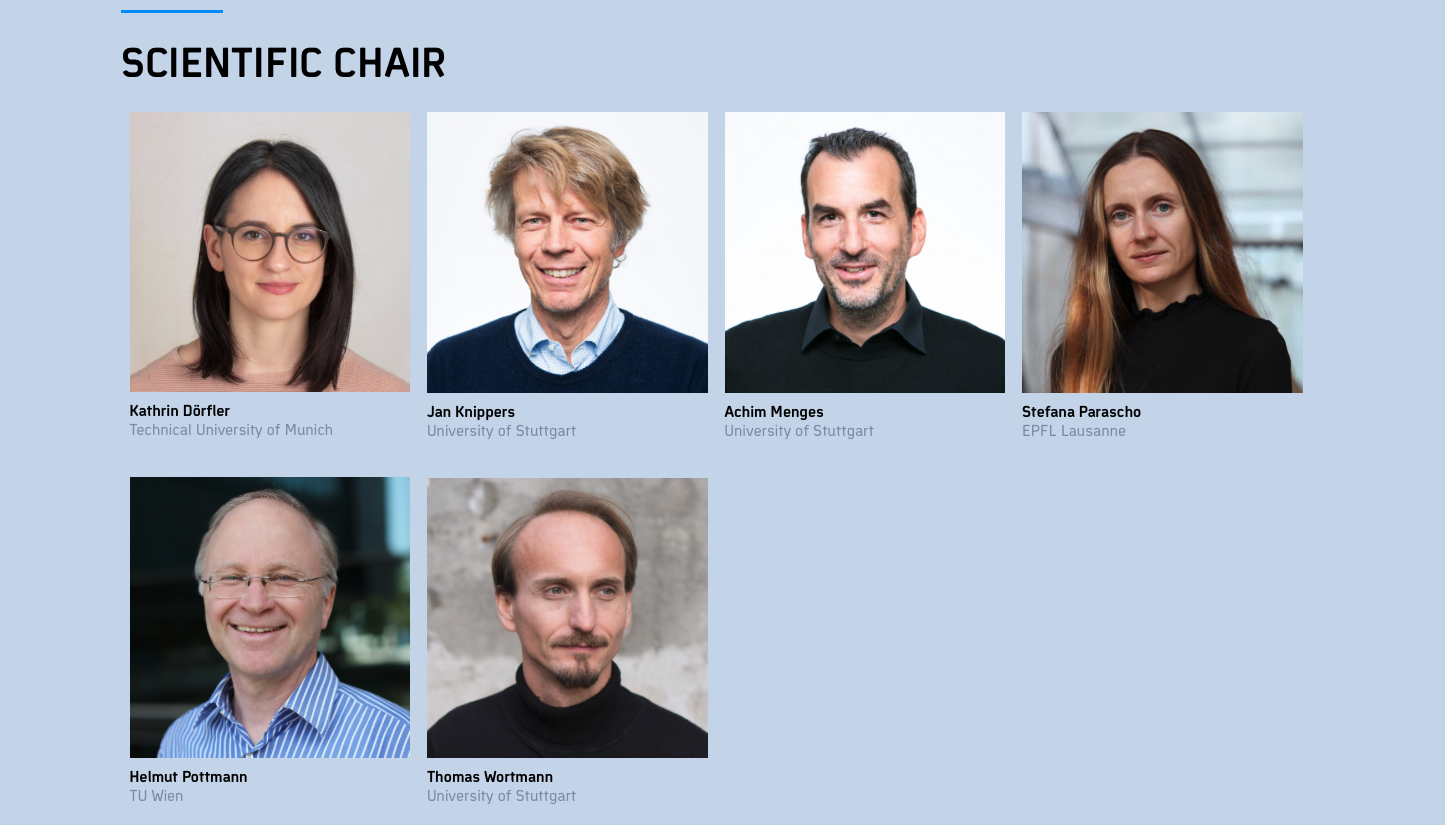
    Stefana Parascho is a Scientific Chair at AAG 2023, a multi-disciplinary conference connecting architects, engineers, and computer scientists in academia and industry. Find the conference proceedings online!
    🪑 👩 🪑
  37. Homepage for AAG 2023
    Congratulations to CRCL PhD Candidate Jingwen Wang, who will be presenting her paper on multi-robotic assembly during AAG 2023!
    🦾 🐚 🦾
  38. Homepage for ACM SCF 2023
    Congratulations to incoming CRCL PhD Candidate Gabriel Vallat, who will be presenting a paper at the 2023 ACM Symposium on Computational Fabrication!
    🤖 🧠 🤖
  39. Maxence receiving Best Paper award
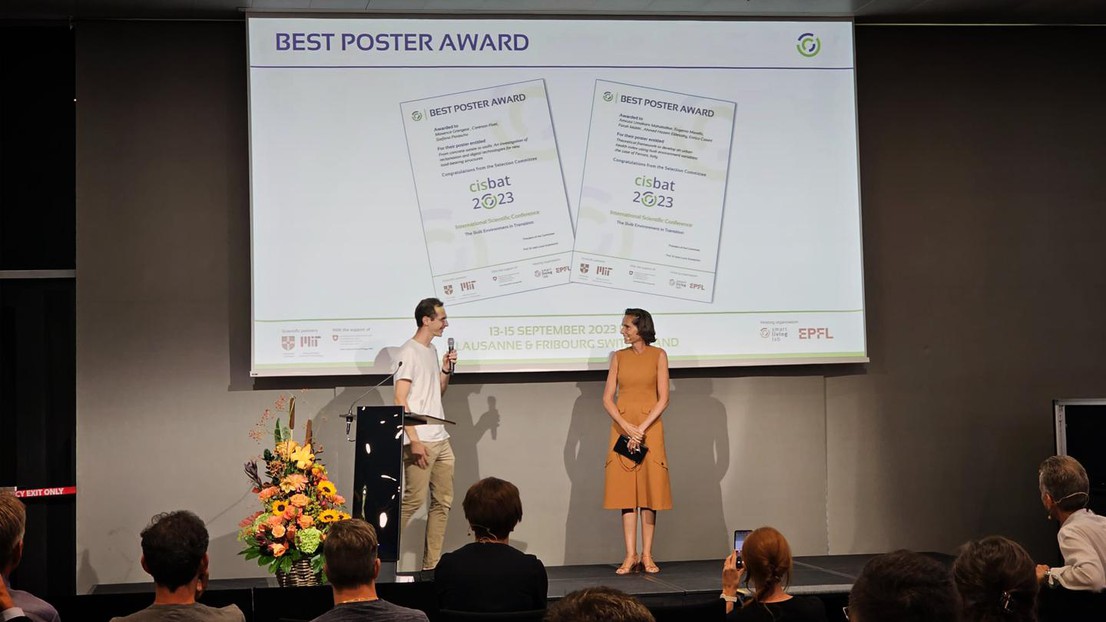
    Congratulations to PhD Candidate Maxence Grangeot, who won the Best Poster Award at CISBAT for his work on structures from reclaimed concrete!
    🏆 🏆 🏆
  40. Web page of the Future of Construction symposium
    The Future of Construction Symposium 2023 will take place from September 13 to 15 and will feature keynotes, poster sessions, and workshops revolving around human-machine collaborations in design and construction. Find out more and register for full access to on-site events!
    🔮 🚧 🔮
  41. Banner for postdoc opening
    CRCL is searching for a postdoctoral researcher for a 2 year project focusing on reconfiguration of timber structures! Learn more about the position opening.
    🪵 ♻ 🪵
  42. Banner for exhibition opening
    CRCL is presenting two projects with the opening of POSITIONS tonight at 18:00. Learn more at the event page.
    🌍 🏫 🌍
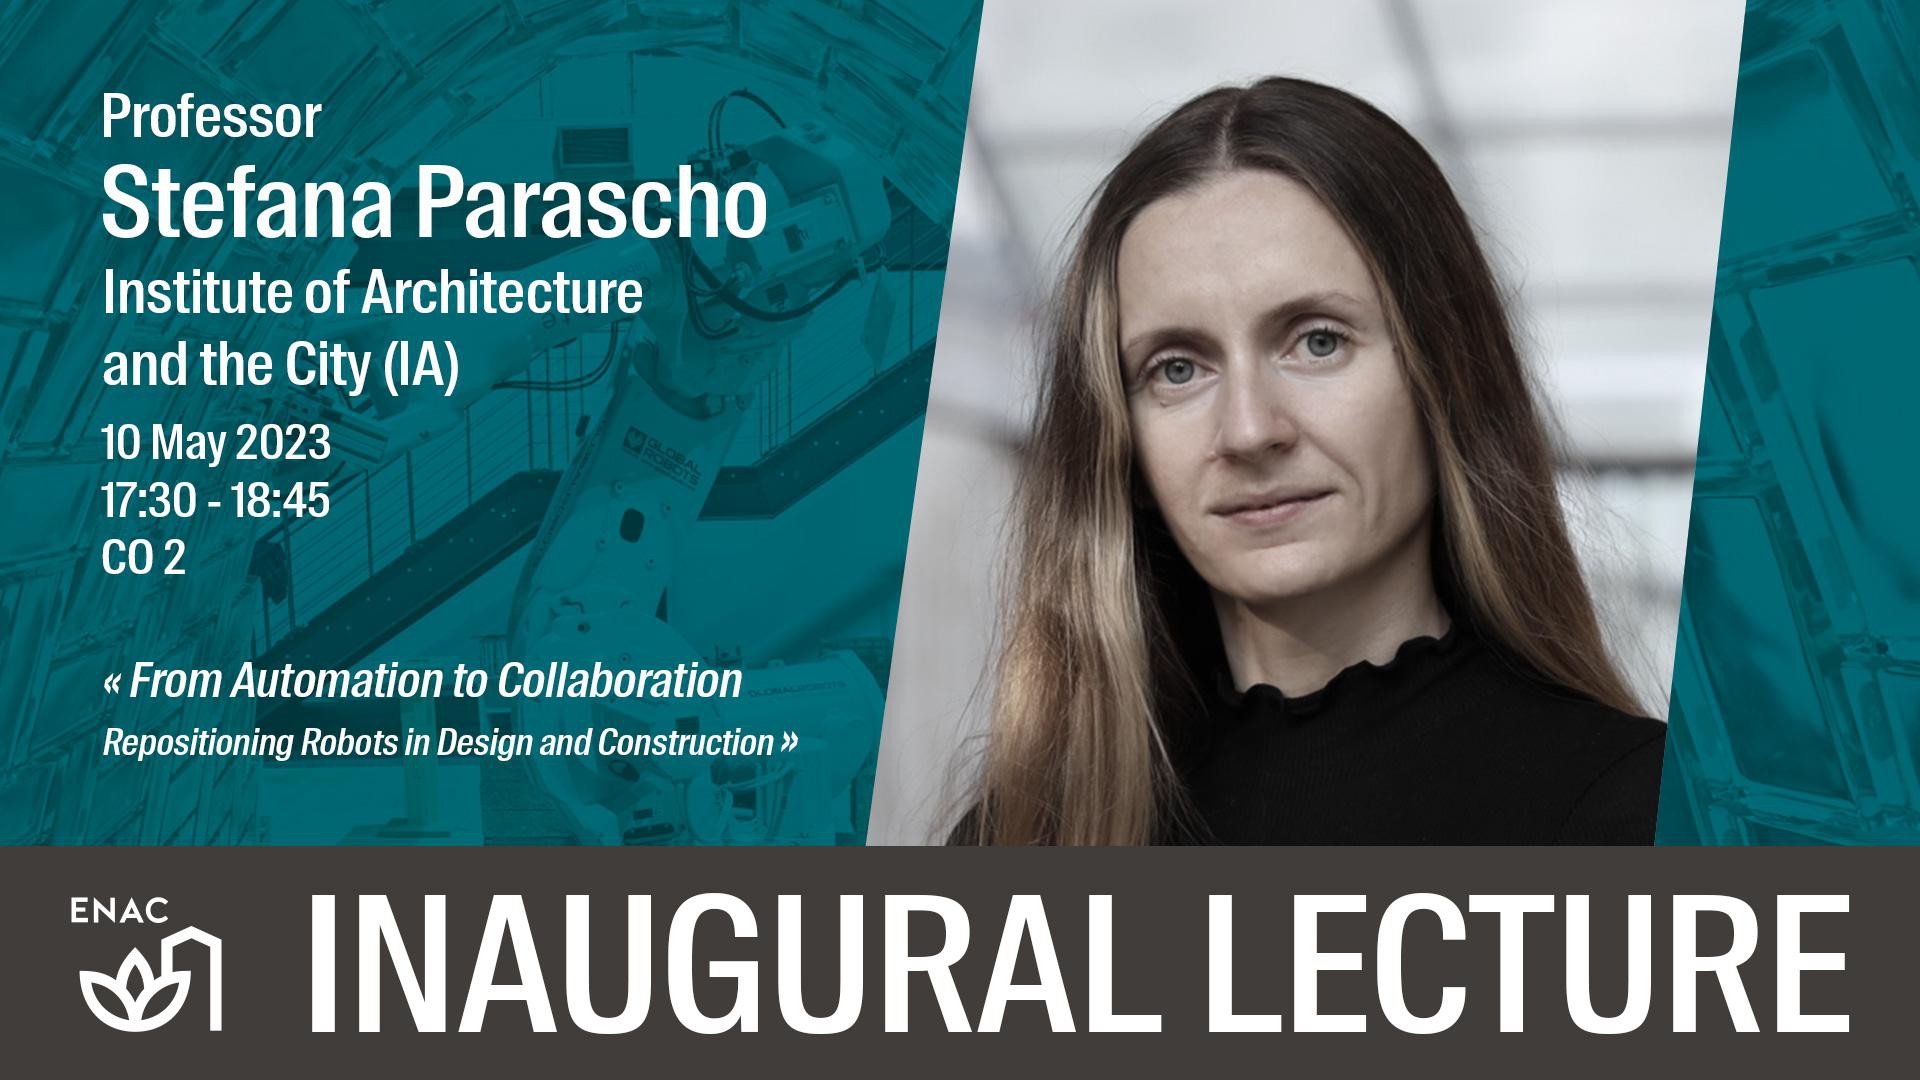
  43. Informational banner for the inaugural lecture
    Stefana will be giving her inaugural lecture about design and construction robotics on May 10, from 17:30 to 18:45.
    ⚠️ ⚠️ ⚠️
  44. Photo of the paper access page
    Construction Robotics: From Automation to Collaboration by Prof. Dr. Stefana Parascho is available for download online.
    🛜 📝 🛜
  45. Cover of the 2021 ACADIA Publication
    The proceedings from ACADIA 2021 'Realignments: Toward Critical Computation' have been published and are available for free download or purchase in print.
    📚 📥 📚
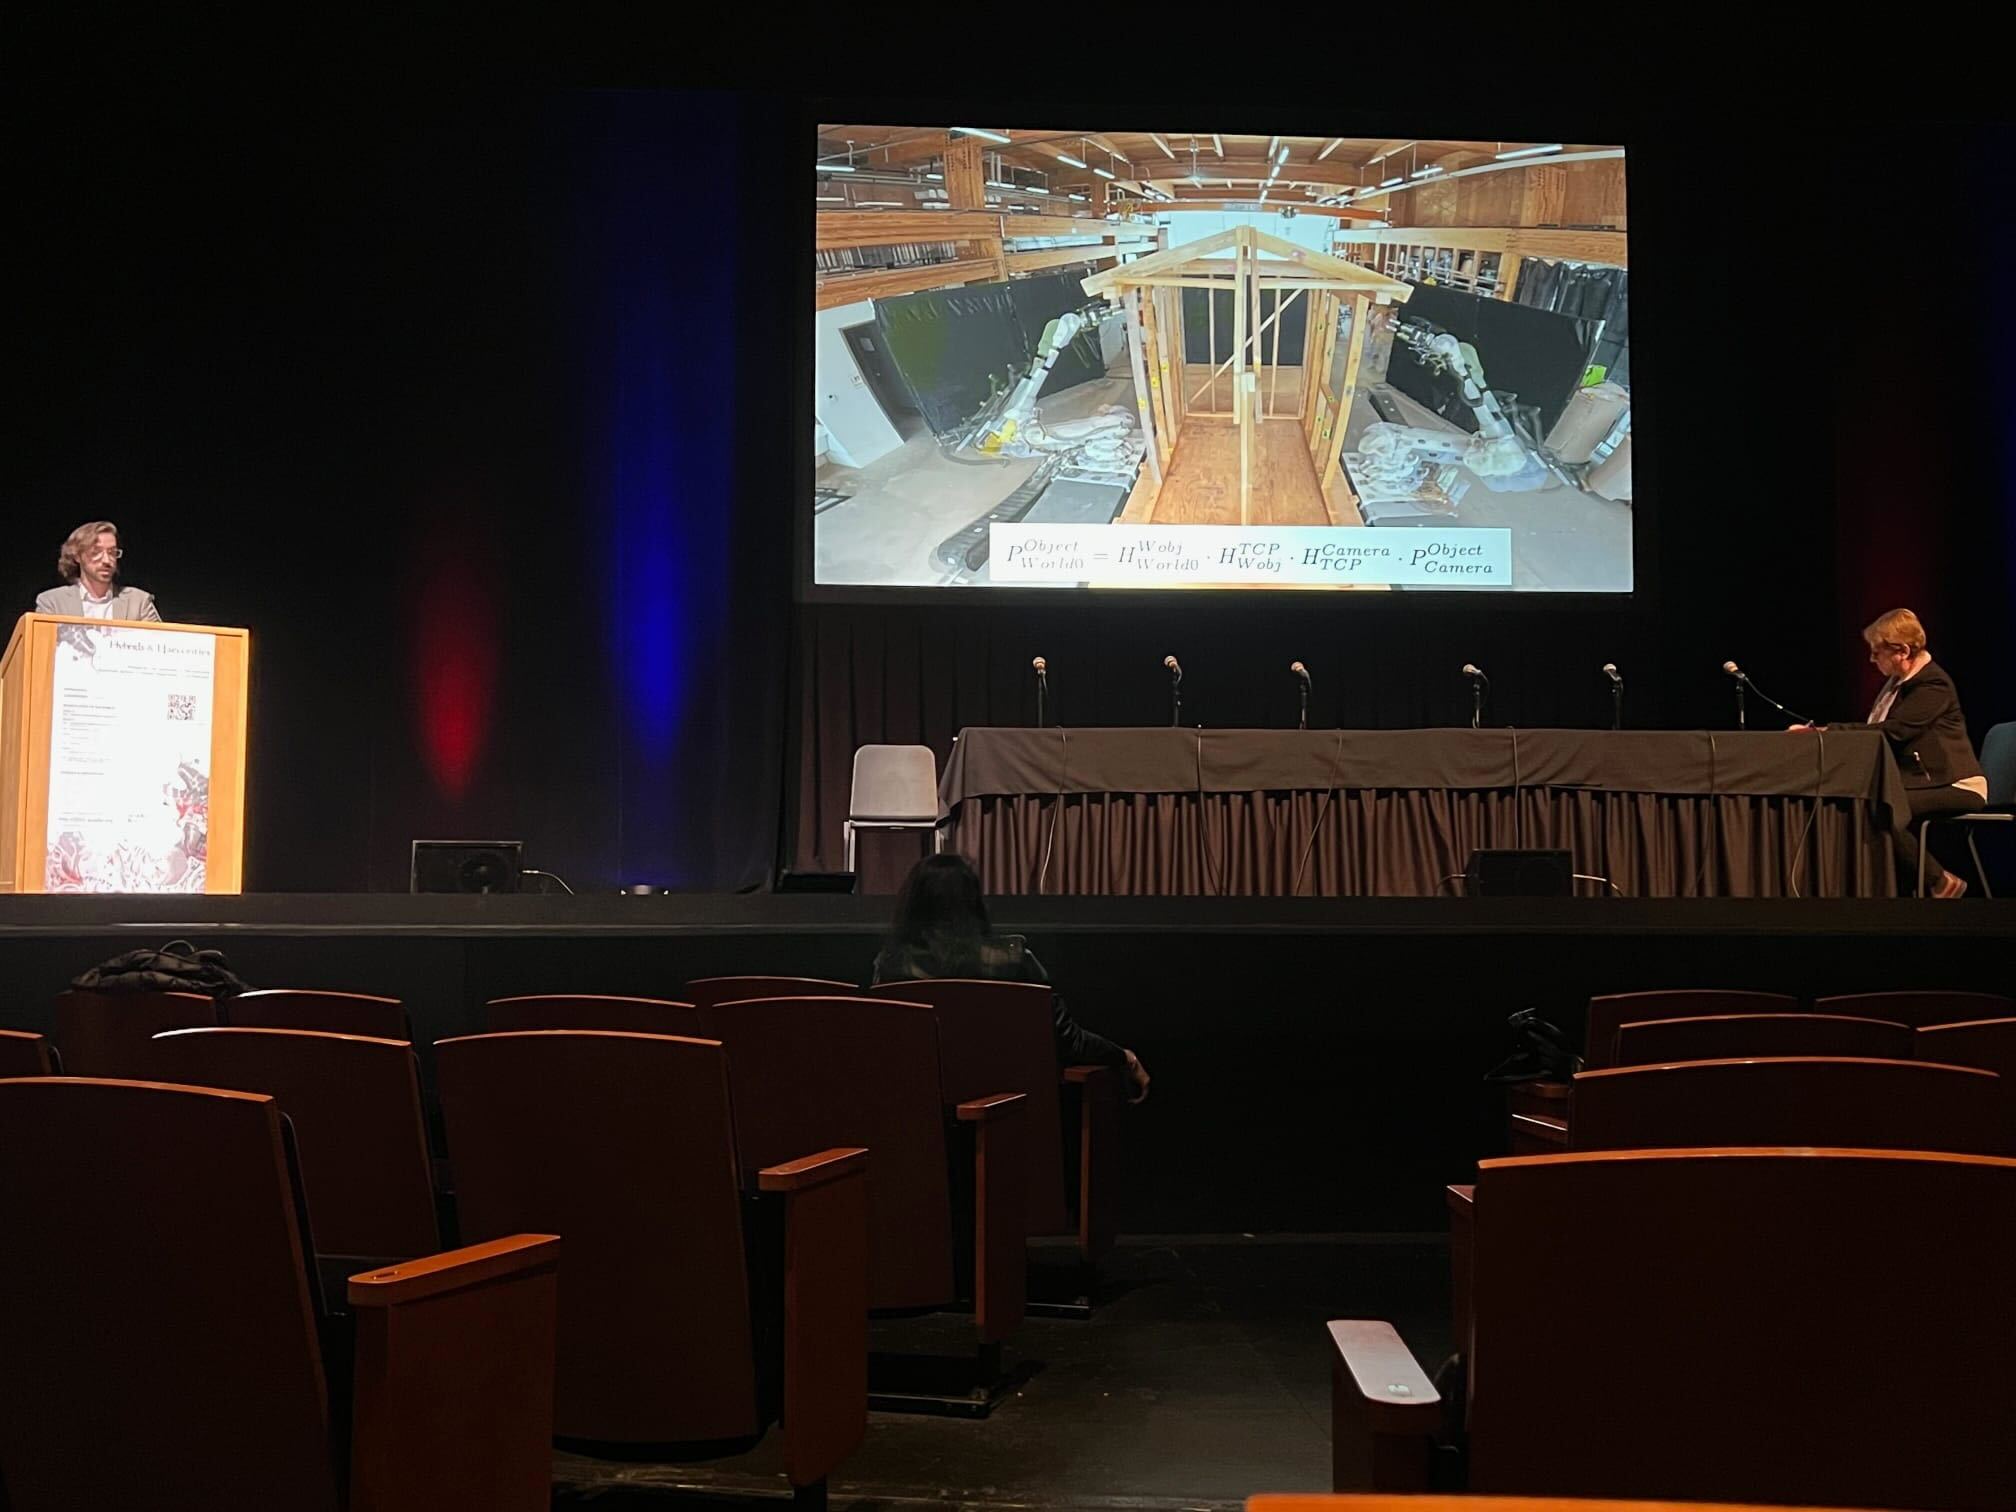
  46. Edvard Bruun presenting ZeroWaste at ACADIA
    Congratulations to CRCL external advisee Edvard Bruun, who presented research on robotic dis- and reassembly of timber structures at ACADIA 2022.
    🦾 🎤 🏠
  47. Photo of the lightweight bamboo structure BamX
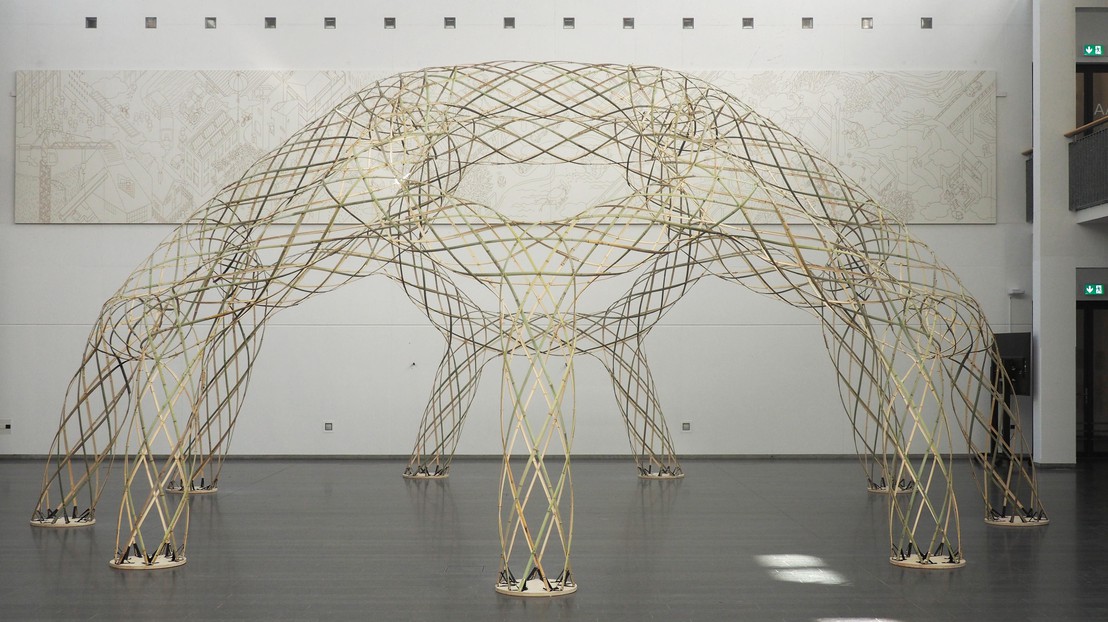
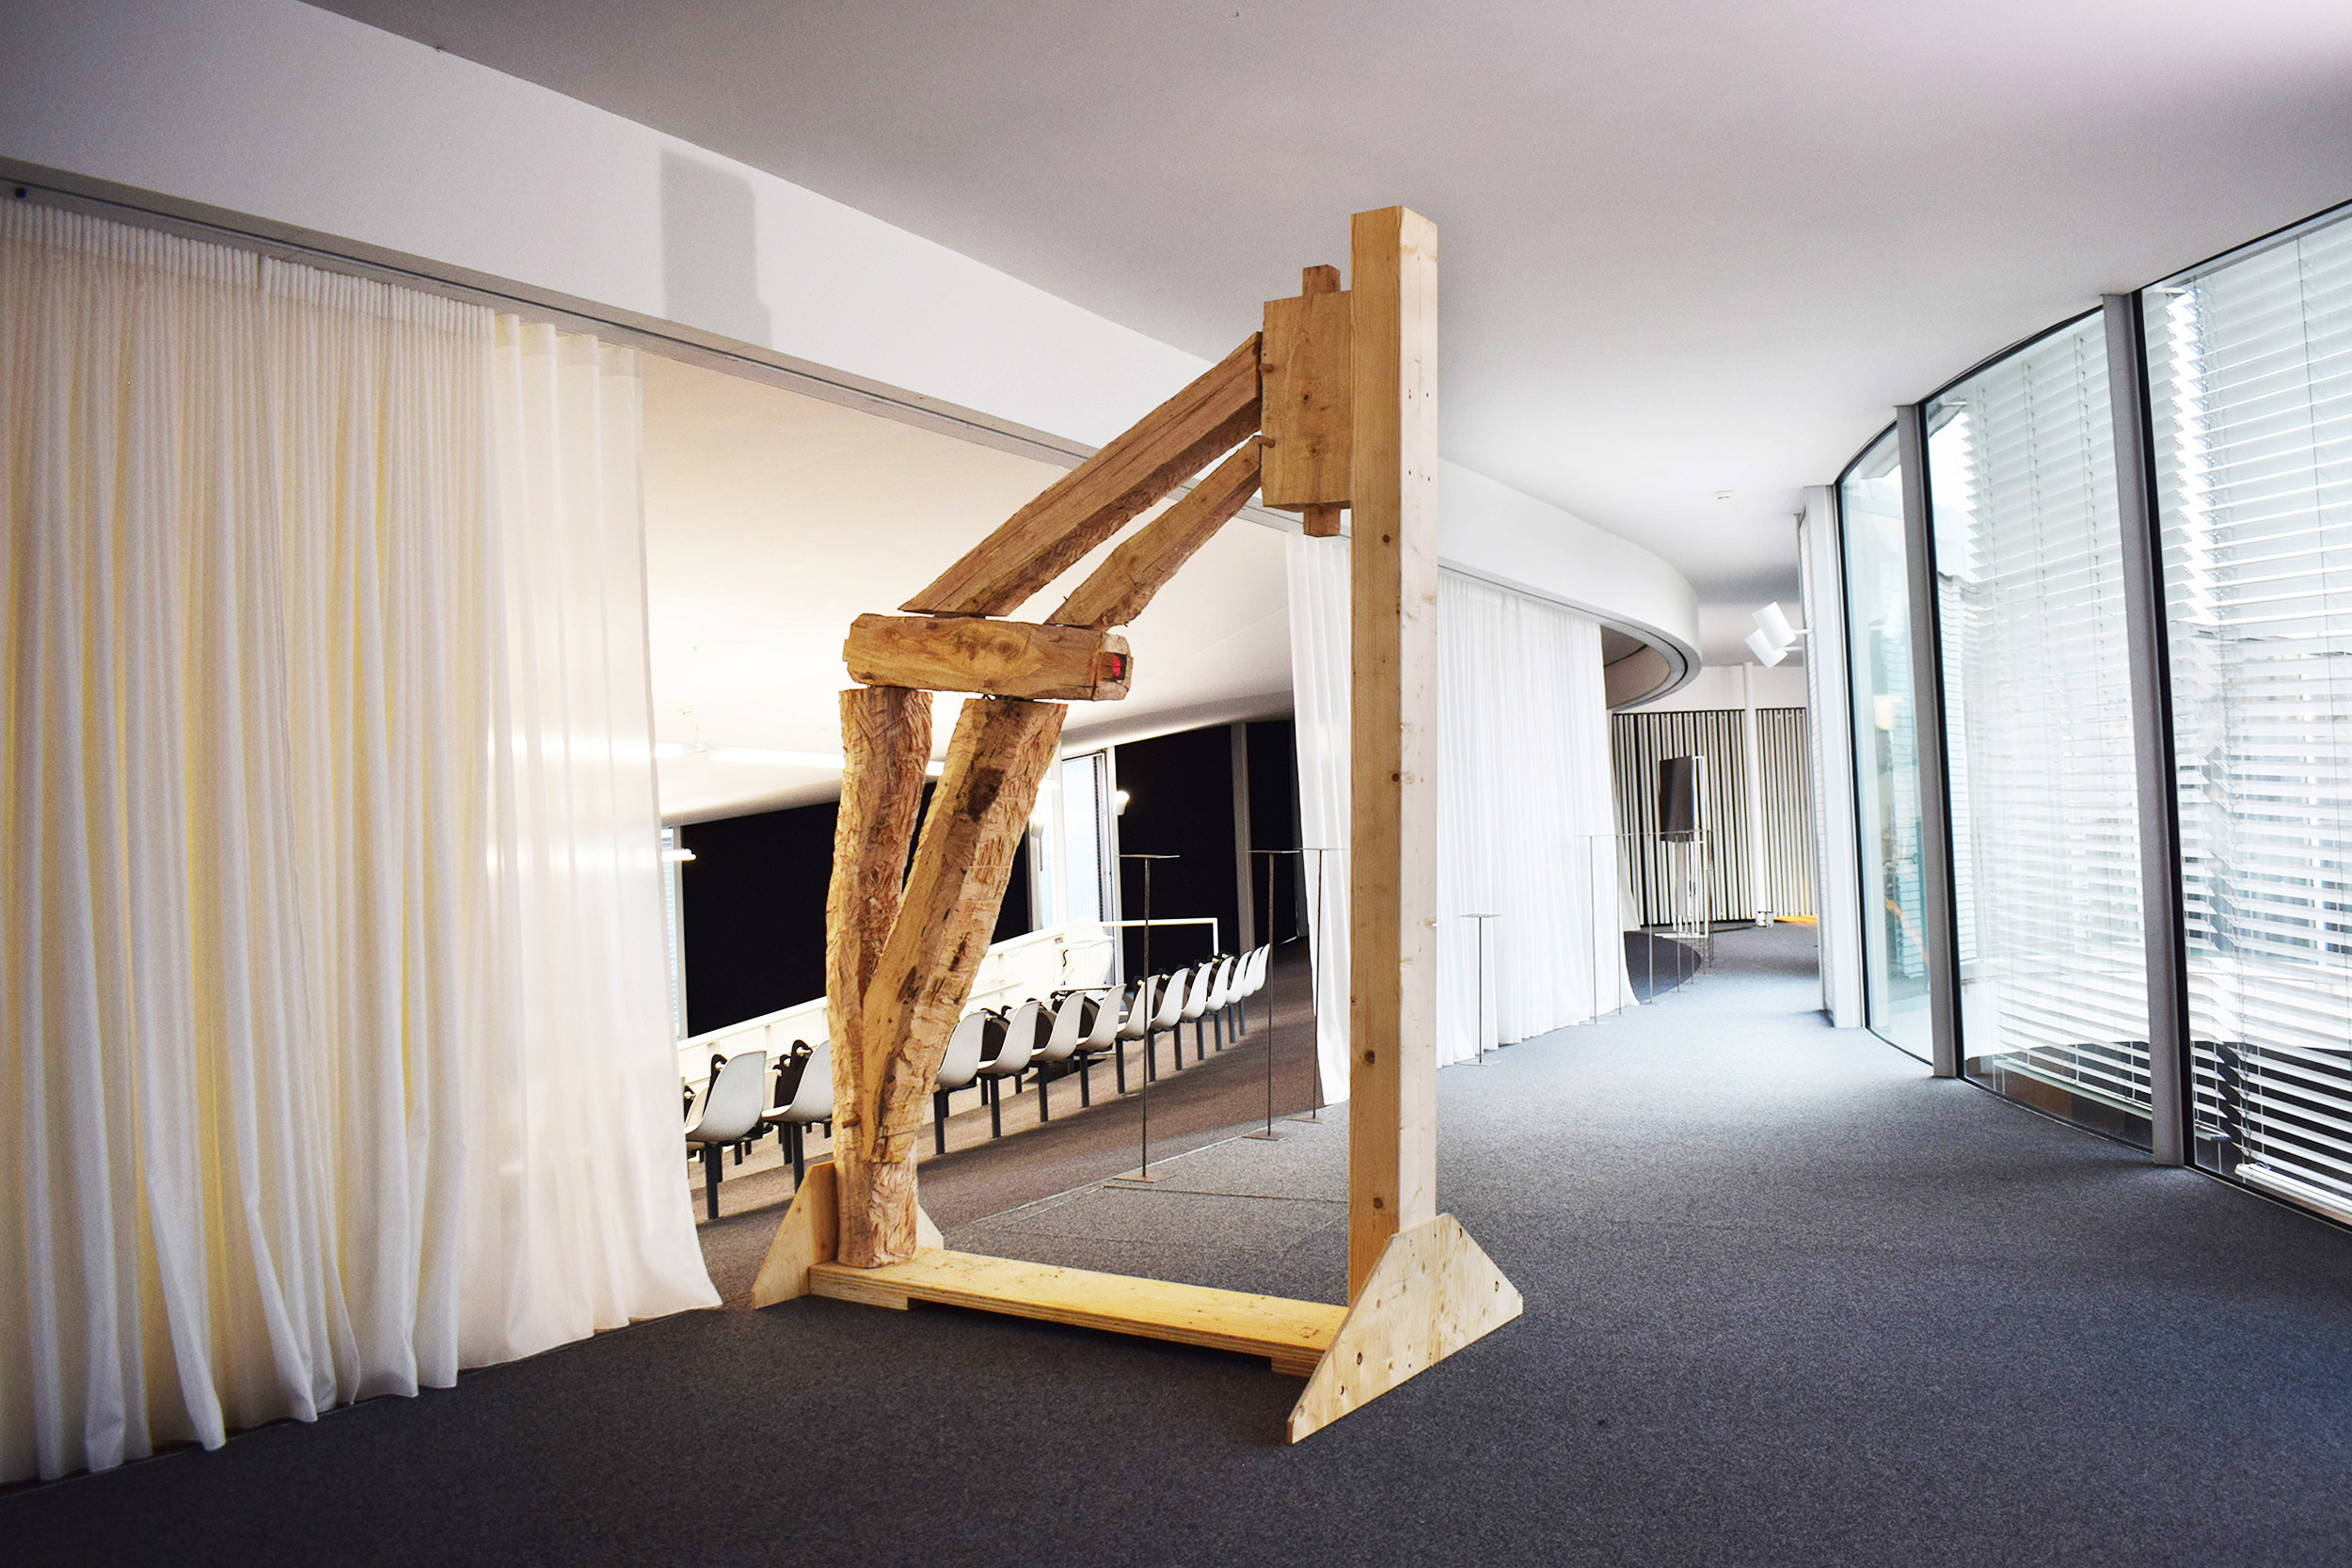
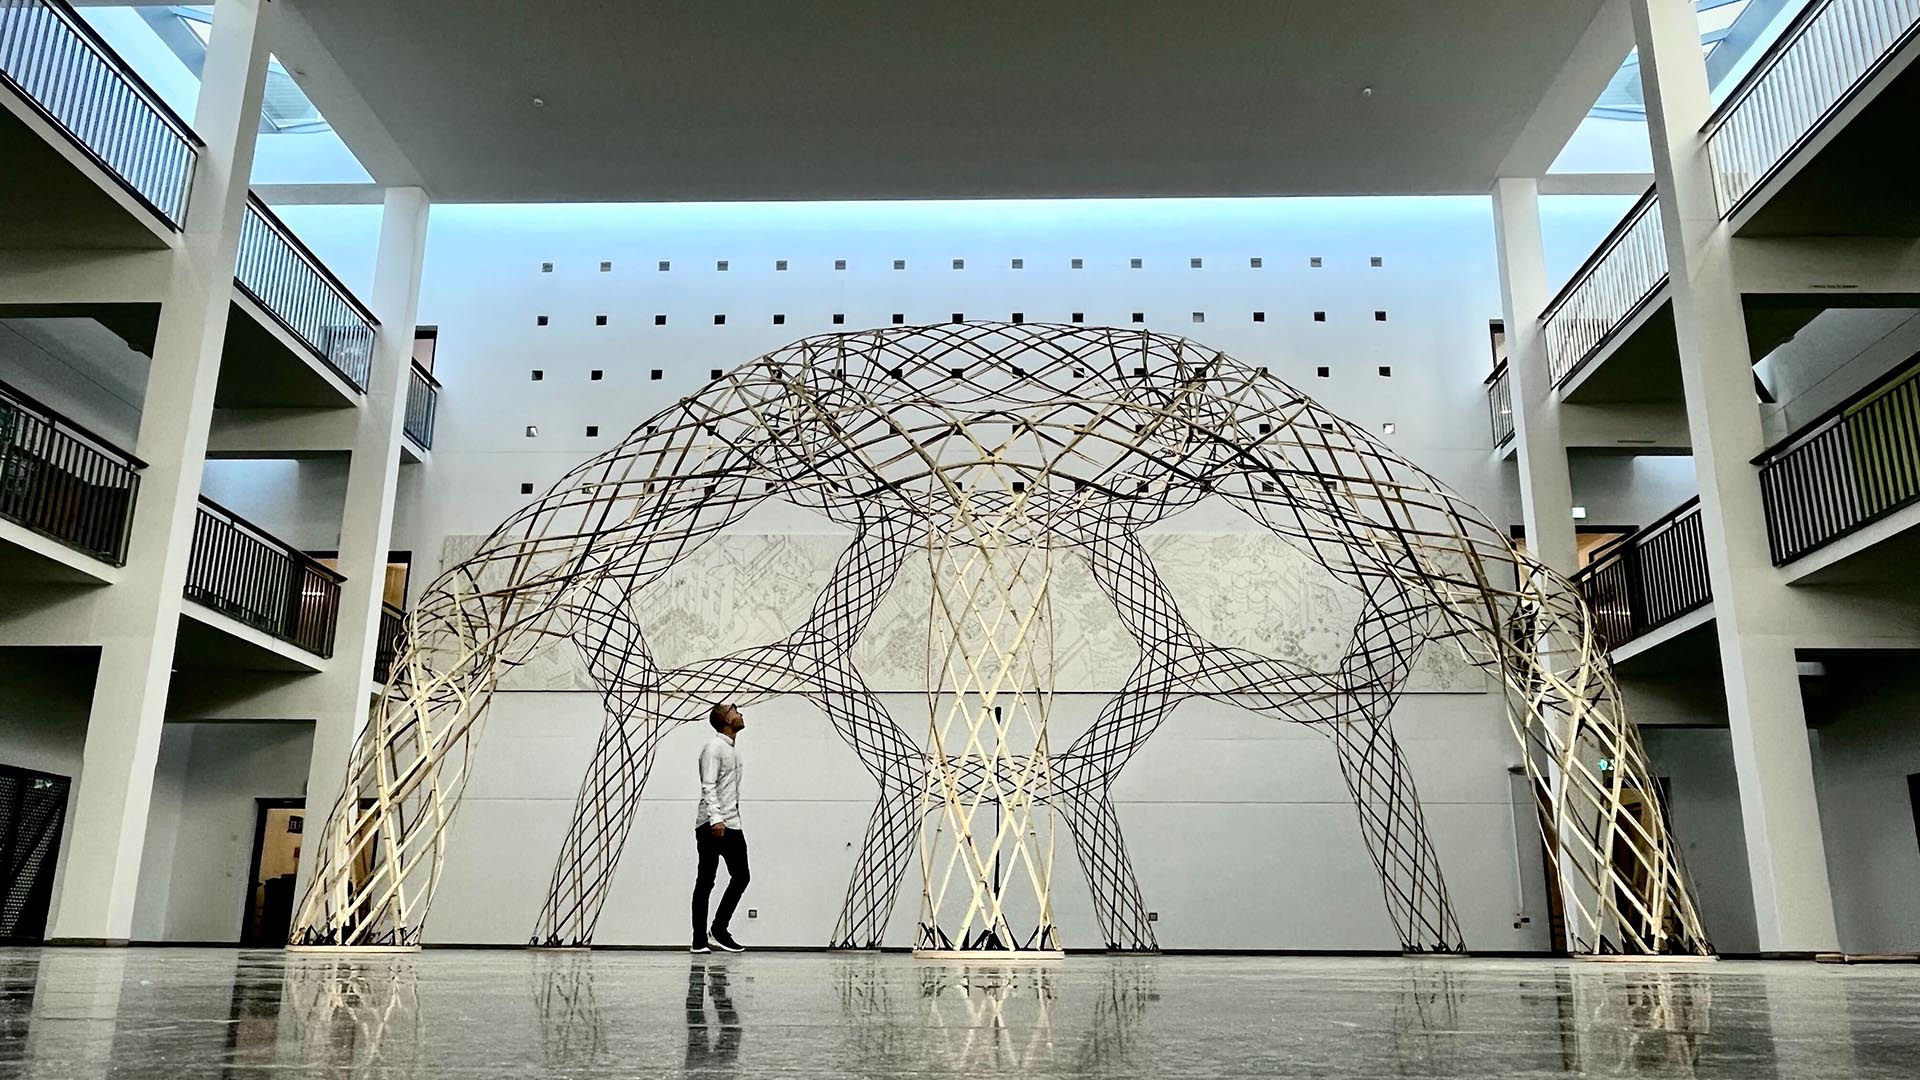
    In collaboration with GCM, ITKE and an independent artist, the CRCL unveils a lightweight bamboo structure, BamX, at the heart of the Architecture faculty building.
    🕸 🎍 🕸
  48. Stefana Parascho presenting at CIS
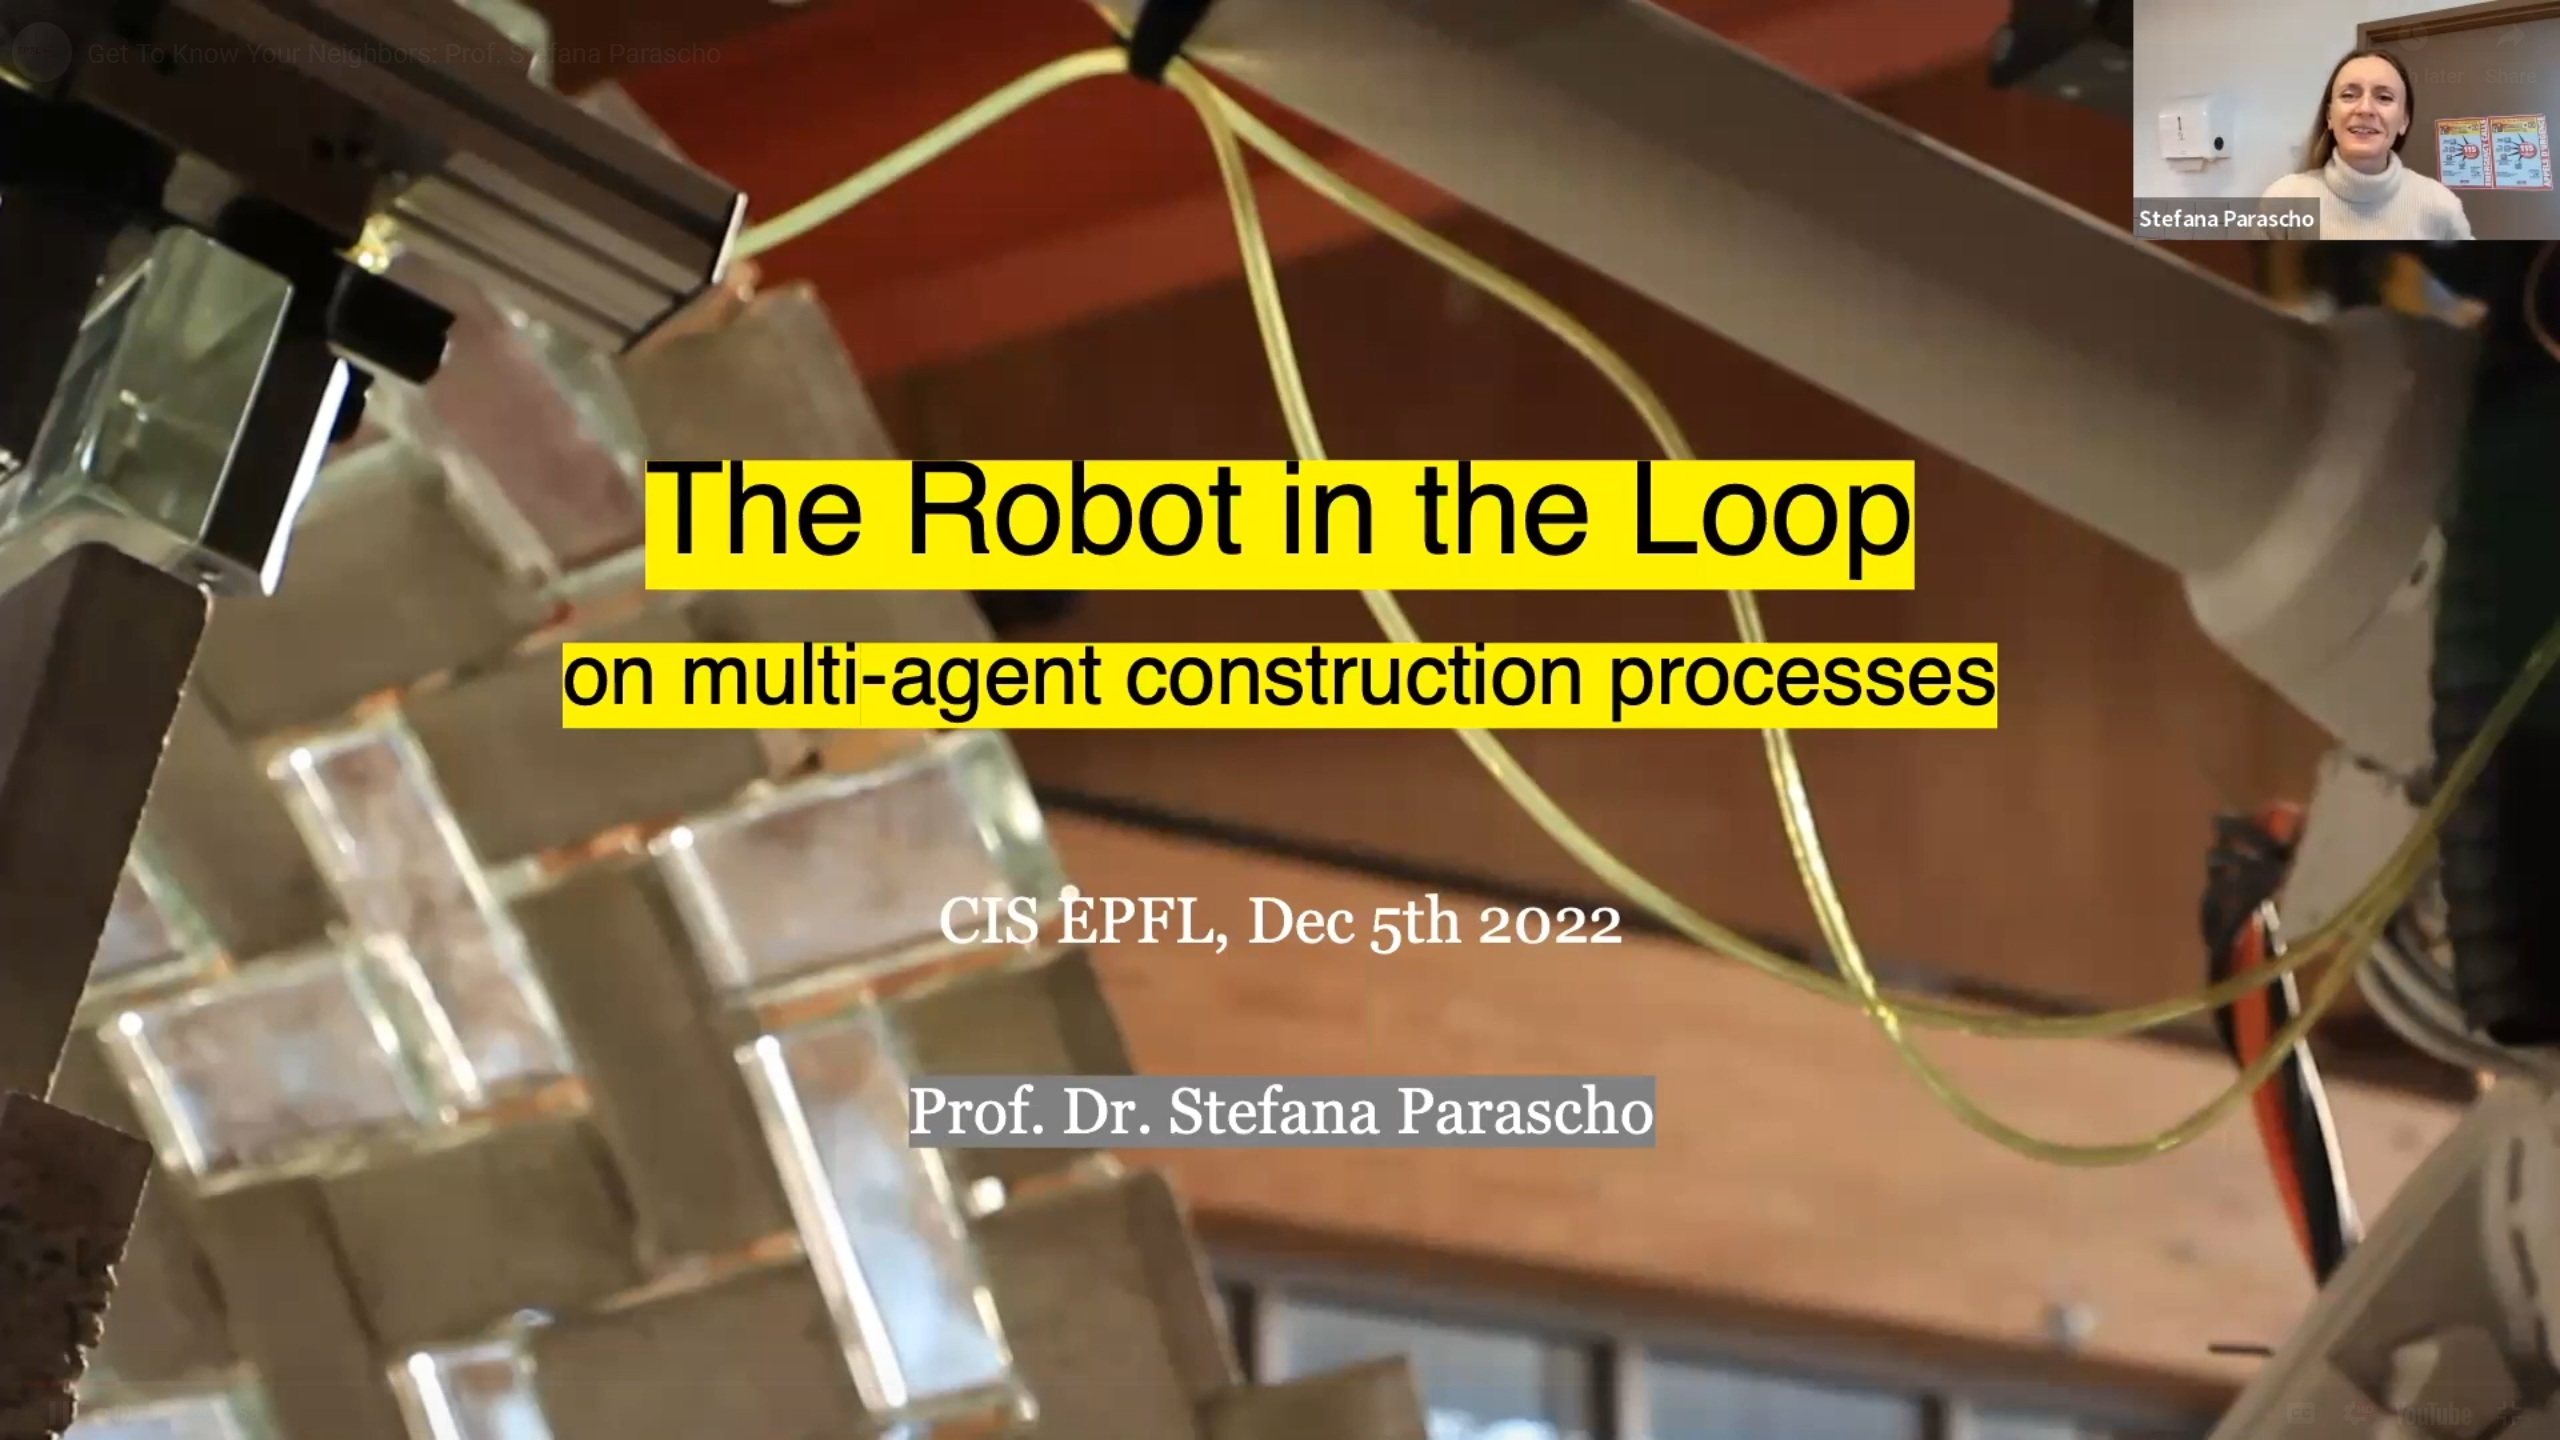
    Stefana was invited to give a lecture on multi-agent robotic processes at CIS. The recording is now available to watch online.
    🎤 👩‍💻 💬
  49. Robotic assembly prototype
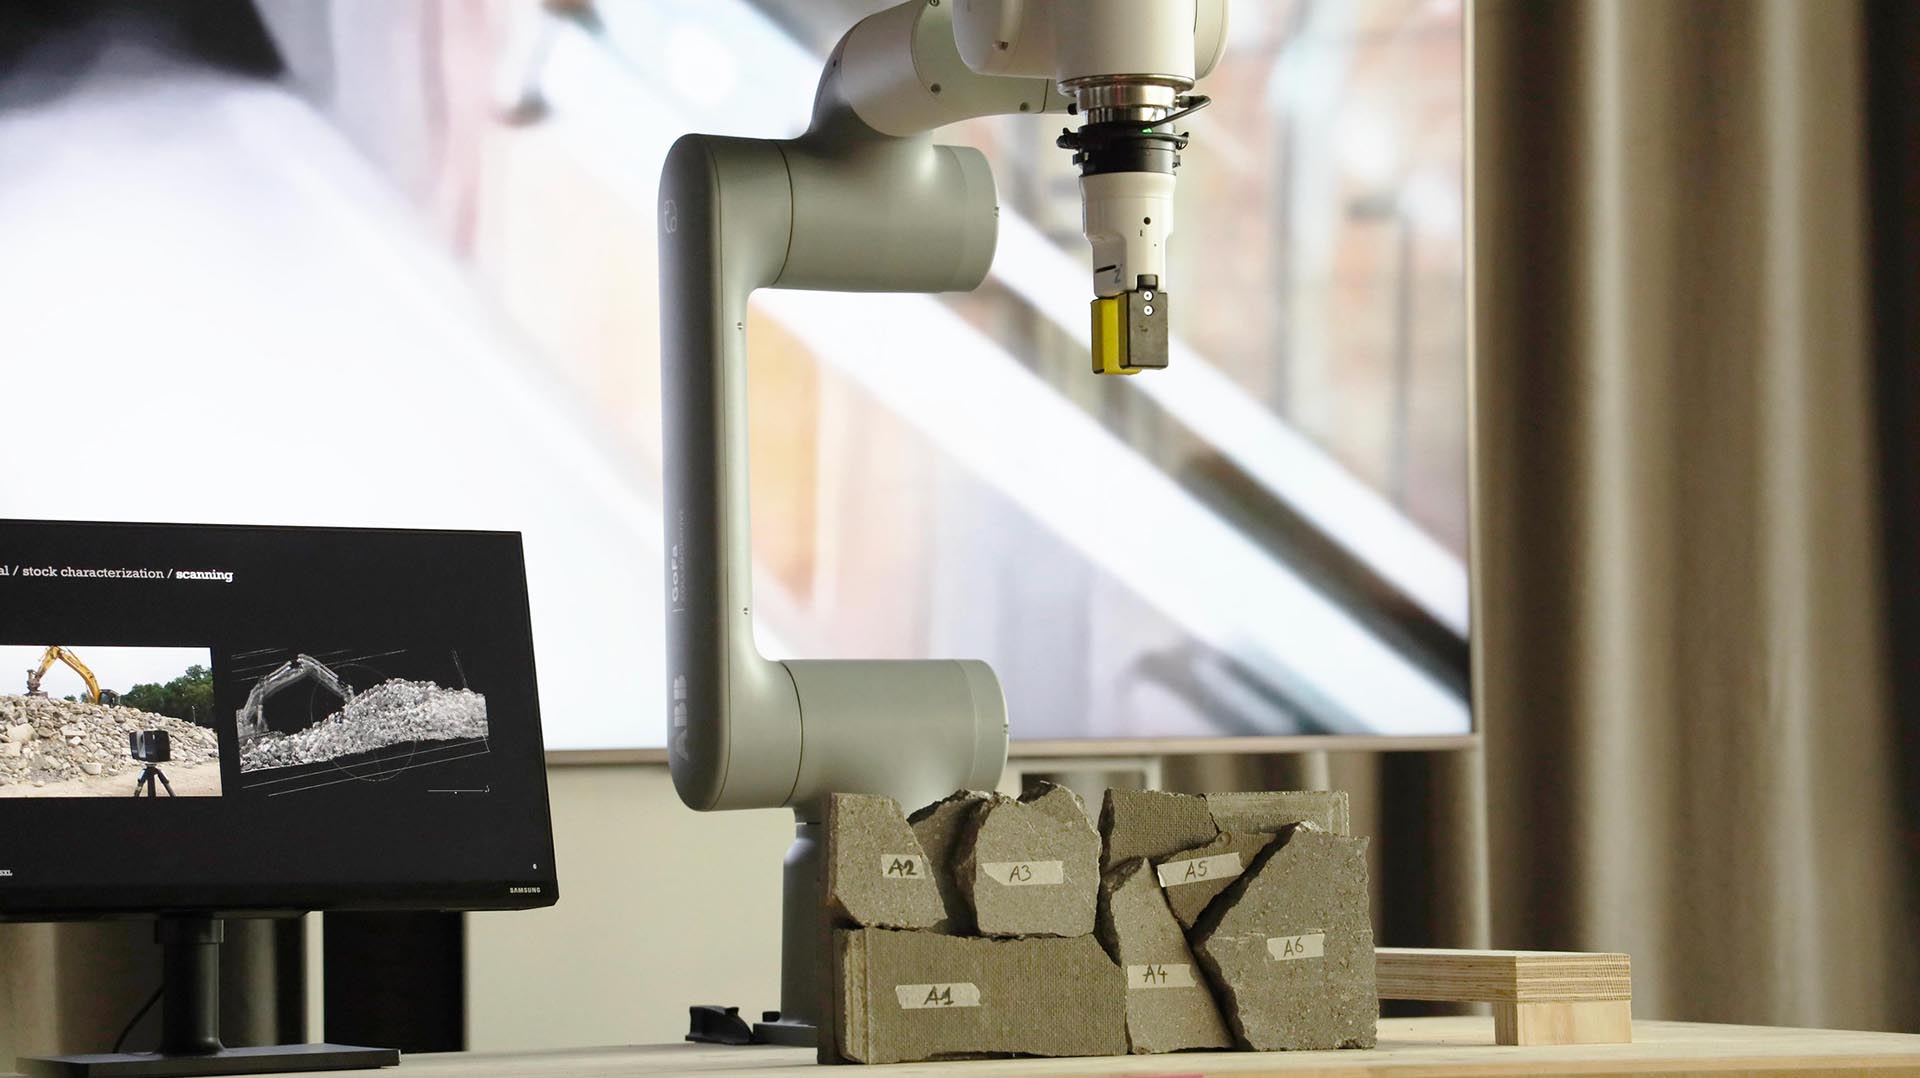
    CRCL presented a robotic assembly prototype of reused concrete for the ENAC 20 years anniversary exhibition.
    ✨ 🎈 🎉
  50. Robotic assembly prototype
    Stefana Parascho was invited to give a lecture at the Smart Living Lab.
    🏡 👩‍💻 💬
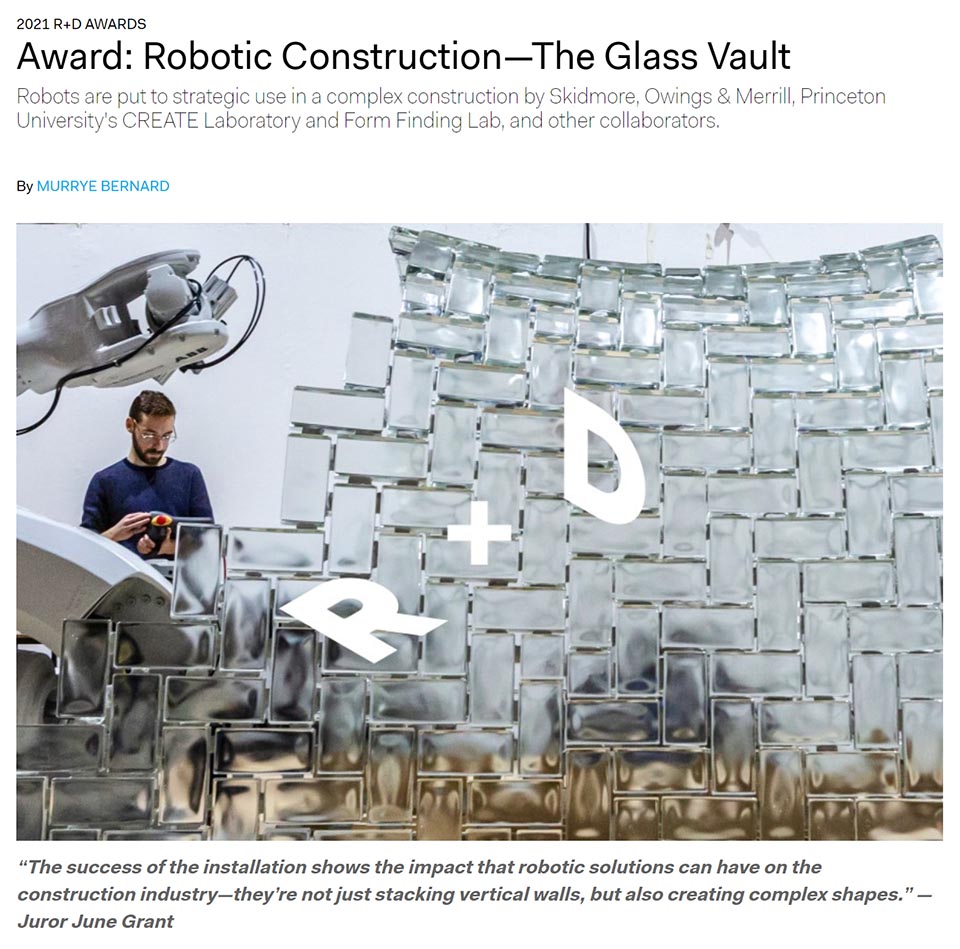
  51. Screenshot of Architect Magazine R+D Award website announcement
    Congrats to Isla Han, Edvard Bruun and Stefana Parascho for making this unique collaborative project happen.
    🏆 💎 🏆
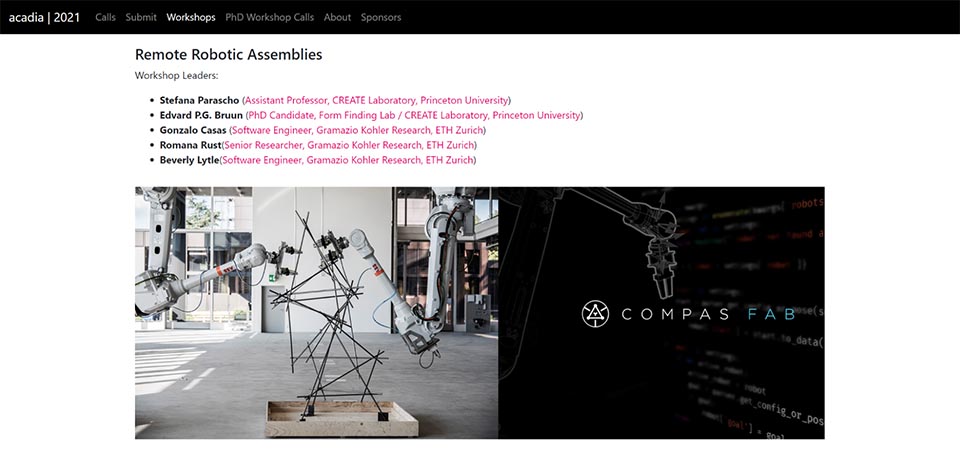
  52. Screenshot of ACADIA Workshops website
    We are teaching a workshop at this year's ACADIA conference together with Gramazio Kohler Research, ETH Zurich - Controlling robots remotely through COMPAS FAB. Join us by registering here!!
    🤖 👩 ‍💻
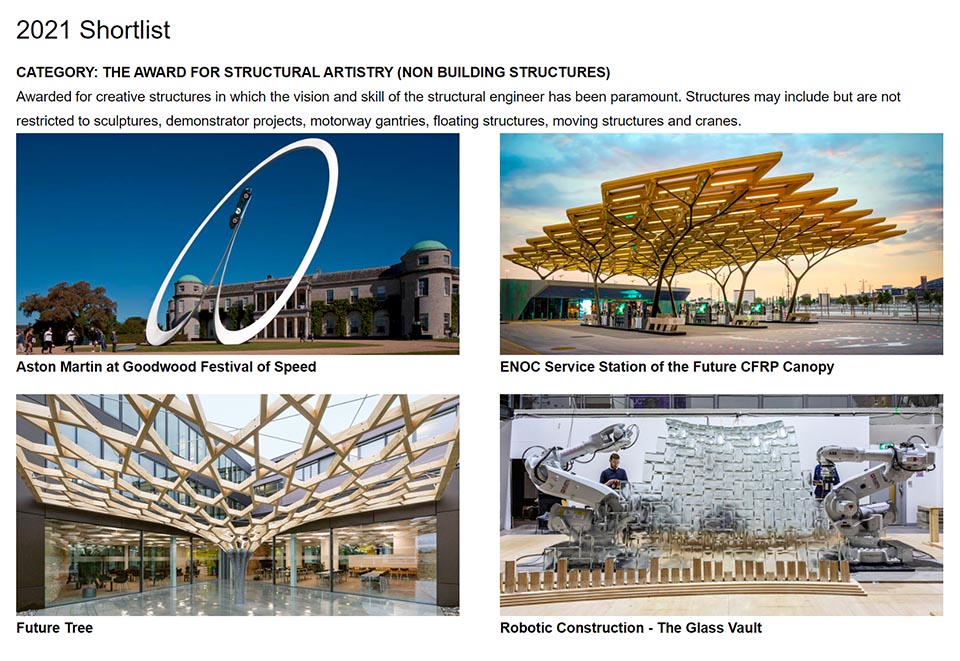
  53. Screenshot of the Structural Awards website
    LightVault shortlisted for the Structural Awards 2021 - The Institution of Structural Engineers (IStructE)
    🤞 🤩 🤞
  54. Screenshot of Construction Robotics journal article website
    Our paper "Robotic additive construction of bar structures: unified sequence and motion planning" in collaboration with the Digital Structures Group MIT is published in Construction Robotics! Led by Yijiang Huang (MIT)
    👏 👏 👏
  55. Screenshot of the Women in Architecture Festival Berlin website
    Stefana Parascho speaking at the Women in Architecture Festival Berlin, hosted by the CyPhyLab TU Berlin. Watch the recording here.
    🏰 👩 🏰
  56. Screenshot of the ACADIA 2021 conference website
    Stefana Parascho is Co-Chairing this year's ACADIA Conference: "Realignments: toward critical computation" Nov 3rd - 6th. Save the dates!!
    💃 💃 💃
  57. Screenshot of Automation in Construction journal article website
    Our paper "Three cooperative robotic fabrication methods for the scaffold-free construction of a masonry arch" in collaboration with the Form Finding Lab is published in Automation in Construction Journal! Led by Edvard Bruun.
    🥳 🦾 🥳

 Do Robots Dream of Construction Sites? 

Exhibition at Archizoom
9 September–5 December 2026

↗ Opening Tuesday 8 September 2026 ↗
↓ Download the Brochure ↓

Poster featuring Research Project Robotoddler, Jingwen Wang et al. CRCL. Graphic design: Sophie Wietlisbach

Robots have long promised to relieve workers from dangerous and physically demanding tasks while making building faster and more efficient. Yet construction remains largely manual, environmentally destructive, and deeply dependent on human skill and judgement.

Do Robots Dream of Construction Sites? examines this contradiction. Through robotic demonstrations, prototypes, films, and research developed at EPFL, the exhibition explores alternatives to automation as replacement: processes in which humans and machines assemble, adapt, experiment, and build together.
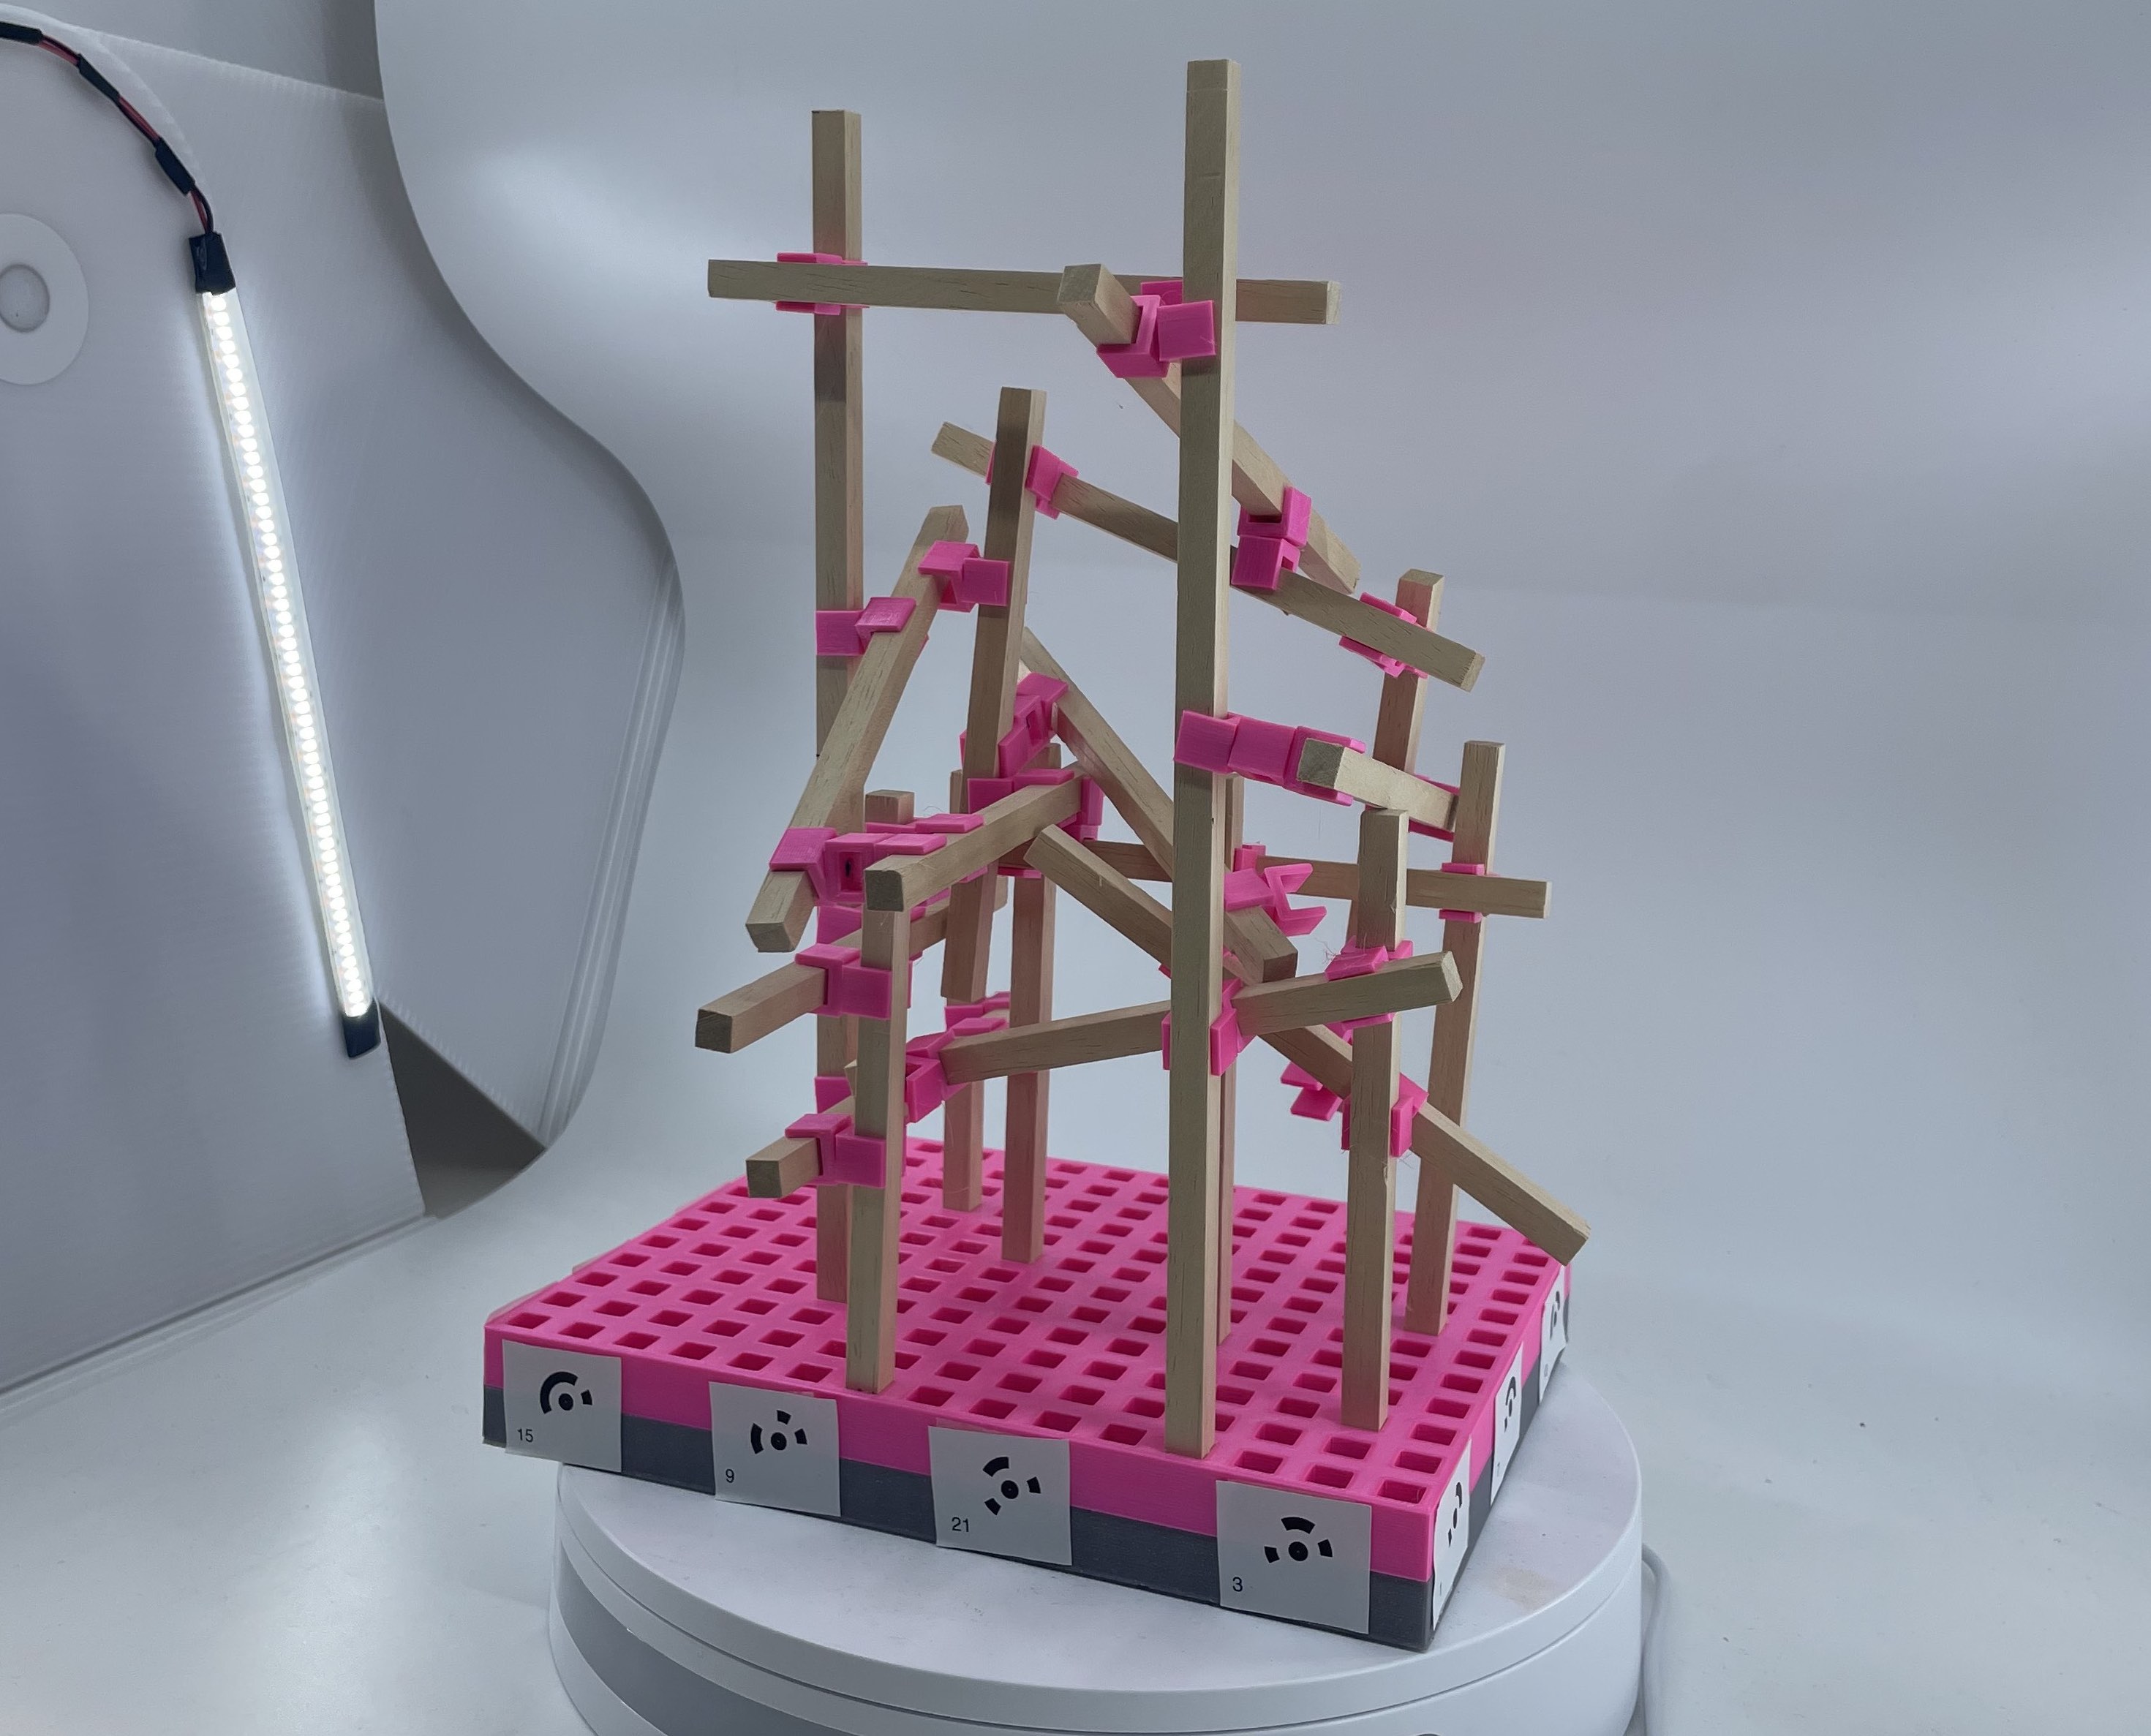
📸 ReConfig, Human-robot adaptive workflows for disassembly, repair, and construction. CRCL, EPFL, 2026. Photo: Dalila Romero Zenker
Robots for what?
Efficient for whom?
What stays human?

The exhibition brings together projects addressing automation, labour, and sustainability in construction. It situates contemporary robotics within a longer history of mechanisation, industrial production, and automation.

Through live robotic demonstrations, built prototypes, films, and documentation, the works range from autonomous assembly to collaborative processes in which humans and machines build, adapt, and respond to uncertain conditions.

Rather than imagining robots simply as substitutes for workers, the exhibition asks how machines might support human capacities and contribute to more adaptive and resource-conscious ways of building.

📸 Truss from Trash: A Human–Robot Framework for Adaptive Timber Assembly on the Construction Floor. CRCL, EPFL 2026. Photo: Eric Duong & Eleni Skevaki

Vernissage — Tuesday 8 September
  • 18:15 Introduction by Cyril Veillon
  • 18:30 Discussion between Stefana Parascho and Aude Billard, moderated by Pier Vittorio Aureli
  • 19:30 Exhibition opening and welcome drinks
Guided Tours
  • Saturday 26 September — Night of the Museums
    Open 14:00–00:00, guided tours in French at 15:00, 18:00, and 21:00
  • Tuesday 13 October — Festival Les Culturelles at EPFL
    Guided tours in French at 17:30
  • Saturday 7 and Sunday 8 November — Scientastic
    Guided tours in French at 11:00 and 16:00
  • Tuesday 24 November
    Guided tour by Stefana Parascho at 17:30, in English

Guided tours require registration. Additional tours can be organised upon request. Robots are in operation during guided tours.

The interactive robotic installation remains active from 14–24 October.
9 September–5 December 2026

Monday–Friday
09:00–17:00

Tuesday evenings
Open until 20:00

Archizoom, SG Building
Place Ada Lovelace
EPFL

Stefana Parascho
Exhibition lead, CRCL – Lab for Creative Computation

Dalila Romero Zenker
Exhibition development

Cyril Veillon
Archizoom direction

Solène Hoffmann
Curation and communication

Dimitri Kasparian
Curation, scenographic design and production

An exhibition developed by CRCL – Lab for Creative Computation in collaboration with Archizoom, EPFL.

Featuring research projects developed at CRCL, with thanks to past and present team members for their contributions.

 Publications 

Papers 54
  1. Crafting Structural Timber Trusses from Irregular Offcuts via Human–Robot Interaction Eleni Skevaki, Eric Duong, Hong-Bin Yang, and Stefana Parascho Construction Robotics DOI ↗
  2. Computational Design for Lunar Infrastructure Built with Unprocessed Stones Qianqing Wang, Jingwen Wang, Ran Xu, Danhui Dan, Stefana Parascho, and Katrin Beyer npj Space Exploration 2 (1): 8 DOI ↗
  3. Learning to Build: Autonomous Robotic Assembly of Stable Structures Without Predefined Plans Jingwen Wang, Johannes Kirschner, Paul Rolland, Luis Salamanca, and Stefana Parascho arXiv preprint 2602.23934 (preprint) Link ↗
  4. Intelligent Stone Masonry Robot for Sustainable Construction: Opportunities and Challenges Qianqing Wang, Jingwen Wang, Bryan German Pantoja Rosero, Stefana Parascho, and Katrin Beyer Proceedings of the 43rd International Symposium on Automation and Robotics in Construction (ISARC 2026) DOI ↗
  5. Spontaneous Tensegrity: Exploring Improvisational Design and Robotic Fabrication in Tensegrity Structures Isla Xi Han and Stefana Parascho Robotic Fabrication in Architecture, Art and Design 2024 (ROB|ARCH 2024), pp. 47–61, Springer, Cham DOI ↗
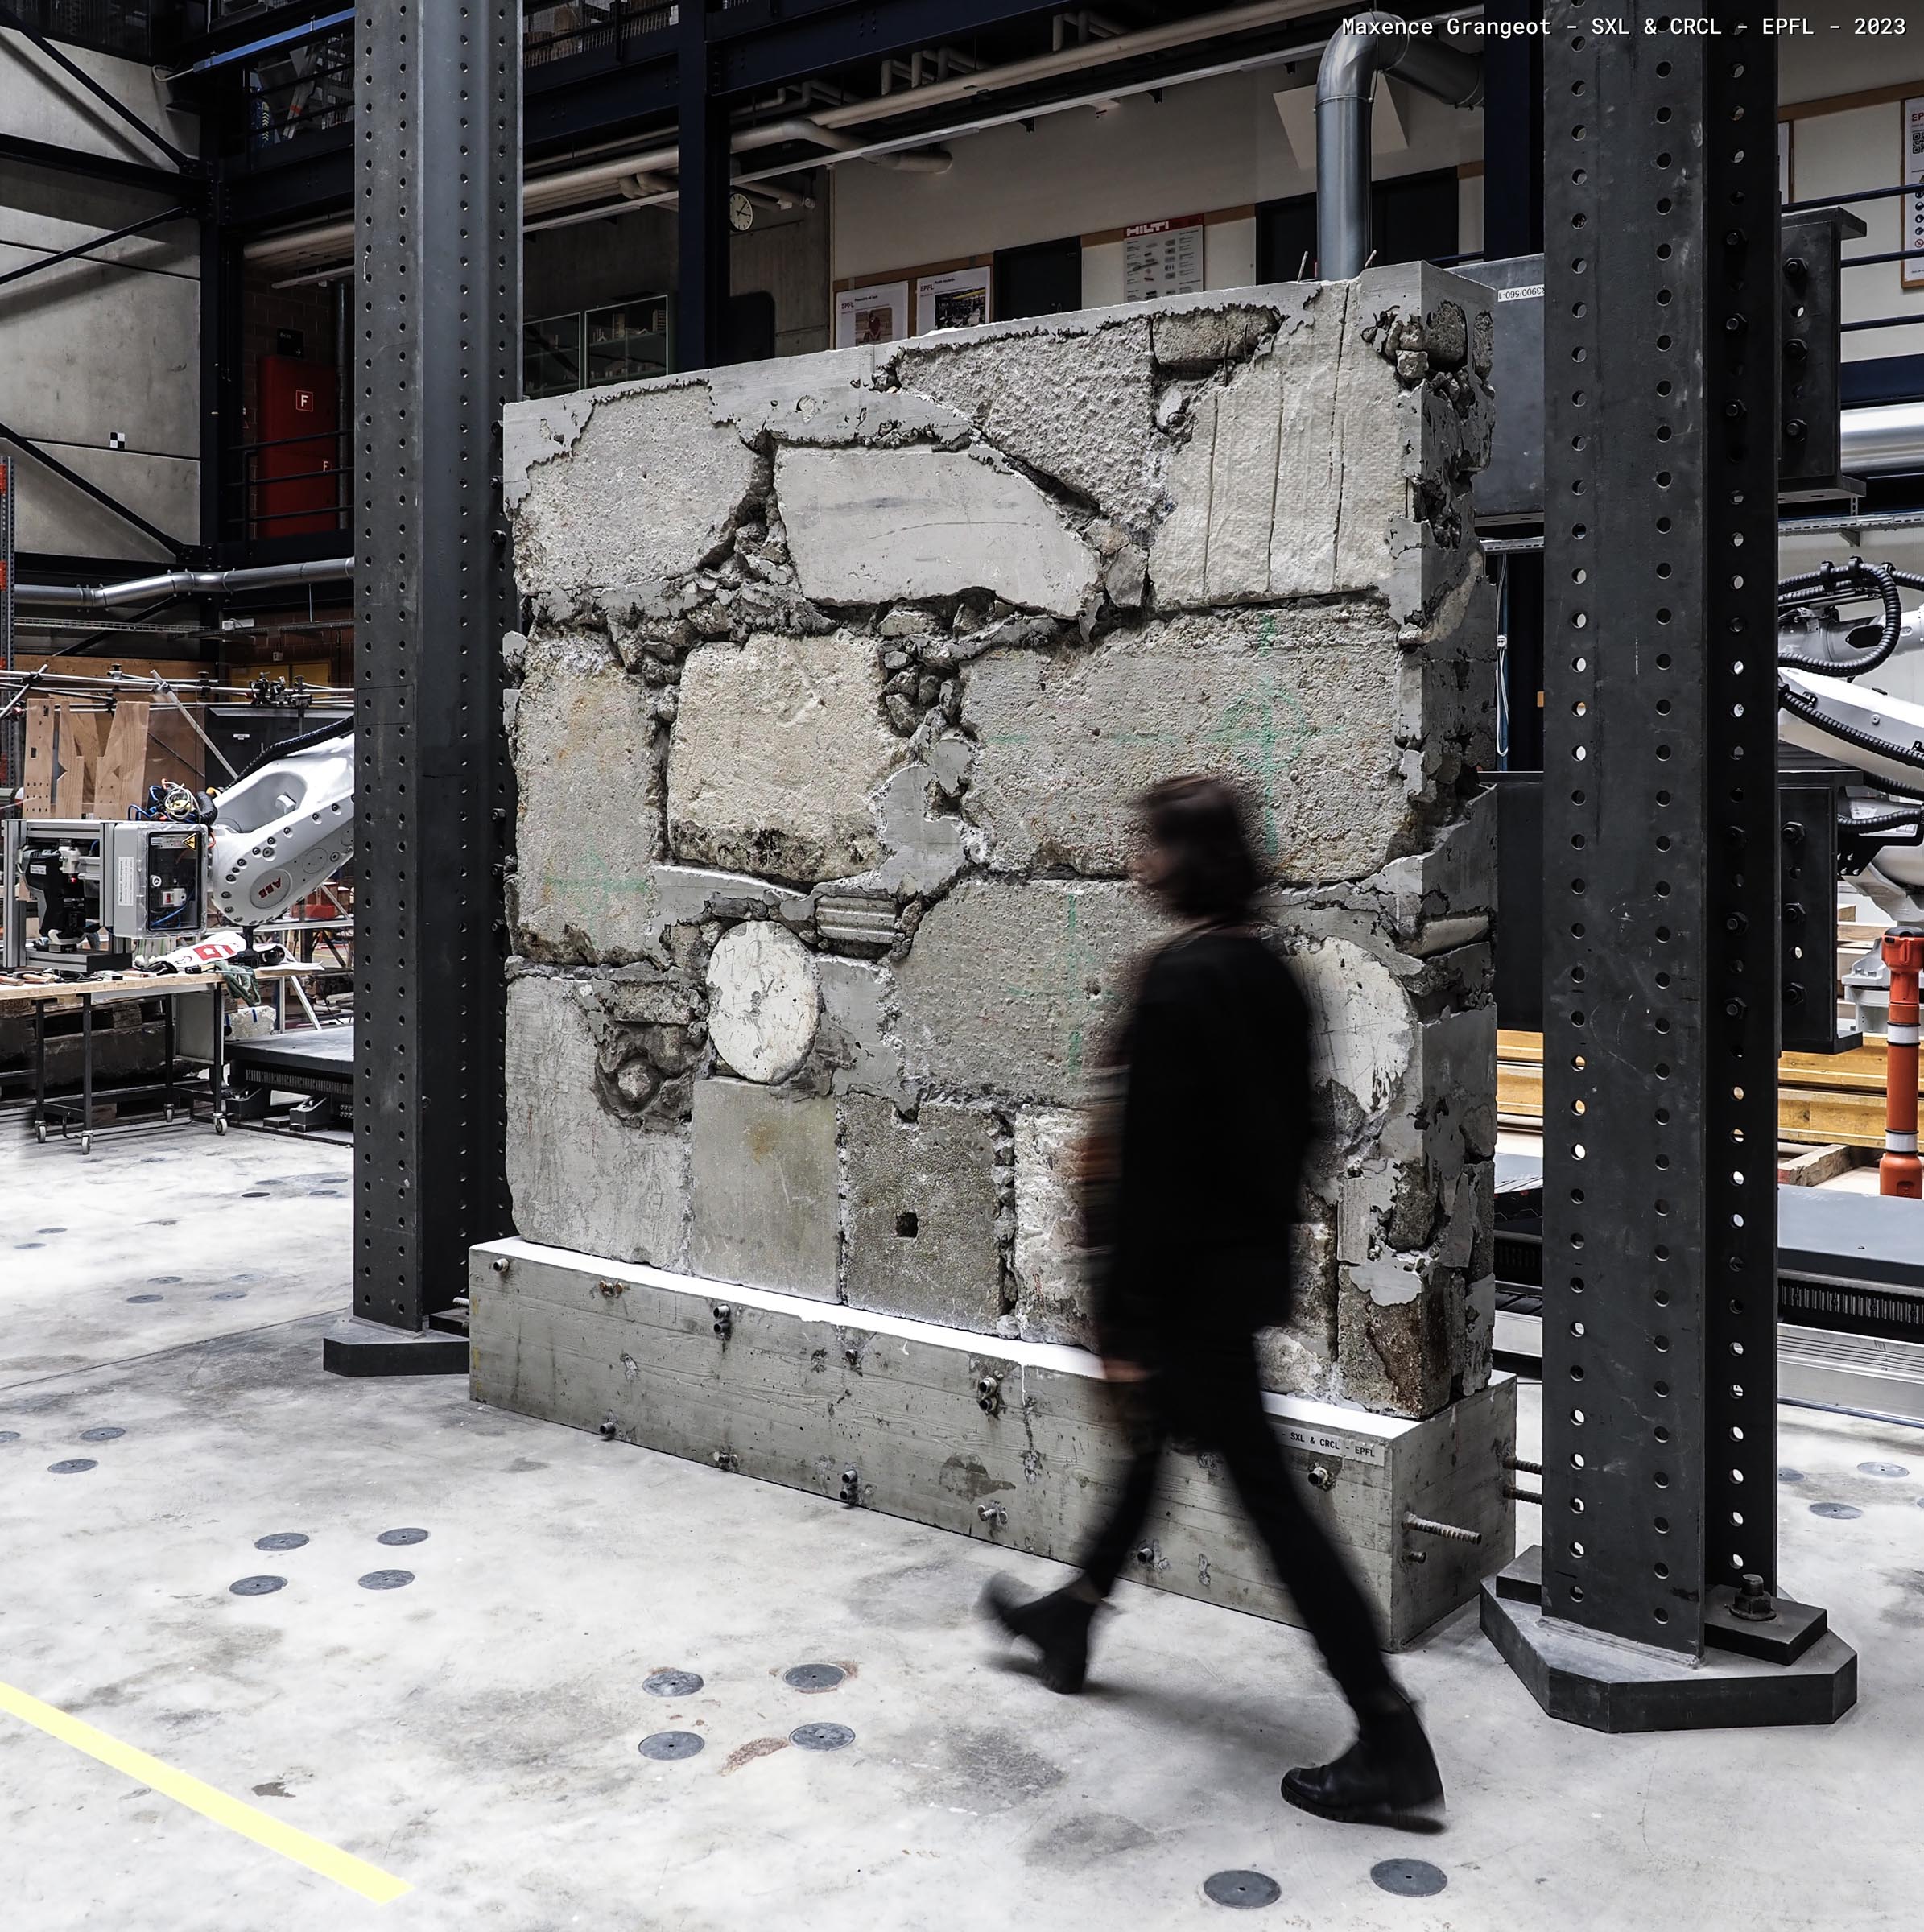
  6. Rising from Rubble: Leveraging Existing Construction Tools for Upcycling Concrete Waste into Slender Walls Maxence Grangeot, Qianqing Wang, Katrin Beyer, Corentin Fivet, and Stefana Parascho Robotic Fabrication in Architecture, Art and Design 2024 (ROB|ARCH 2024), pp. 253–265, Springer, Cham (New Frontiers Runner-Up Award, ROB|ARCH 2024) DOI ↗
  7. Truss from Trash: A Human–Robot Framework for Adaptive Timber Assembly on the Construction Floor Eleni Skevaki, Eric Duong, Hong-Bin Yang, and Stefana Parascho Construction Robotics 10 (1): 2 DOI ↗
  8. TimberProxy: A Tangible Human–Robot Interface for Incremental Design and Fabrication of Timber Structures Eleni Skevaki, Marirena Kladeftira, Ziqi Wang, Sihui Wu, Gudela Grote, and Stefana Parascho ACADIA 2025: Computing for Resilience, Proceedings of the Annual Conference of the Association for Computer Aided Design in Architecture, pp. 786–795 DOI ↗
  9. Dynamic Planning and Assembly for Constructing Mortar-Joint Multi-Leaf Stone Masonry Walls with a Robotic Arm Qianqing Wang, Jingwen Wang, Bryan German Pantoja Rosero, Katrin Beyer, and Stefana Parascho 2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), pp. 4873–80 DOI ↗
  10. Crafted by Hand and Machine: Human–Robot Fabrication Workflow for the Use of Curved Wood in Construction Alberto Johnsson Alvarez, Eleni Skevaki, Marirena Kladeftira, and Stefana Parascho eCAADe 2025: Confluence, Proceedings of the 43rd Conference on Education and Research in Computer Aided Architectural Design in Europe, pp. 745–754 DOI ↗
  11. Learning to Assemble with Alternative Plans Ziqi Wang, Wenjun Liu, Jingwen Wang, Gabriel Vallat, Fan Shi, Stefana Parascho, and Maryam Kamgarpour ACM Transactions on Graphics 44 (4): 1–16 DOI ↗
  12. Microscale Digital Twinning of Rubble Stone Masonry Walls Using Robotic Assembly Qianqing Wang, Jingwen Wang, Stefana Parascho, and Katrin Beyer Proceedings of the 42nd International Symposium on Automation and Robotics in Construction (ISARC 2025), pp. 1408–1413 DOI ↗
  13. DiffCheck: A Scan-CAD Evaluation Tool for Digital Manufacturing and Assembly Processes in Timber Construction Andrea Settimi, Damien Gilliard, Eleni Skevaki, Marirena Kladeftira, Julien Gamerro, Stefana Parascho, and Yves Weinand Structures and Architecture: REstructure REmaterialize REthink REuse, edited by Mario Rinke and Marie Frier Hvejsel, pp. 687–695, CRC Press DOI ↗
  14. New Tectonics of Concrete through Rubble Reuse Maxence Grangeot, Tanguy Auffret-Postel, Stefana Parascho, and Corentin Fivet Structures and Architecture: REstructure REmaterialize REthink REuse, edited by Mario Rinke and Marie Frier Hvejsel, pp. 1185–1192, CRC Press DOI ↗
  15. Re:Config: A Human–Robot Collaborative Process for the Reuse and Reconfiguration of Existing Timber Structures in the European Building Stock Marirena Kladeftira, Corentin Fivet, and Stefana Parascho Structures and Architecture: REstructure REmaterialize REthink REuse, edited by Mario Rinke and Marie Frier Hvejsel, CRC Press
  16. From Words to Actions: A Large Language Model (LLM) Approach for Human–Robot Interaction in Design-Fabrication Settings Isla Xi Han and Stefana Parascho CAADRIA 2025: Architectural Informatics, Proceedings of the 30th International Conference of the Association for Computer-Aided Architectural Design Research in Asia, vol. 2, pp. 325–334 (Young CAADRIA Award 2025) DOI ↗
  17. Augmented Human–Robot Collaborative Bending: Human–Robot Collaboration for Biogenic Material Bending-Active Assemblies Alexandra Pittiglio, Xiliu Yang, Marirena Kladeftira, Felix Amtsberg, Achim Menges, and Stefana Parascho CAADRIA 2025: Architectural Informatics, Proceedings of the 30th International Conference of the Association for Computer-Aided Architectural Design Research in Asia, vol. 2, pp. 315–324 DOI ↗
  18. Large Concrete Rubble as a New Structural Construction Material: Opportunities and Digital Processes for Load-Bearing Walls Maxence Grangeot, Malena Bastien-Masse, Corentin Fivet, and Stefana Parascho Buildings 15 (9): 1437 DOI ↗
  19. Disused Concrete, Digital Acupuncture and Reuse Corentin Fivet, Stefana Parascho, Maxence Grangeot, and Malena Bastien-Masse Architectural Design 94 (5): 88–97 DOI ↗
  20. Structural Concrete Rubble Arrangements: A Framework for Upcycling Demolition Waste into Slender Masonry Walls for Buildings Maxence Grangeot, Qianqing Wang, Katrin Beyer, Corentin Fivet, and Stefana Parascho Scalable Disruptors: Proceedings of the Design Modelling Symposium Kassel 2024, pp. 15–27, Springer, Cham DOI ↗
  21. Upcycling Concrete Rubble into Masonry Walls: Design and Assessment of Two Prototypes Built with Digitally Augmented Tools Maxence Grangeot, Malena Bastien-Masse, Stefana Parascho, and Corentin Fivet Proceedings of the 4th fib International Conference on Concrete Sustainability (ICCS 2024), pp. 324–331, Springer, Cham DOI ↗
  22. Concrete Rubble as a New Construction Material: Panorama of Applications to Known Structural Typologies Maxence Grangeot, Stefana Parascho, and Corentin Fivet Proceedings of the IASS 2024 Symposium: Redefining the Art of Structural Design, Zürich Link ↗
  23. Scaffold-Free Cooperative Robotic Disassembly and Reuse of a Timber Structure in the ZeroWaste Project Edvard Bruun, Erin Besler, Sigrid Adriaenssens, and Stefana Parascho Construction Robotics 8 (2): 20 DOI ↗
  24. Human-Robot Interaction – Workshop at Design Modelling Symposium 2024 Eleni Skevaki, Marirena Kladeftira, Ziqi Wang, and Stefana Parascho Design Modelling Symposium 2024 Kassel, September 2024 Link ↗
  25. Assembly of Spaceframes in Hybrid Teams: Adaptive Digital Fabrication Workflows for Human-Robot Collaboration Eleni Skevaki, Marirena Kladeftira, Alexandra Pittiglio, and Stefana Parascho CAADRIA 2024: Accelerated Design, Proceedings of the 29th International Conference of the Association for Computer-Aided Architectural Design Research in Asia, vol. 3, pp. 291–300 DOI ↗
  26. Construction Robotics: From Automation to Collaboration Stefana Parascho Annual Review of Control, Robotics, and Autonomous Systems 6 (1): 183–204 DOI ↗
  27. Constrained Form-Finding of Tension-Compression Structures using Automatic Differentiation Rafael Pastrana, Patrick Ole Ohlbrock, Thomas Oberbichler, Pierluigi D’Acunto, and Stefana Parascho Computer-Aided Design 155: 103435 DOI ↗
  28. From Concrete Waste to Walls: An Investigation of Reclamation and Digital Technologies for New Load-Bearing Structures Maxence Grangeot, Corentin Fivet, and Stefana Parascho Journal of Physics: Conference Series 2600 (19): 192019 DOI ↗
  29. Reinforcement Learning for Scaffold-Free Construction of Spanning Structures Gabriel Vallat, Jingwen Wang, Anna Maddux, Maryam Kamgarpour, and Stefana Parascho Proceedings of the 8th ACM Symposium on Computational Fabrication (SCF ’23), pp. 1–12, Association for Computing Machinery, New York DOI ↗
  30. Multi-Robotic Assembly of Discrete Shell Structures Jingwen Wang, Wenjun Liu, Gene Ting-Chun Kao, Ioanna Mitropoulou, Francesco Ranaudo, Philippe Block, and Benjamin Dillenburger Advances in Architectural Geometry 2023, edited by Kathrin Dörfler, Jan Knippers, Achim Menges, Stefana Parascho, Helmut Pottmann, and Thomas Wortmann, pp. 261–274, De Gruyter, Berlin/Boston DOI ↗
  31. BamX: Rethinking Deployability in Architecture through Weaving Seiichi Suzuki, Alison Grace Martin, Yingying Ren, Tzu-Ying Chen, Stefana Parascho, and Mark Pauly Advances in Architectural Geometry 2023, edited by Kathrin Dörfler, Jan Knippers, Achim Menges, Stefana Parascho, Helmut Pottmann, and Thomas Wortmann, pp. 207–220, De Gruyter, Berlin/Boston DOI ↗
  32. Social Signals: An Adaptive Installation for Mediating Space During COVID-19 and Beyond Eric Duong and Stefana Parascho Computer-Aided Architectural Design. INTERCONNECTIONS: Co-Computing Beyond Boundaries, edited by Michela Turrin, Charalampos Andriotis, and Azarakhsh Rafiee, pp. 547–61, Communications in Computer and Information Science, Springer Nature Switzerland, Cham DOI ↗
  33. ZeroWaste: Towards Computing Cooperative Robotic Sequences for the Disassembly and Reuse of Timber Frame Structures Edvard Bruun, Sigrid Adriaenssens, Erin Besler, and Stefana Parascho ACADIA 2022: Hybrids & Haecceities, Proceedings of the 42nd Annual Conference of the Association for Computer Aided Design in Architecture, pp. 586–597 Link ↗
  34. Improv-Structure: Exploring Improvisation in Collective Human-Robot Construction Isla Xi Han and Stefana Parascho Trends on Construction in the Digital Era, edited by António Gomes Correia, Miguel Azenha, Paulo J. S. Cruz, Paulo Novais, and Paulo Pereira, pp. 233–43, Lecture Notes in Civil Engineering, Springer International Publishing, Cham DOI ↗
  35. Structural Rigidity Theory Applied to the Scaffold-Free (Dis)Assembly of Space Frames Using Cooperative Robotics Edvard Bruun, Sigrid Adriaenssens, and Stefana Parascho Automation in Construction 141: 104405 DOI ↗
  36. Bridging the Collectives: A Review of Collective Human-Robot Construction Isla Xi Han, Forrest Meggers, and Stefana Parascho International Journal of Architectural Computing 19 (4): 512–531 DOI ↗
  37. Robotic Additive Construction of Bar Structures: Unified Sequence and Motion Planning Yijiang Huang, Caelan R. Garrett, Ian Ting, Stefana Parascho, and Caitlin T. Mueller Construction Robotics 5 (2): 115–130 DOI ↗
  38. Three cooperative robotic fabrication methods for the scaffold-free construction of a masonry arch Edvard Bruun, Rafael Pastrana, Vittorio Paris, Alessandro Beghini, Attilio Pizzigoni, Stefana Parascho, and Sigrid Adriaenssens Automation in Construction 129: 103803 DOI ↗
  39. Numerical Modeling of Static Equilibria and Bifurcations in Bigons and Bigon Rings Tian Yu, Lauren Dreier, Francesco Marmo, Stefano Gabriele, Stefana Parascho, and Sigrid Adriaenssens Journal of the Mechanics and Physics of Solids 152: 104459 DOI ↗
  40. LightVault: A Design and Robotic Fabrication Method for Complex Masonry Structures Stefana Parascho, Isla Xi Han, Alessandro Beghini, Masaaki Miki, Samantha Walker, Edvard Bruun, and Sigrid Adriaenssens AAG 2020: Advances in Architectural Geometry, pp. 350–375, Presses des Ponts, Paris
  41. Robotic Construction of a Self-Balancing Glass Masonry Vault: DEM Study of Stability During Construction Stages Vittorio Paris, Nicola Lepore, Edvard Bruun, Giuseppe Ruscica, Mario Daniele Piccioni, Alessandro Beghini, Stefana Parascho, and Sigrid Adriaenssens Proceedings of the IASS Annual Symposium 2020/21: Inspiring the Next Generation, pp. 314–325 Link ↗
  42. Robotic Construction of a Self-Balancing Glass Masonry Vault: Design and Tessellation Alessandro Beghini, Samantha Walker, Masaaki Miki, Isla Xi Han, Sigrid Adriaenssens, and Stefana Parascho Proceedings of the IASS Annual Symposium 2020/21: Inspiring the Next Generation
  43. Robotic Vault: A Cooperative Robotic Assembly Method for Brick Vault Construction Stefana Parascho, Isla Xi Han, Samantha Walker, Alessandro Beghini, Edvard Bruun, and Sigrid Adriaenssens Construction Robotics 4 (3–4): 117–126 DOI ↗
  44. Human–Robot Collaboration: A Fabrication Framework for the Sequential Design and Construction of Unplanned Spatial Structures Edvard Bruun, Ian Ting, Sigrid Adriaenssens, and Stefana Parascho Digital Creativity 31 (4): 320–36 DOI ↗
  45. From Concept to Construction: A Transferable Design and Robotic Fabrication Method for a Building-Scale Vault Isla Xi Han, Edvard Bruun, Stuart Marsh, Matteo Tavano, Sigrid Adriaenssens, and Stefana Parascho ACADIA 2020: Distributed Proximities, Proceedings of the 40th Annual Conference of the Association for Computer Aided Design in Architecture, pp. 614–623 DOI ↗
  46. Towards Automatic Path Planning for Robotically Assembled Spatial Structures Augusto Gandia, Stefana Parascho, Romana Rust, Gonzalo Casas, Fabio Gramazio, and Matthias Kohler Robotic Fabrication in Architecture, Art and Design 2018 (ROB|ARCH 2018), edited by Jan Willmann, Philippe Block, Marco Hutter, Kendra Byrne, and Tim Schork, pp. 59–73, Springer, Cham DOI ↗
  47. The Brick Labyrinth Luka Piškorec, David Jenny, Stefana Parascho, Hannes Mayer, Fabio Gramazio, and Matthias Kohler Robotic Fabrication in Architecture, Art and Design 2018 (ROB|ARCH 2018), edited by Jan Willmann, Philippe Block, Marco Hutter, Kendra Byrne, and Tim Schork, pp. 489–500, Springer, Cham DOI ↗
  48. Computational Design of Multi-Robotically Assembled Spatial Structures Stefana Parascho, Thomas Kohlhammer, Stelian Coros, Fabio Gramazio, and Matthias Kohler AAG – Advances in Architectural Geometry 2018, pp. 112–139, edited by Lars Hesselgren, Axel Kilian, Olga Sorkine Hornung, Samar Malek, Karl-Gunnar Olsson, and Christopher John Kenneth Williams, Klein Publishing, Göteborg Link ↗
  49. Cooperative Fabrication of Spatial Metal Structures Stefana Parascho, Augusto Gandia, Ammar Mirjan, Fabio Gramazio, and Matthias Kohler Fabricate 2017: Rethinking Design and Construction, pp. 24–29, edited by Achim Menges, Bob Sheil, Ruairi Glynn and Marilena Skavara, UCL Press, London. ISBN 978-1-78735-001-4 DOI ↗
  50. ICD/ITKE Research Pavilion 2013-14: Modular Coreless Filament Winding Based on Beetle Elytra Moritz Dörstelmann, Jan Knippers, Achim Menges, Stefana Parascho, Marshall Prado, and Tobias Schwinn Architectural Design 85 (5): 54–59 DOI ↗
  51. Modular Fibrous Morphologies: Computational Design, Simulation and Fabrication of Differentiated Fibre Composite Building Components Stefana Parascho, Jan Knippers, Moritz Dörstelmann, Marshall Prado, and Achim Menges AAG – Advances in Architectural Geometry 2014, pp. 29–45, edited by Philippe Block, Jan Knippers, Niloy J. Mitra, and Wenping Wang, Springer. ISBN 978-3-319-11418-7 DOI ↗
  52. Integrative Computational Design Methodologies for Modular Architectural Fiber Composite Morphologies Moritz Dörstelmann, Stefana Parascho, Marshall Prado, Jan Knippers, and Achim Menges ACADIA 2014: Design Agency, Proceedings of the 34th Annual Conference of the Association for Computer Aided Design in Architecture, pp. 219–228, edited by David Gerber, Alvin Huang and Jose Sanchez, ACADIA and Riverside Architectural Press. ISBN 978-1-926724-49-2 DOI ↗
  53. Agent-Based Model for the Development of Integrative Design Tools Stefana Parascho, Marco Baur, Ehsan Baharlou, Jan Knippers, and Achim Menges ACADIA 2013: Adaptive Architecture, Proceedings of the 33rd Annual Conference of the Association for Computer Aided Design in Architecture, pp. 429–430 DOI ↗
  54. Design Tools for Integrative Planning Stefana Parascho, Marco Baur, Jan Knippers, and Achim Menges eCAADe 2013: Computation and Performance, Proceedings of the 31st eCAADe Conference, vol. 2, pp. 237–246 DOI ↗
Books 9
  1. Design Space Explorations: On the role of visualisation in architectural fabrication and design Stefana Parascho Book chapter in Bio/Matter/Techno/Synthetics, University of Pennsylvania
  2. Digital Upcycling: New Tectonics for Architecture Maxence Grangeot, Corentin Fivet, and Stefana Parascho In Transcalar Prospects in Climate Crisis
  3. Motion Pictures Eric Duong and Stefana Parascho In Transcalar Prospects in Climate Crisis
  4. Cooperative Robotic Fabrication for a Circular Economy Edvard Bruun, Stefana Parascho, and Sigrid Adriaenssens Book chapter in A Circular Built Environment in the Digital Age, edited by Catherine De Wolf, Sultan Çetin, and Nancy Bocken, pp. 129–149, Springer, Cham DOI ↗
  5. Beyond Optimization: Interaction as a Means to Resituate Digital Fabrication Stefana Parascho Book chapter in Homing the Machine
  6. Advances in Architectural Geometry 2023 Kathrin Dörfler, Jan Knippers, Achim Menges, Stefana Parascho, Helmut Pottmann, and Thomas Wortmann De Gruyter, Berlin/Boston (Editors) DOI ↗
  7. Realignments: Toward Critical Computation – Proceedings of ACADIA 2021 Kathrin Dörfler, Stefana Parascho, and Jane Scott Book (Editors) DOI ↗
  8. Home Position Stefana Parascho Book chapter in Design Studio Vol. 2: Intelligent Control 2021: Disruptive Technologies, edited by Rob Hyde and Filippos Filippidis, RIBA Publishing
  9. Generative Design Edvard Bruun, Stefana Parascho, and Sigrid Adriaenssens Encyclopedia of Artificial Intelligence: The Past, Present, and Future of AI, edited by Philip L. Frana and Michael J. Klein, ABC-CLIO, Santa Barbara Link ↗
Dissertations 1
  1. Cooperative Robotic Assembly: Computational Design and Robotic Fabrication of Spatial Metal Structures Stefana Parascho Doctoral thesis, ETH Zurich DOI ↗
Articles 4
  1. Invisible Motions Stefana Parascho Drawing Codes: Experimental Protocols of Architectural Representation, Applied Research + Design
  2. def help(): technical support Stefana Parascho Pidgin Magazine 26, Princeton University
  3. Integrative Architekturmodelle Stefana Parascho Kunst + Architektur in der Schweiz 2018.4, Gesellschaft für Schweizerische Kunstgeschichte, Berne. ISBN 978-3-03797-345-5
  4. Un labirint de cărămidă Stefana Parascho igloo habitat & arhitectură 179, Aug–Sep 2017, pp. 138–141, Igloo Media, Bucharest

 Research 

Manuscript image
Research by Gabriel Vallat on training robots to build structures from specifications
🤖📝🏗️

Manuscript image
A collection of collaborative robotics projects developed by Eleni Skevaki
🤖📱🤖

Manuscript image
Research by Maxence Grangeot on upcycling large irregular concrete rubble pieces from demolition sites into walls
🪨🏗️🪨

Manuscript image
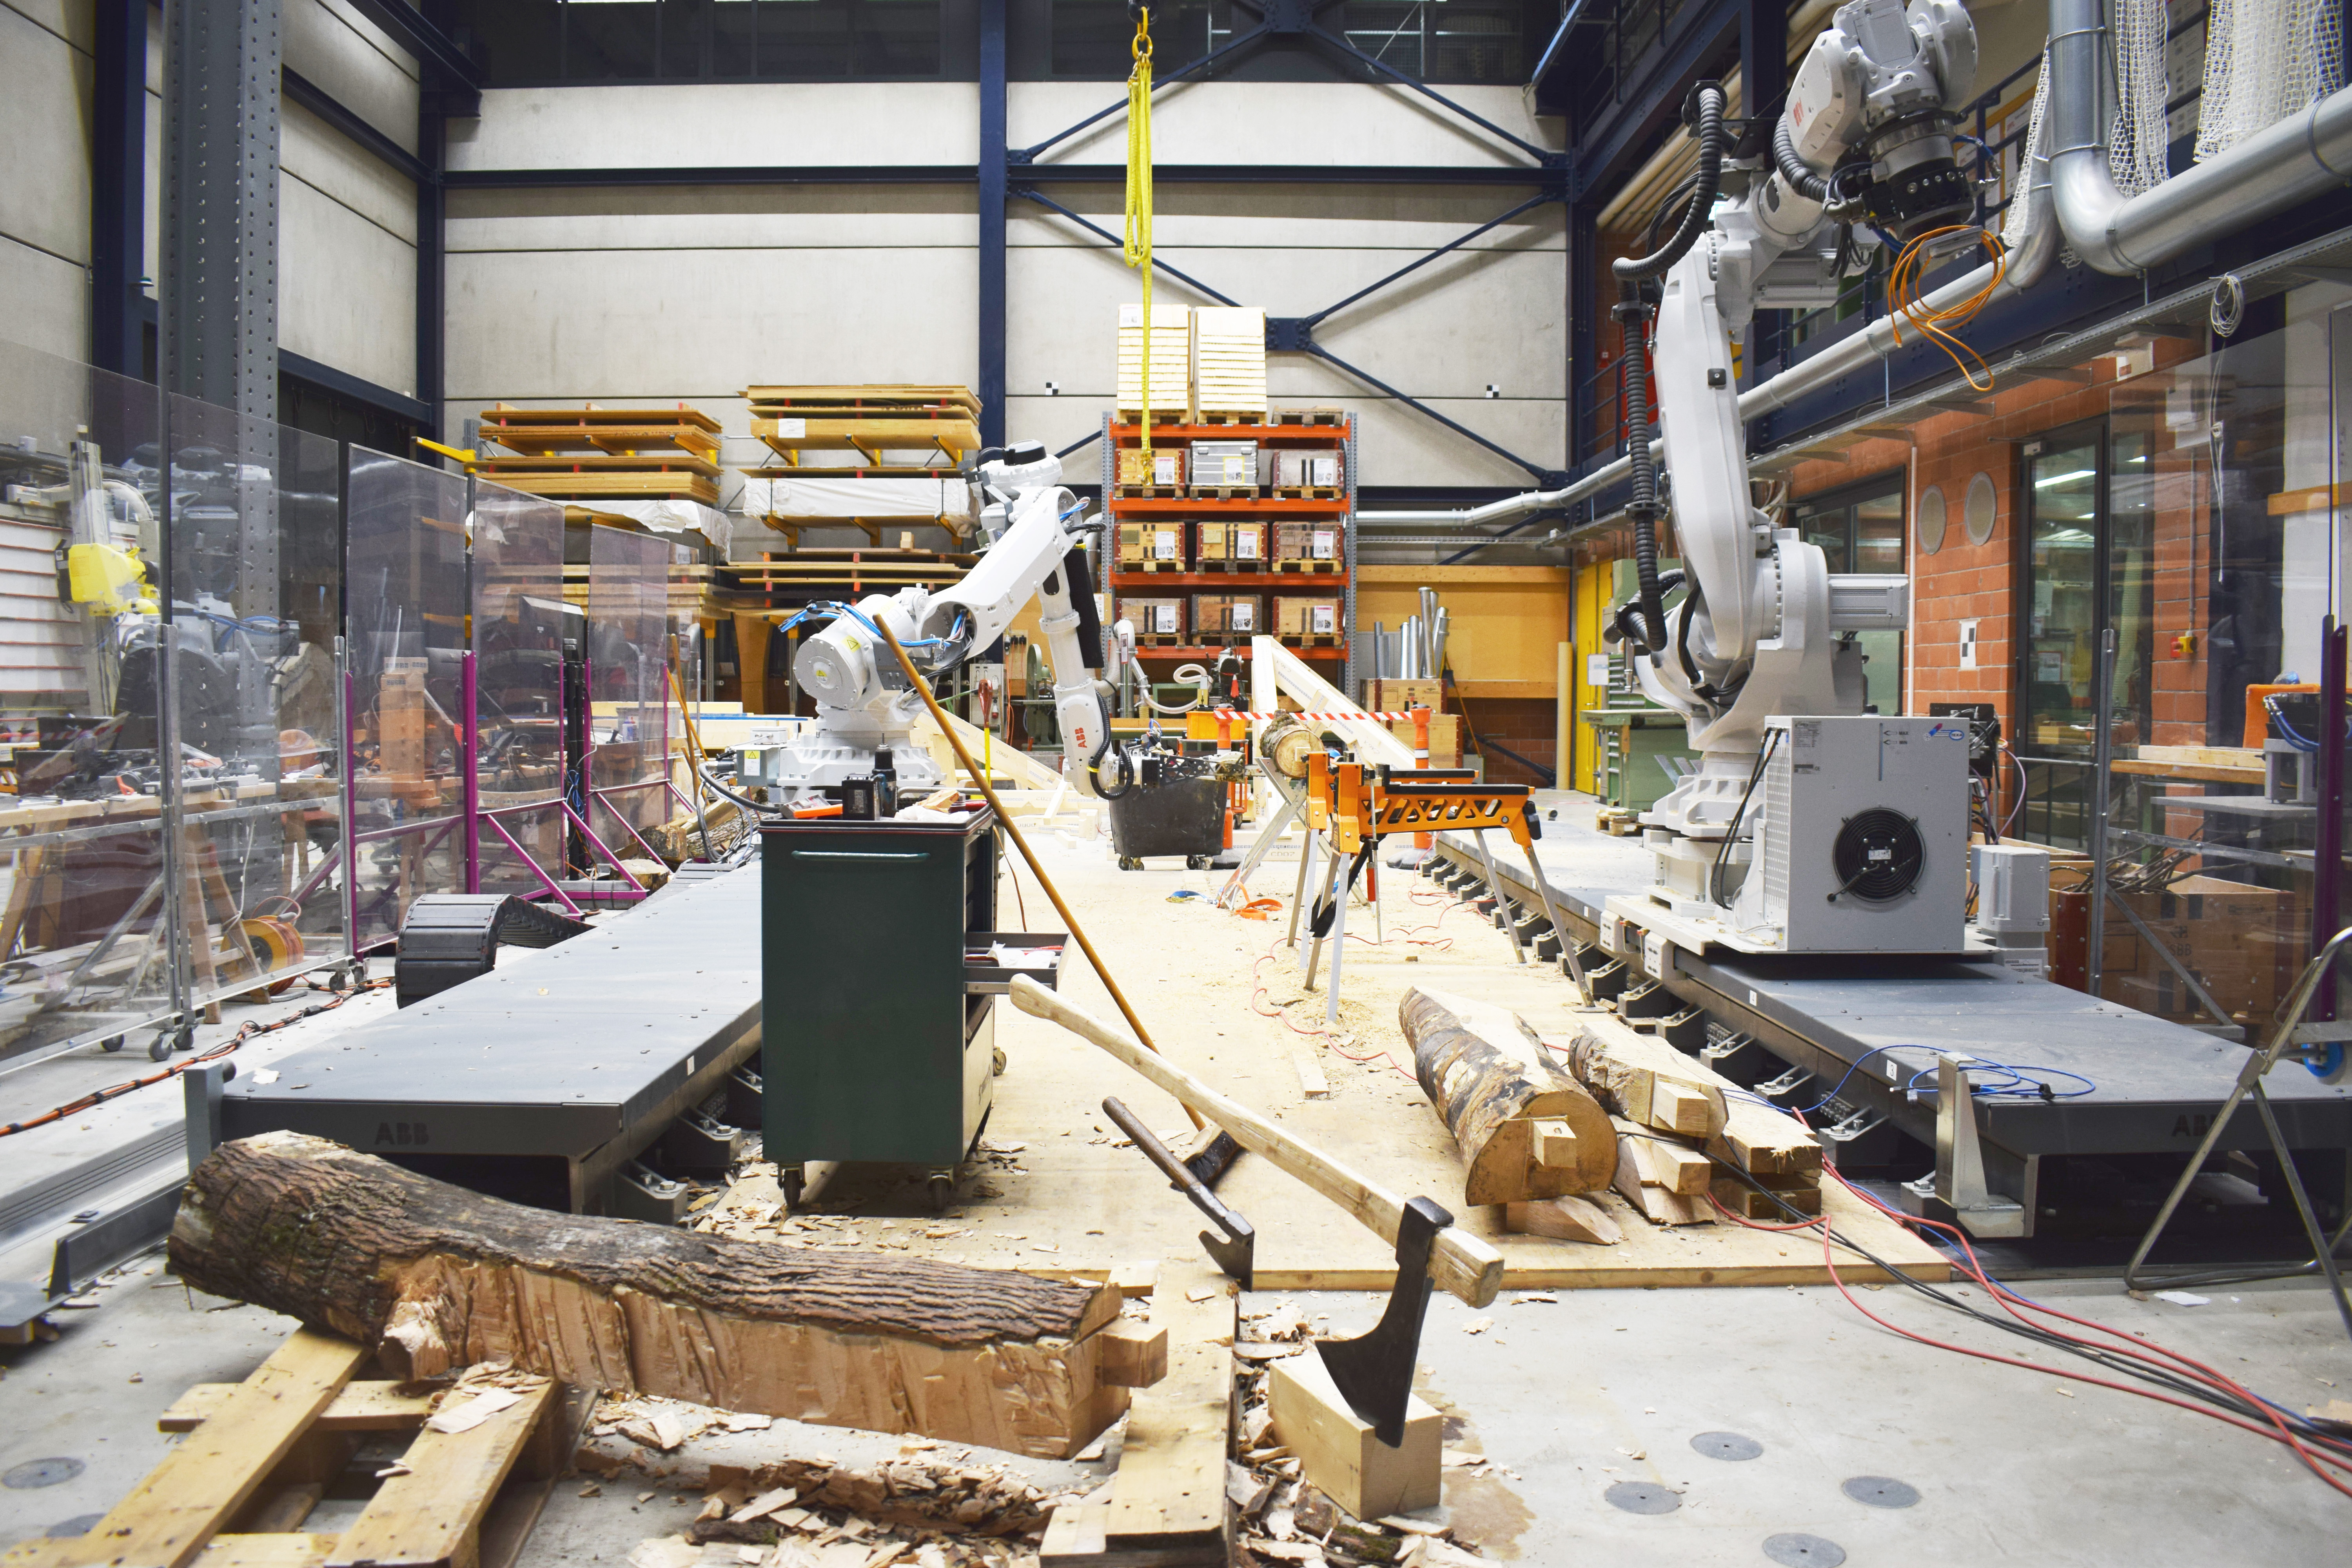
Human-robot adaptive workflows for disassembly, repair, and construction
🏫🤖🏠

Coming soon!
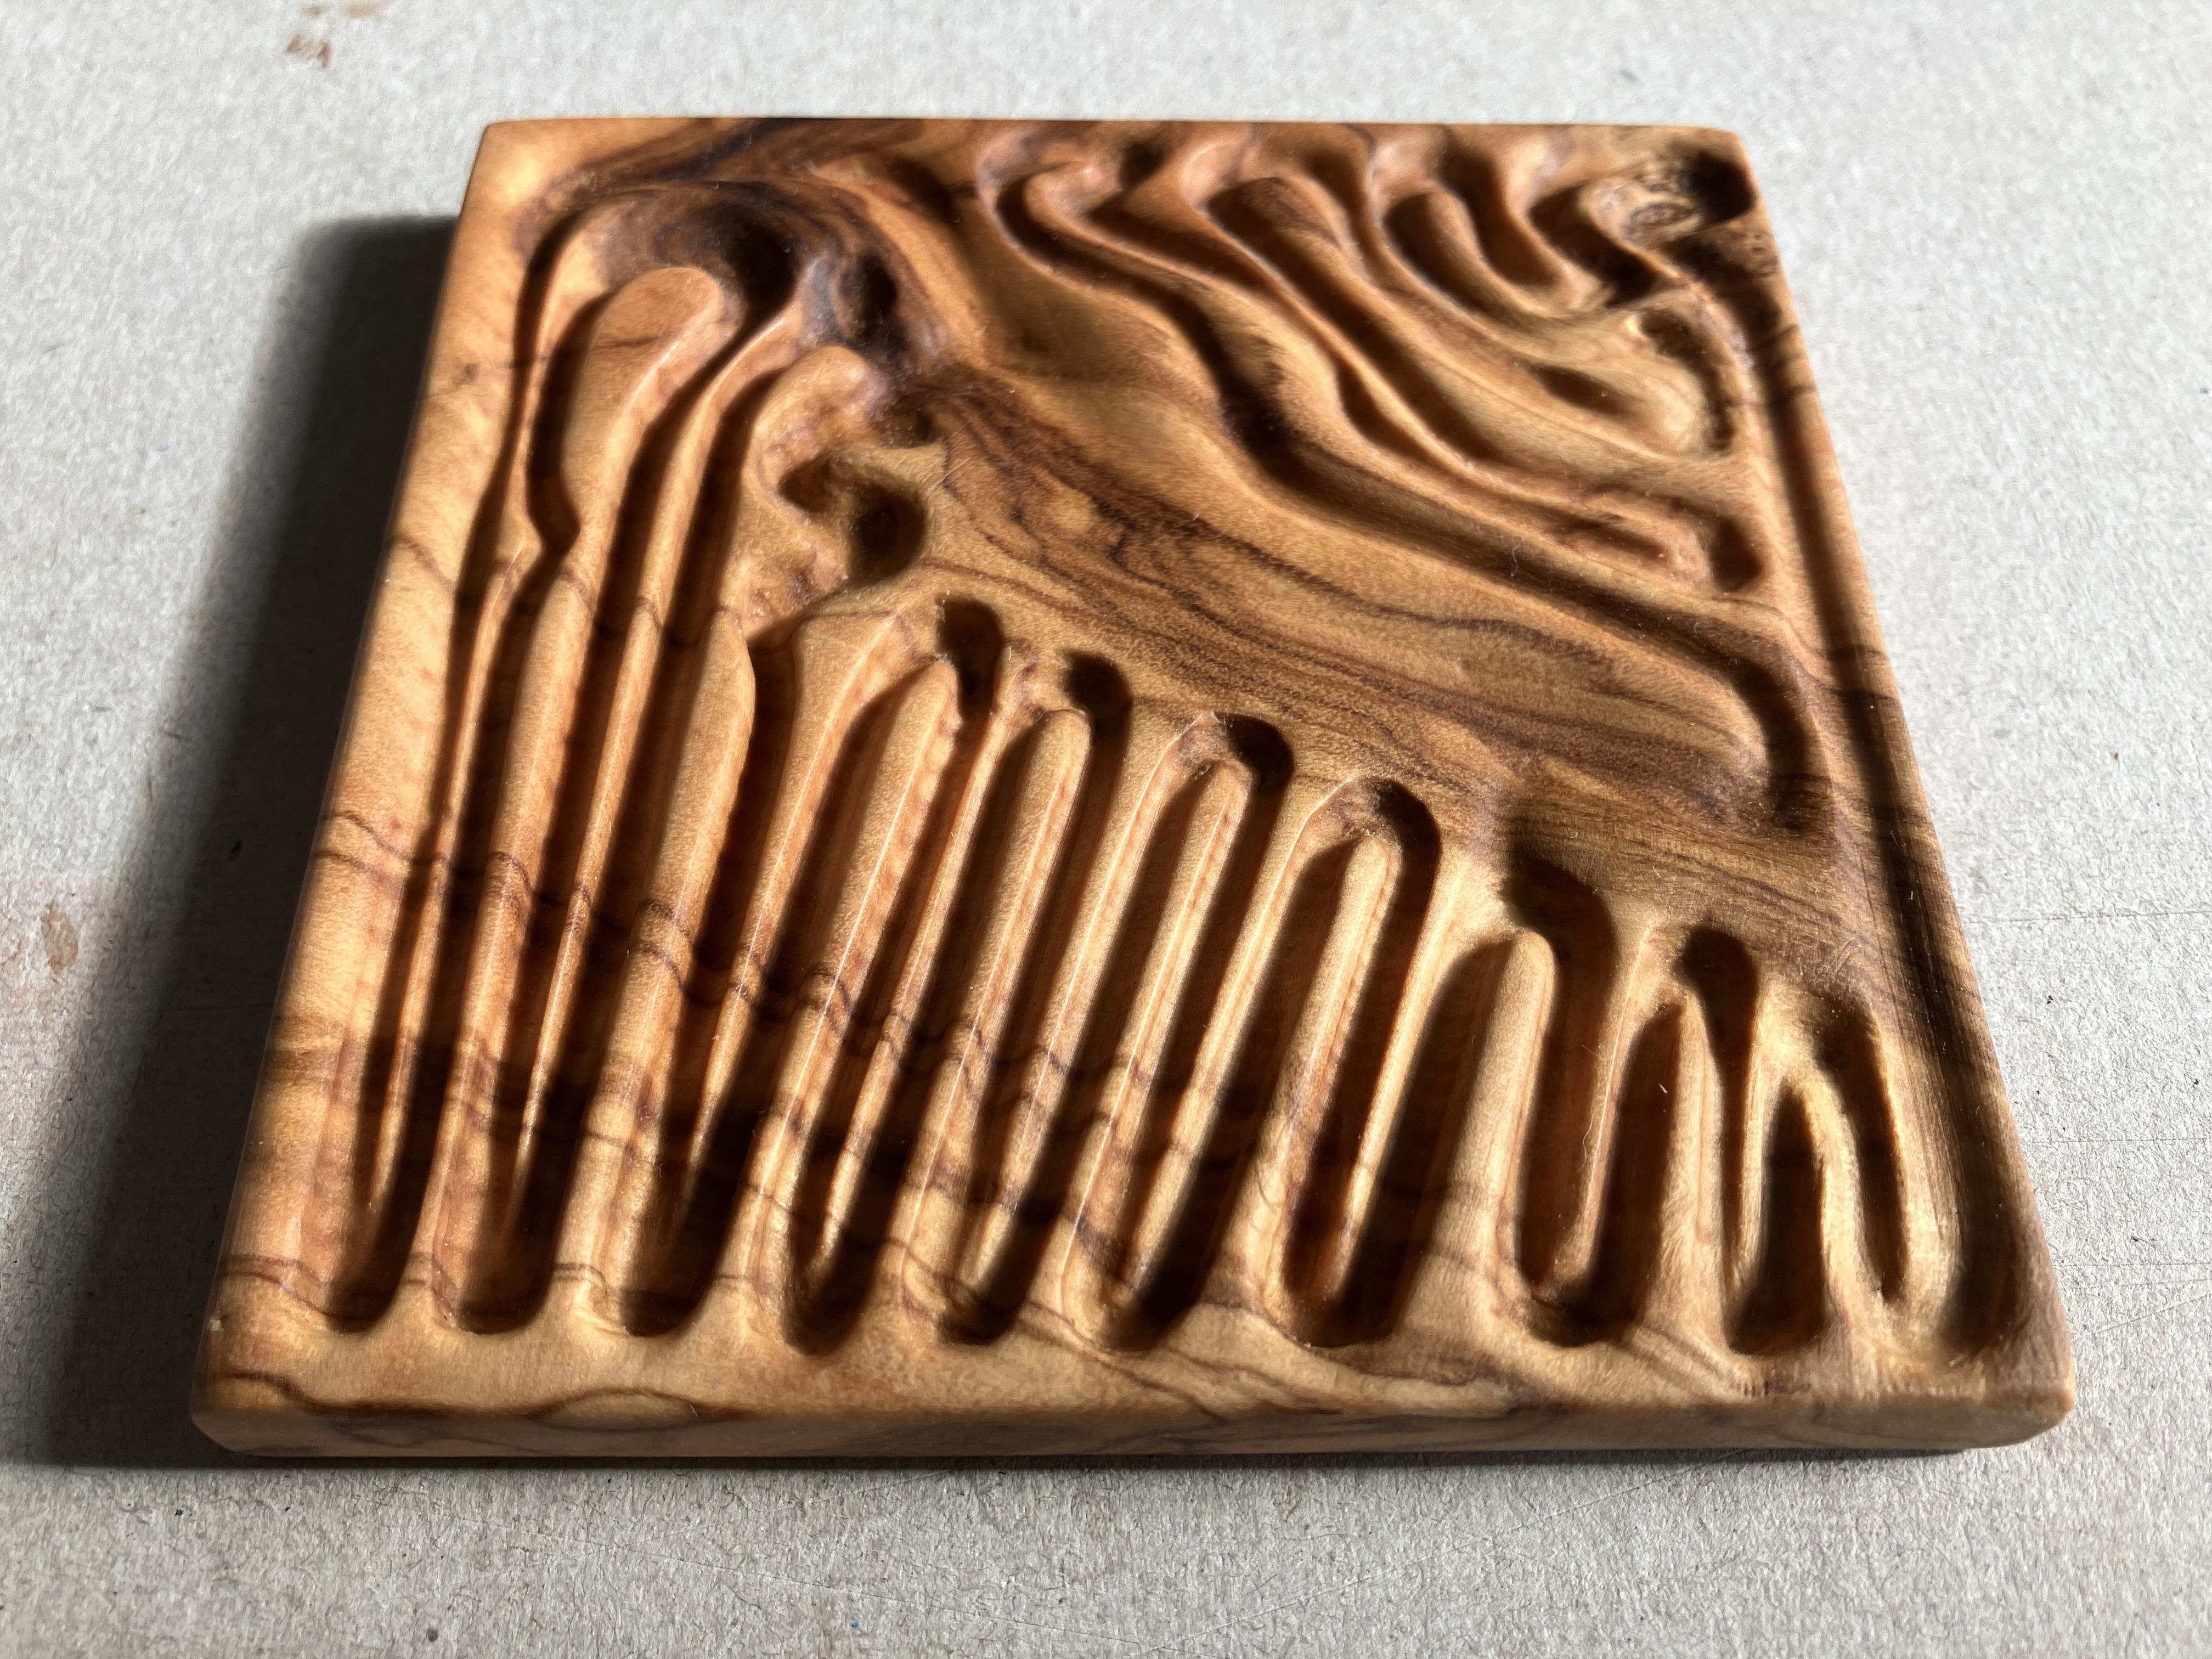
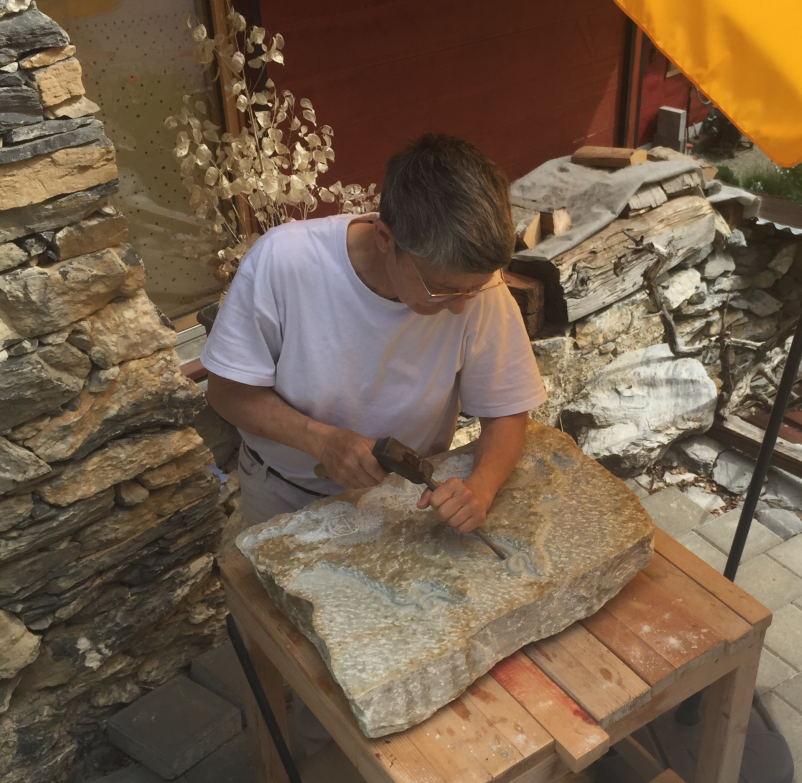
Research by Marie-Pierre on the relationship between the human hand and tools for making, both new and old
🪨⚒️🪨

Manuscript image
Human-robot fabrication workflow for the use of curved wood in construction by Alberto Johnsson
🪵💻🪵

Manuscript image
An upcoming manuscript on the unrealized dream of construction automation
🌐 📖 🌐

Web page of the Future of Construction symposium
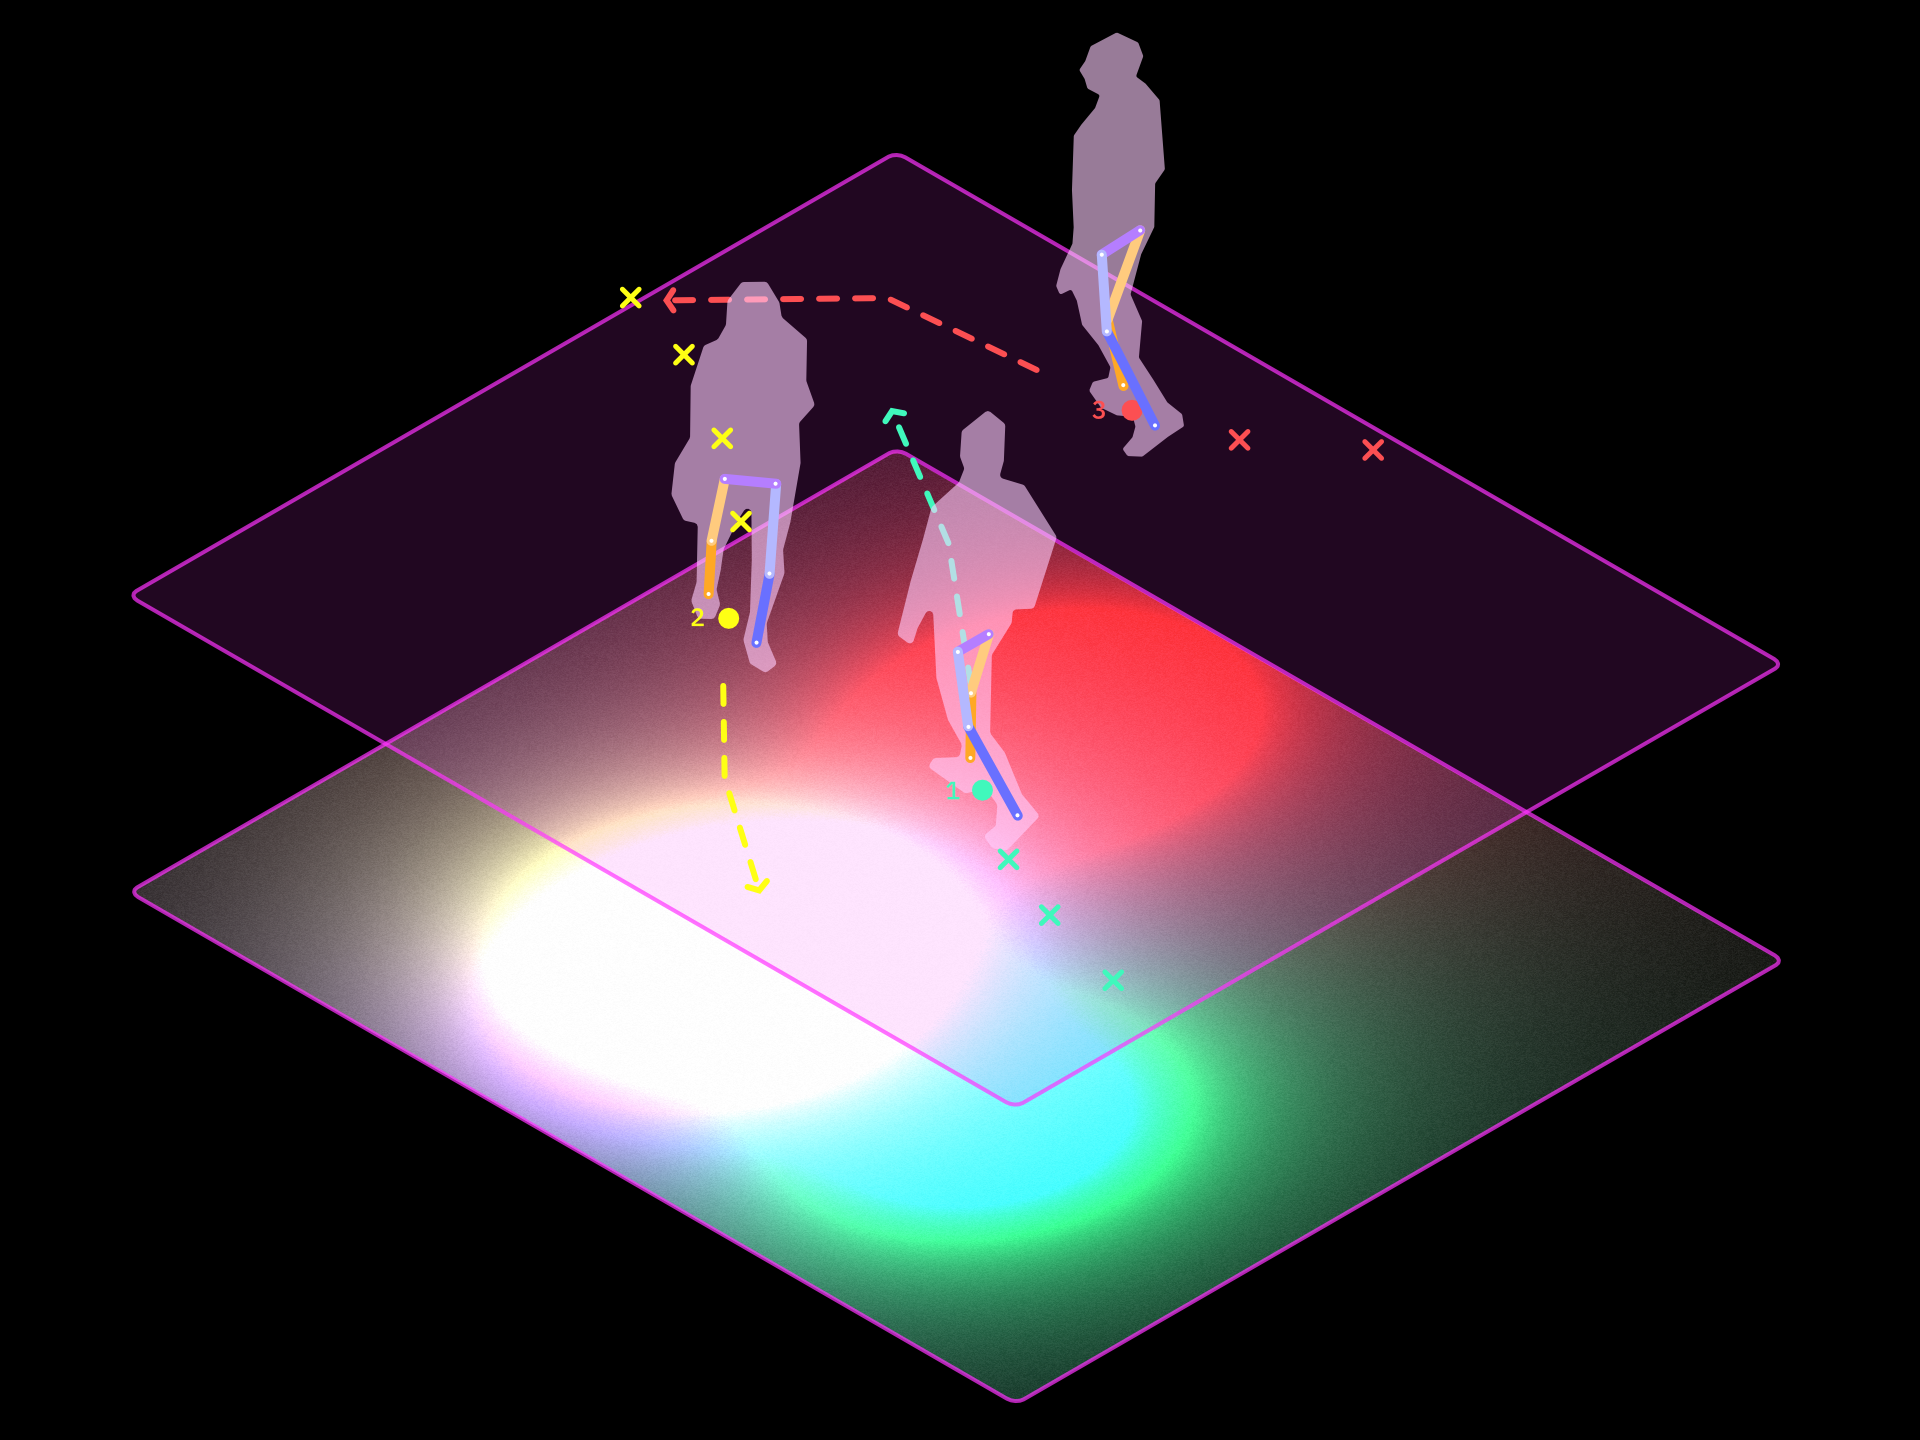
An interactive installation that brings together building occupancy analysis methods, trajectory prediction, and digital media to understand and mediate shared spaces
🔮 🚧 🔮

Web page of the Future of Construction symposium
A platform dedicated to beginner-friendly creative coding tutorials and exercises for building architecture with robots
🏫 🤖 🏫

 Teaching 

Student Projects

Master's Projects - Architecture
📸 Alberto Johnsson

We'll add some topic ideas soon, but in the meantime you can see projects that previous students have completed with us. Of course if you have any ideas related to robots, digital fabrication, design software, and computation feel free to reach out and discuss more with us!

Contact: Eric Duong

Previous Projects

Alberto Johnsson: Digital Woodcraft : A Wood-Making Village in the Jorat

Johan Link: A chapel in Rüeggisberg

Spring 2026

🏫🤖🏫

Master's Project - Microengineering
📸 Jingwen Wang

Dual Arm Adaptation for Robotic Construction

Dual-robot collaborative construction of self-supporting arches under geometric and physical uncertainty

Contact: Jingwen Wang

Spring 2026, beginning early February

↓ PROJECT .PDF ↓

🦾🪨🦾

Courses

NEW

EPFL + ETHZ PhD/Master Summer School – Capitalizing on Uncertainty

Capitalizing on Uncertainty — Structures, Processes, Mindsets is a 6-day summer school for EPFL & ETHZ PhD and Master students, exploring how uncertainty can be engaged as a productive resource in design and fabrication.

More details on the program, dates, and registration are available on on the course website

31 August – 5th of September 2026

🪵🎓🦾

Learn more about the course on the coursebook.

Fall 2022, Fall 2023, Fall 2025

🦾💡🦾

Fall 2024

⚒️🪨⚒️

A weeklong course on daylight analysis using Grasshopper

January 2024

🦗☀️🦗

Spring 2023

🤖🎨🤖

Find materials for computational design and building with robots on the LE-AR-N website!.

Ongoing

🖥️🧠🖥️

 Team 

  1. Dalila Romero ZenkerScientific Assistant

    Profile photo of Dalila

    Dalila is a scientific assistant at CRCL, working on human–robot collaboration in adaptive timber structures. She holds an Integrated Master’s degree in Architecture and a MAS in Architecture and Digital Fabrication from ETH. She has worked professionally in Switzerland and abroad on projects ranging from new construction to heritage‑protected buildings. Her research interests include computational fabrication, material‑driven design, and circular construction across contemporary and heritage contexts.

    Beyond the lab 🐱🐈📚⛷️🩰🖼️🐈‍⬛

  2. Eleni SkevakiDoctoral Assistant

    Profile photo of Eleni Skevaki

    Eleni Skevaki is a doctoral researcher at the Lab for Creative Computation (CRCL) of EPFL Lausanne and associated with the National Centre for Competence in Research – Digital Fabrication, where she explores human-robot interaction within heterogeneous construction teams. 🤖 She holds an integrated Master in Architectural Engineering from the National Technical University of Athens and an MAS in Architecture and Digital Fabrication from ETH Zurich.🎓 Her working shoes are still dirty from spending too much time next to a 3D concrete printing robot. 🥾

  3. Eric DuongScientific Assistant

    Profile photo of Eric Duong
    📸 Ian Ting

    Eric is a scientific assistant at CRCL working on human-robot interfaces and interactive installations. He studied architecture and computer science at the University of Virginia, where he discovered creative coding through Processing and Grasshopper. 🖌 Today he goes between visual toolkits, computer vision libraries, and robotics toward building spatial experiences and experimental applications. 🚧 Outside of the lab, he enjoys backpacking, cycling, and making things. 🏕
  4. Gabriel VallatDoctoral Assistant

    Profile photo of Gabriel Vallat
    📸 Alex Pittiglio

    Gabriel is a PhD student at CRCL and Sycamore lab. He’s working on multi-agent reinforcement learning in a collaborative setting. 🦾🫂

    He has obtained a bachelor’s degree in micro-engineering and a master’s in robotics, both at the EPFL. During his civilian service, he worked as a data analyst in aquatic ecology at EAWAG, where he used deep neural networks to predict the evolution of plankton populations. 🦠🦆

    If you don’t see him in the office, you could try to catch him climbing or running outside 🧗‍♂️👣, or at Unipoly, where he tries to avoid conflicts by working as a mediator. 🕊️
  5. Jingwen WangDoctoral Assistant
    Profile photo of Jingwen Wang
    📸 Eric Duong

    Jingwen is a Ph.D. student at the CRCL. She is trained as a structural engineer and holds a B.Eng degree from HKUST and a M.Eng degree from MIT, both in Civil and Environmental engineering. After graduation, she worked in the New York office of Skidmore, Owings and Merrill for three years as a structural engineer, where she contributed to 15 projects worldwide. Notable projects she has worked on include Kempegowda International Airport Terminal II, MIT – Stephen A. Schwarzman College of Computing, NYC Penn Station Entrance Canopy.

    In 2021, she decided to pursue her interest in fabrication-related research. She came to Europe and did a Master of Advanced Studies in Architecture and Digital Fabrication at ETH Zurich. She still considers herself as a structural engineer at heart, but also loves design, robotics and architecture.

    In her free time, she likes walking around the city, taking photographs and watching films.

  6. Marie-Pierre ZuffereyScientist

    Profile photo of Marie-Pierre

    Marie-Pierre Zufferey is an architect dipl. EPFL, Doctor of Science, and scientific collaborator at CRCL. She has focused on geometry and stereotomy (stone-cutting) for a long time. Now she aims to tame robots and use them as tools that directly extend the human hand and spirit as pencil, brush, bow, and chisel toward investigating the links between representing and creating, and how to make these new technologies accessible for non-specialists. 

    Unexepected interactions could emerge with her many outside activities, like martial arts, carving, painting, entomological and botanical observations, and reading!

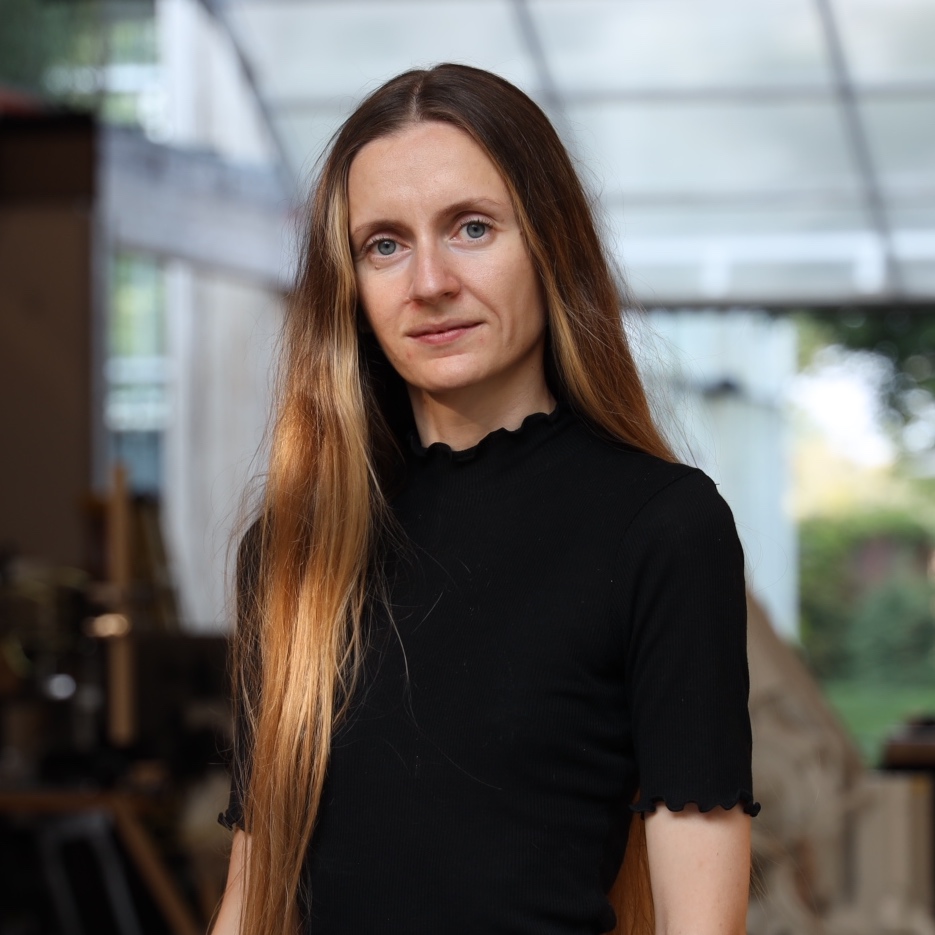
  7. Stefana ParaschoLaboratory Director

    Profile photo of Prof. Dr. Stefana Parascho
    📸 Mathias Bernhard

    Stefana Parascho is the Director of the Lab for Creative Computation (CRCL).

    Stefana studied in Stuttgart and received her Doctorate degree from ETH Zurich, Gramazio Kohler Research. She is an Assistant Professor at EPFL and makes sure that the robots and students in the lab don’t get bored. 💃 🤖 🕺 When she’s not in the lab, she is probably in a dance class or travelling (except during pandemics). She fights to see more recognition for women in STEM fields and hopes to never get stuck on a fixed research idea.

    Bio

    Stefana Parascho is a researcher, architect, and educator whose work lies at the intersection of architecture, digital fabrication and computational design. She is currently an Assistant Professor at EPFL where she founded the Lab for Creative Computation. Through her research, she has explored multi-robotic fabrication methods and their relationship to architectural design. Stefana investigated computational design techniques ranging from agent-based systems to sequential design and optimisation methods. Her goal is to strengthen the connection between design, structure, and fabrication, and boost the interdisciplinary nature of architecture through the development of accessible computational tools and robotic fabrication methods. Before joining EPFL, Stefana was an Assistant Professor at Princeton University, where she led the CREATE Lab Princeton. She completed her doctorate in 2019 at ETH Zurich, Gramazio Kohler Research. Previously, she received her Diploma in Architectural Engineering from the University of Stuttgart and worked with DesignToProduction Stuttgart and Knippers Helbig Advanced Engineering.

    • Anthony PecoriniAdministrative Assistant

    • Megi SinaniPhD Candidate

    • Nicolas RogeauScientist

    • Patricio CasanovaJoint PhD Candidate

    • Wenqian YangPhD Candidate

Collaborators

  1. Former team members:

    Postdocs

    Marirena Kladeftira – Postdoc → Asst. Professor at Cornell University Design Tech

    Ziqi Wang – Postdoc → Asst. Professor at Hong Kong University of Science and Technology

    PhDs

    Maxence Grangeot – PhD student → Asst. Professor at JMA-Fribourg

    Isla Xi Han – PhD student → Asst. Professor at the School of Innovation, University of Hong Kong

    Edvard Bruun – PhD student → Asst. Professor at Georgia Tech College of Engineering

    Ian Ting – PhD candidate → Lecturer at Rice University School of Architecture

    Rafael Pastrana – PhD student

    Lauren Dreier – PhD student

    Researchers

    Alexandra Pittiglio – Scientific collaborator

    Alberto Johnsson – Scientific collaborator

    Hong-Bin Yang – Scientific collaborator

    Matteo Pacher – Scientific collaborator

    Students

    Marcel Garrobé Fonollosa – Reinforcement learning intern

    Adam Joseph Ghadi-Delgado – MArch student

    Laura Fegely – MArch student

    John Mikesh – MArch student

    Jeff Tao – MArch student

    Chris Myefski – MArch student

    Emmanuel Osorno – MArch student

    Lisa Ramsburg – MArch student

    Admin

    Isabelle Cogotti – Administrative assistant

    Tamara Pelège – Administrative assistant

  2. Friends of the lab:

    Mathias Bernhard

    Maria Yablonina

    Kathrin Dörfler

    Besler & Daughter

    THEMA

    RIOT

    SXL

    GIS EPFL

    Archizoom

    SPOLIA

  3. Cats!

    Penelope Priscilla & Perseus Paulus 🐈‍⬛

    More @penny.and.percy

Contact Us

Administration

Anthony Pecorini

anthony.pecorini@epfl.ch

+41 21 693 38 74

Mailing Address

Stefana Parascho
EPFL ENAC IA
CRCL
GC G1 557
Station 18
1015 Lausanne
Switzerland

↑ About ↑ ↓ About ↓